Acta Aeronautica et Astronautica Sinica ›› 2026, Vol. 47 ›› Issue (14): 632687.doi: 10.7527/S1000-6893.2025.32687
• Electronics and Electrical Engineering and Control • Previous Articles
Bicheng CAI1, Siming ZHANG2, Xiaozhe JU3( ), Yuan LI4, Yong ZHAO1
Received:2025-08-18
Revised:2025-10-16
Accepted:2025-12-31
Online:2026-01-16
Published:2026-01-15
Contact:
Xiaozhe JU
E-mail:juhitnuaa@gmail.com
Supported by:CLC Number:
Bicheng CAI, Siming ZHANG, Xiaozhe JU, Yuan LI, Yong ZHAO. Data-driven predictive control for multi-arm spacecraft after target capture[J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(14): 632687.
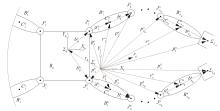
Fig.1
Schematic diagram of multi-arm spacecraft structure[24]
Table 1
Comparison between MSI and MII
| 对比维度 | MSI | MII |
|---|---|---|
| 搜索方法 | 解析法 | 迭代法 |
| 搜索步数 | 单步 | 多步 |
| 优化问题特性 | 凸优化 | 非凸优化 |
| 最优性保证 | 全局最优 | 全局次优 |
| 优化约束 | 无约束 | 有约束 |
| 计算消耗 | 小 | 大 |
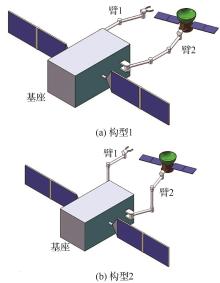
Fig.2
Multi-arm spacecraft configuration in simulations
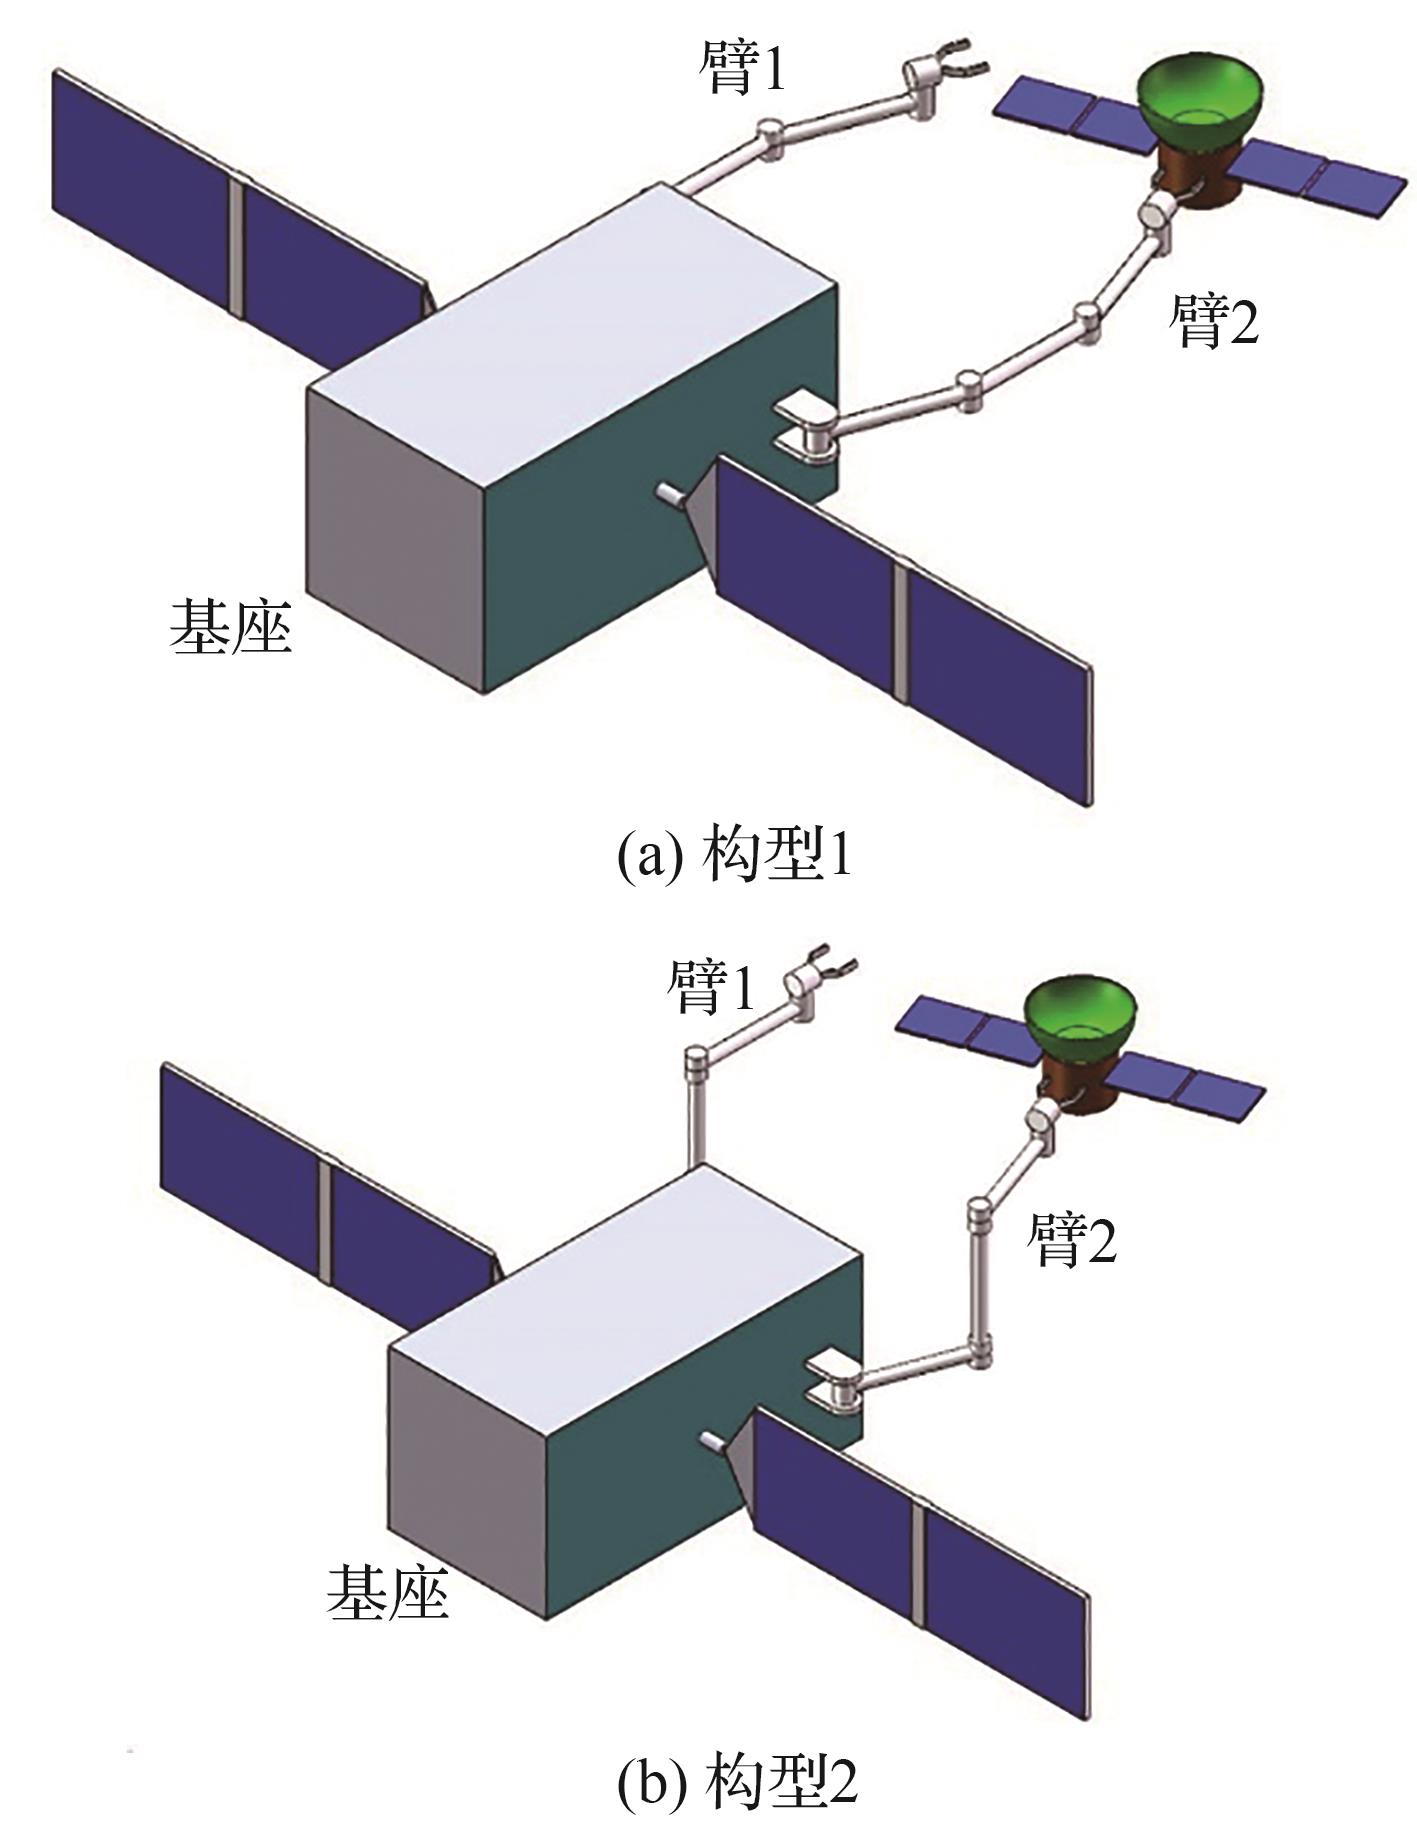
Table 2
Parameters of multi-arm spacecraft
| 参数 | 数值 |
|---|---|
| 基座尺寸/m | 1.2×0.6×0.6 |
| 臂杆长度/m | 0.4 |
| 基座质量/kg | 5 |
| 臂杆质量/kg | 0.2 |
| 基座惯量/(kg·m2) | |
| 臂杆惯量/(kg·m2) | |
| 末端组合杆件质量/kg | 2 |
| 末端组合杆件惯量/(kg·m2) |
Table 3
Parameters of MSI-IPC
| 参数 | 数值 |
|---|---|
| 状态量权重矩阵 | |
| 控制输入权重矩阵 | |
| 控制输入增量权重矩阵 | |
| 预测视界 | 10 |
| 基座喷管最大输入/N | 1 |
| 基座飞轮最大输入/(N·m) | 1 |
| 关节电机最大输入/(N·m) | 1 |
| 仿真时间步长 | 0.01 |
| 历史数据长度 | 100 |
Fig.3
Base position, velocity, and nozzle control input (capturing target under Configuration 1)
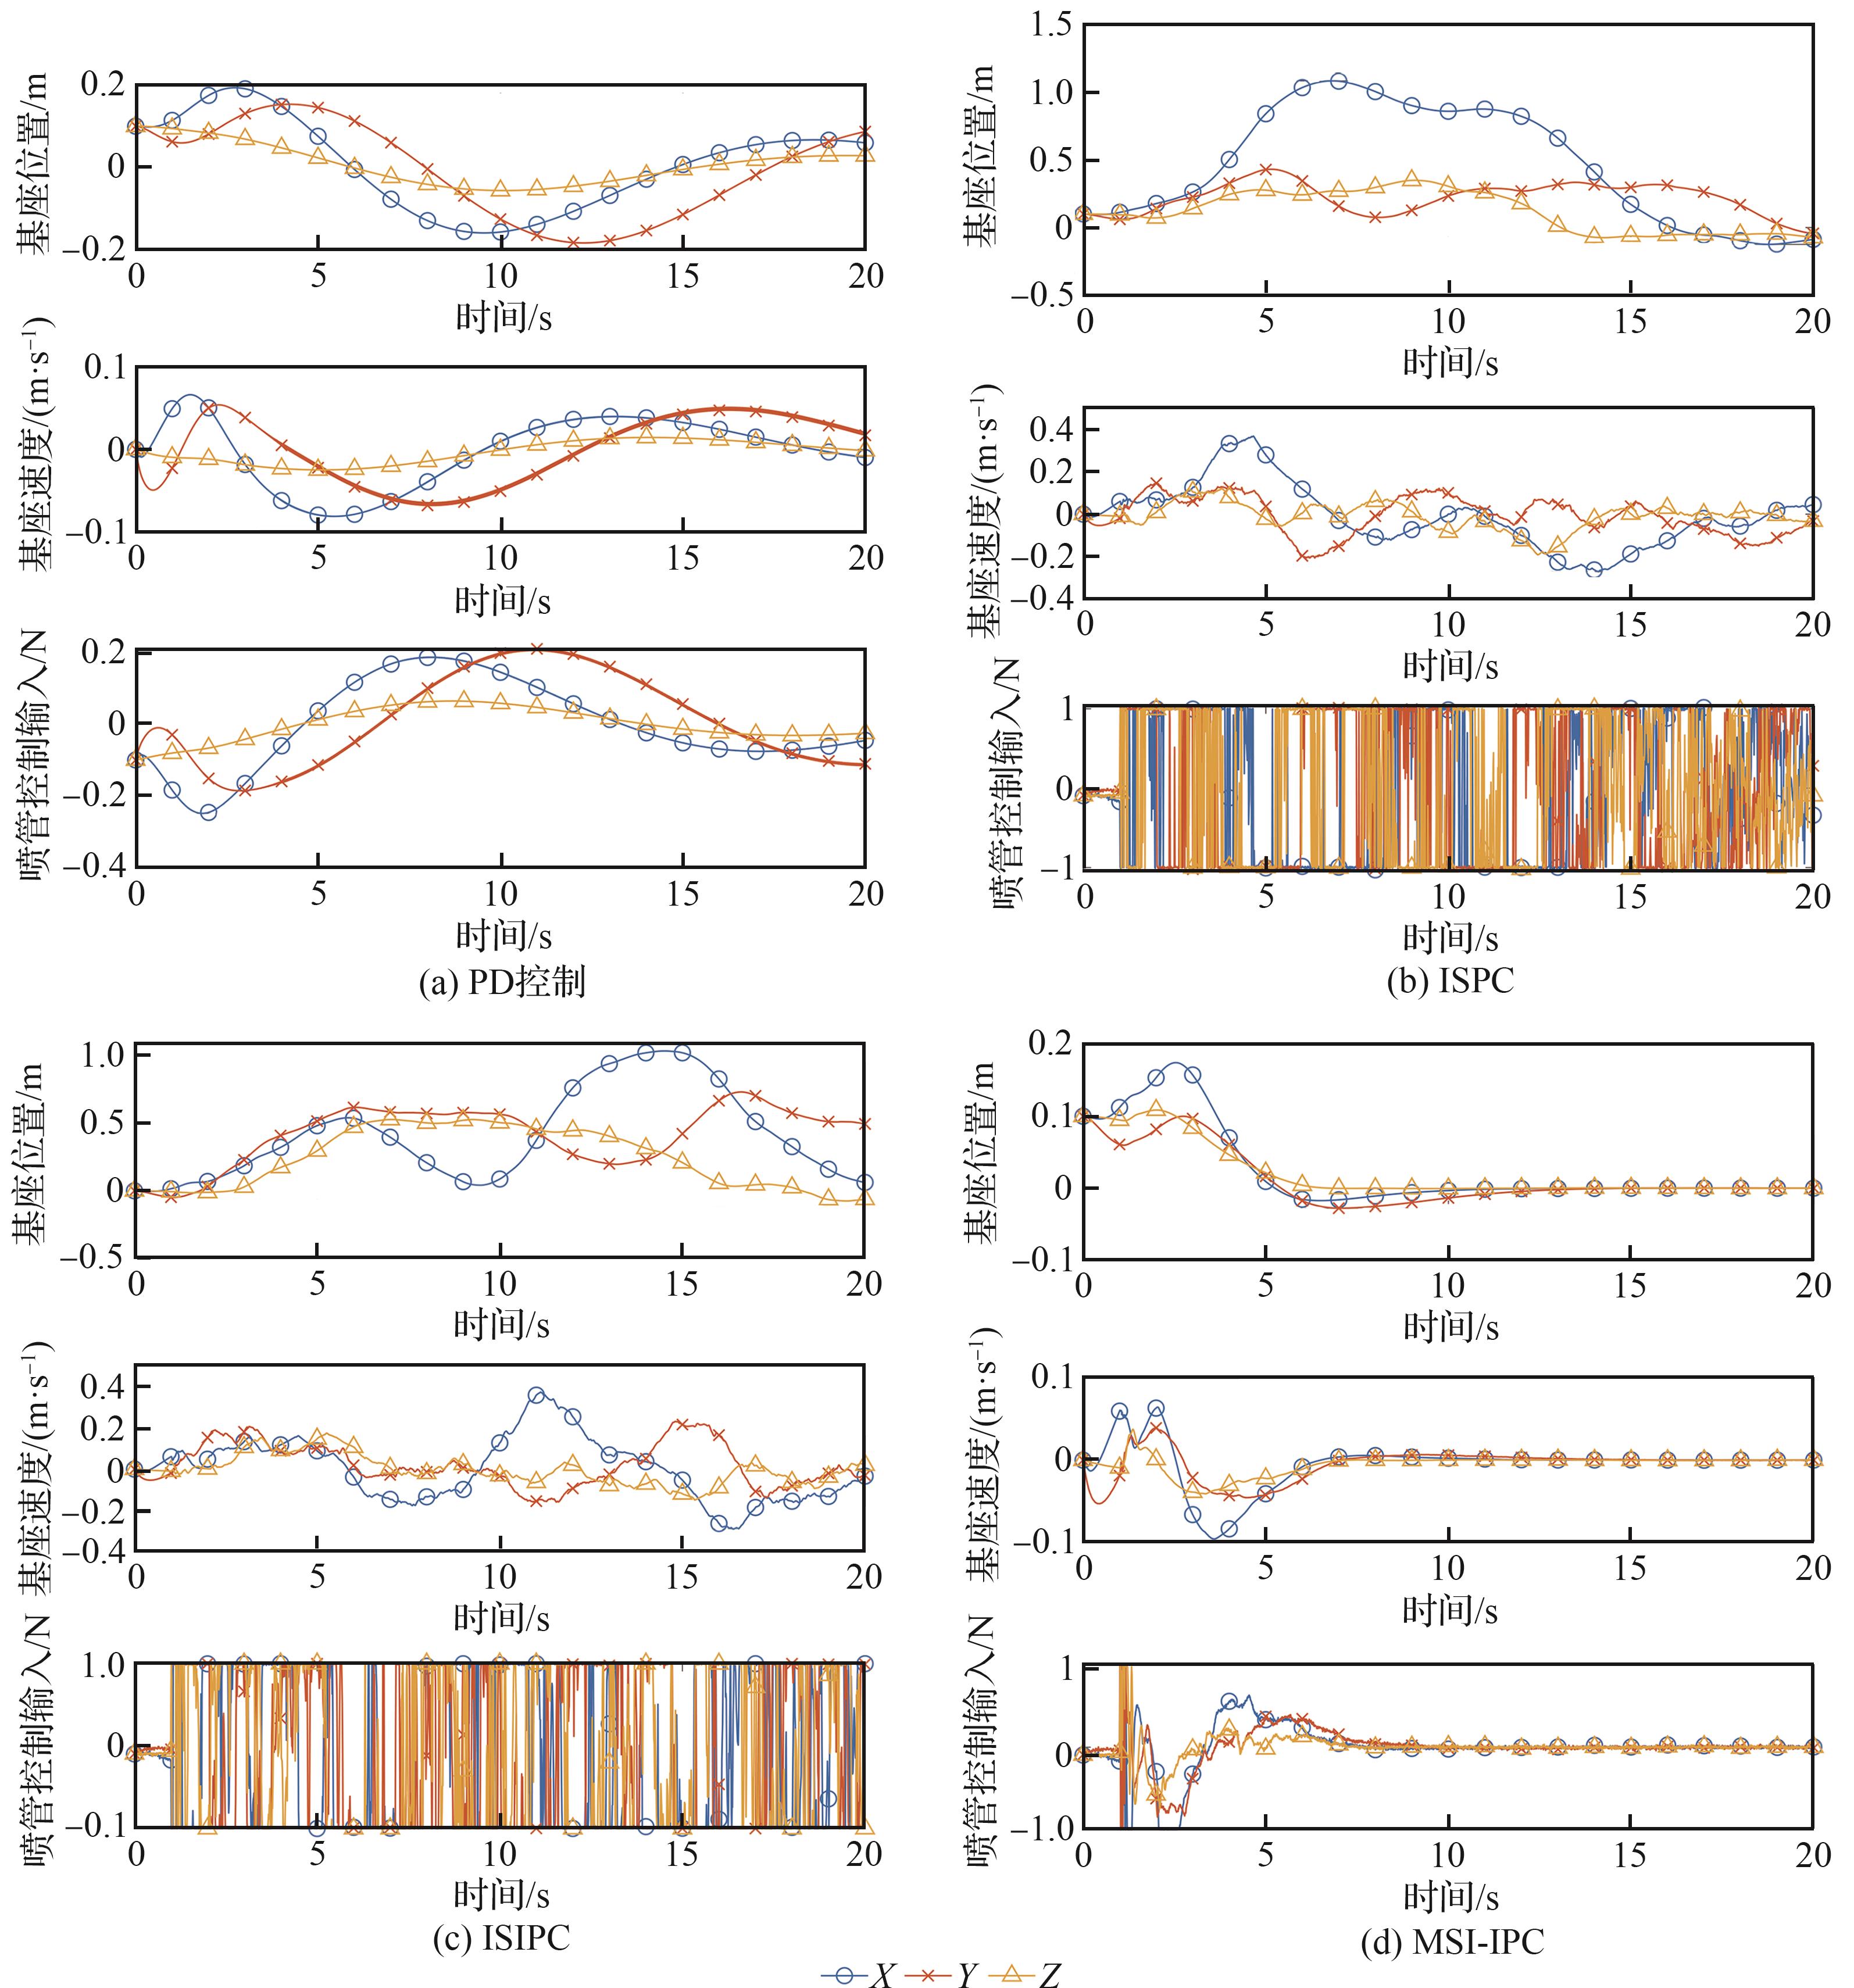
Fig.4
Base attitude Euler angle, angular rate, and flywheel control input (capturing target under Configuration 1)
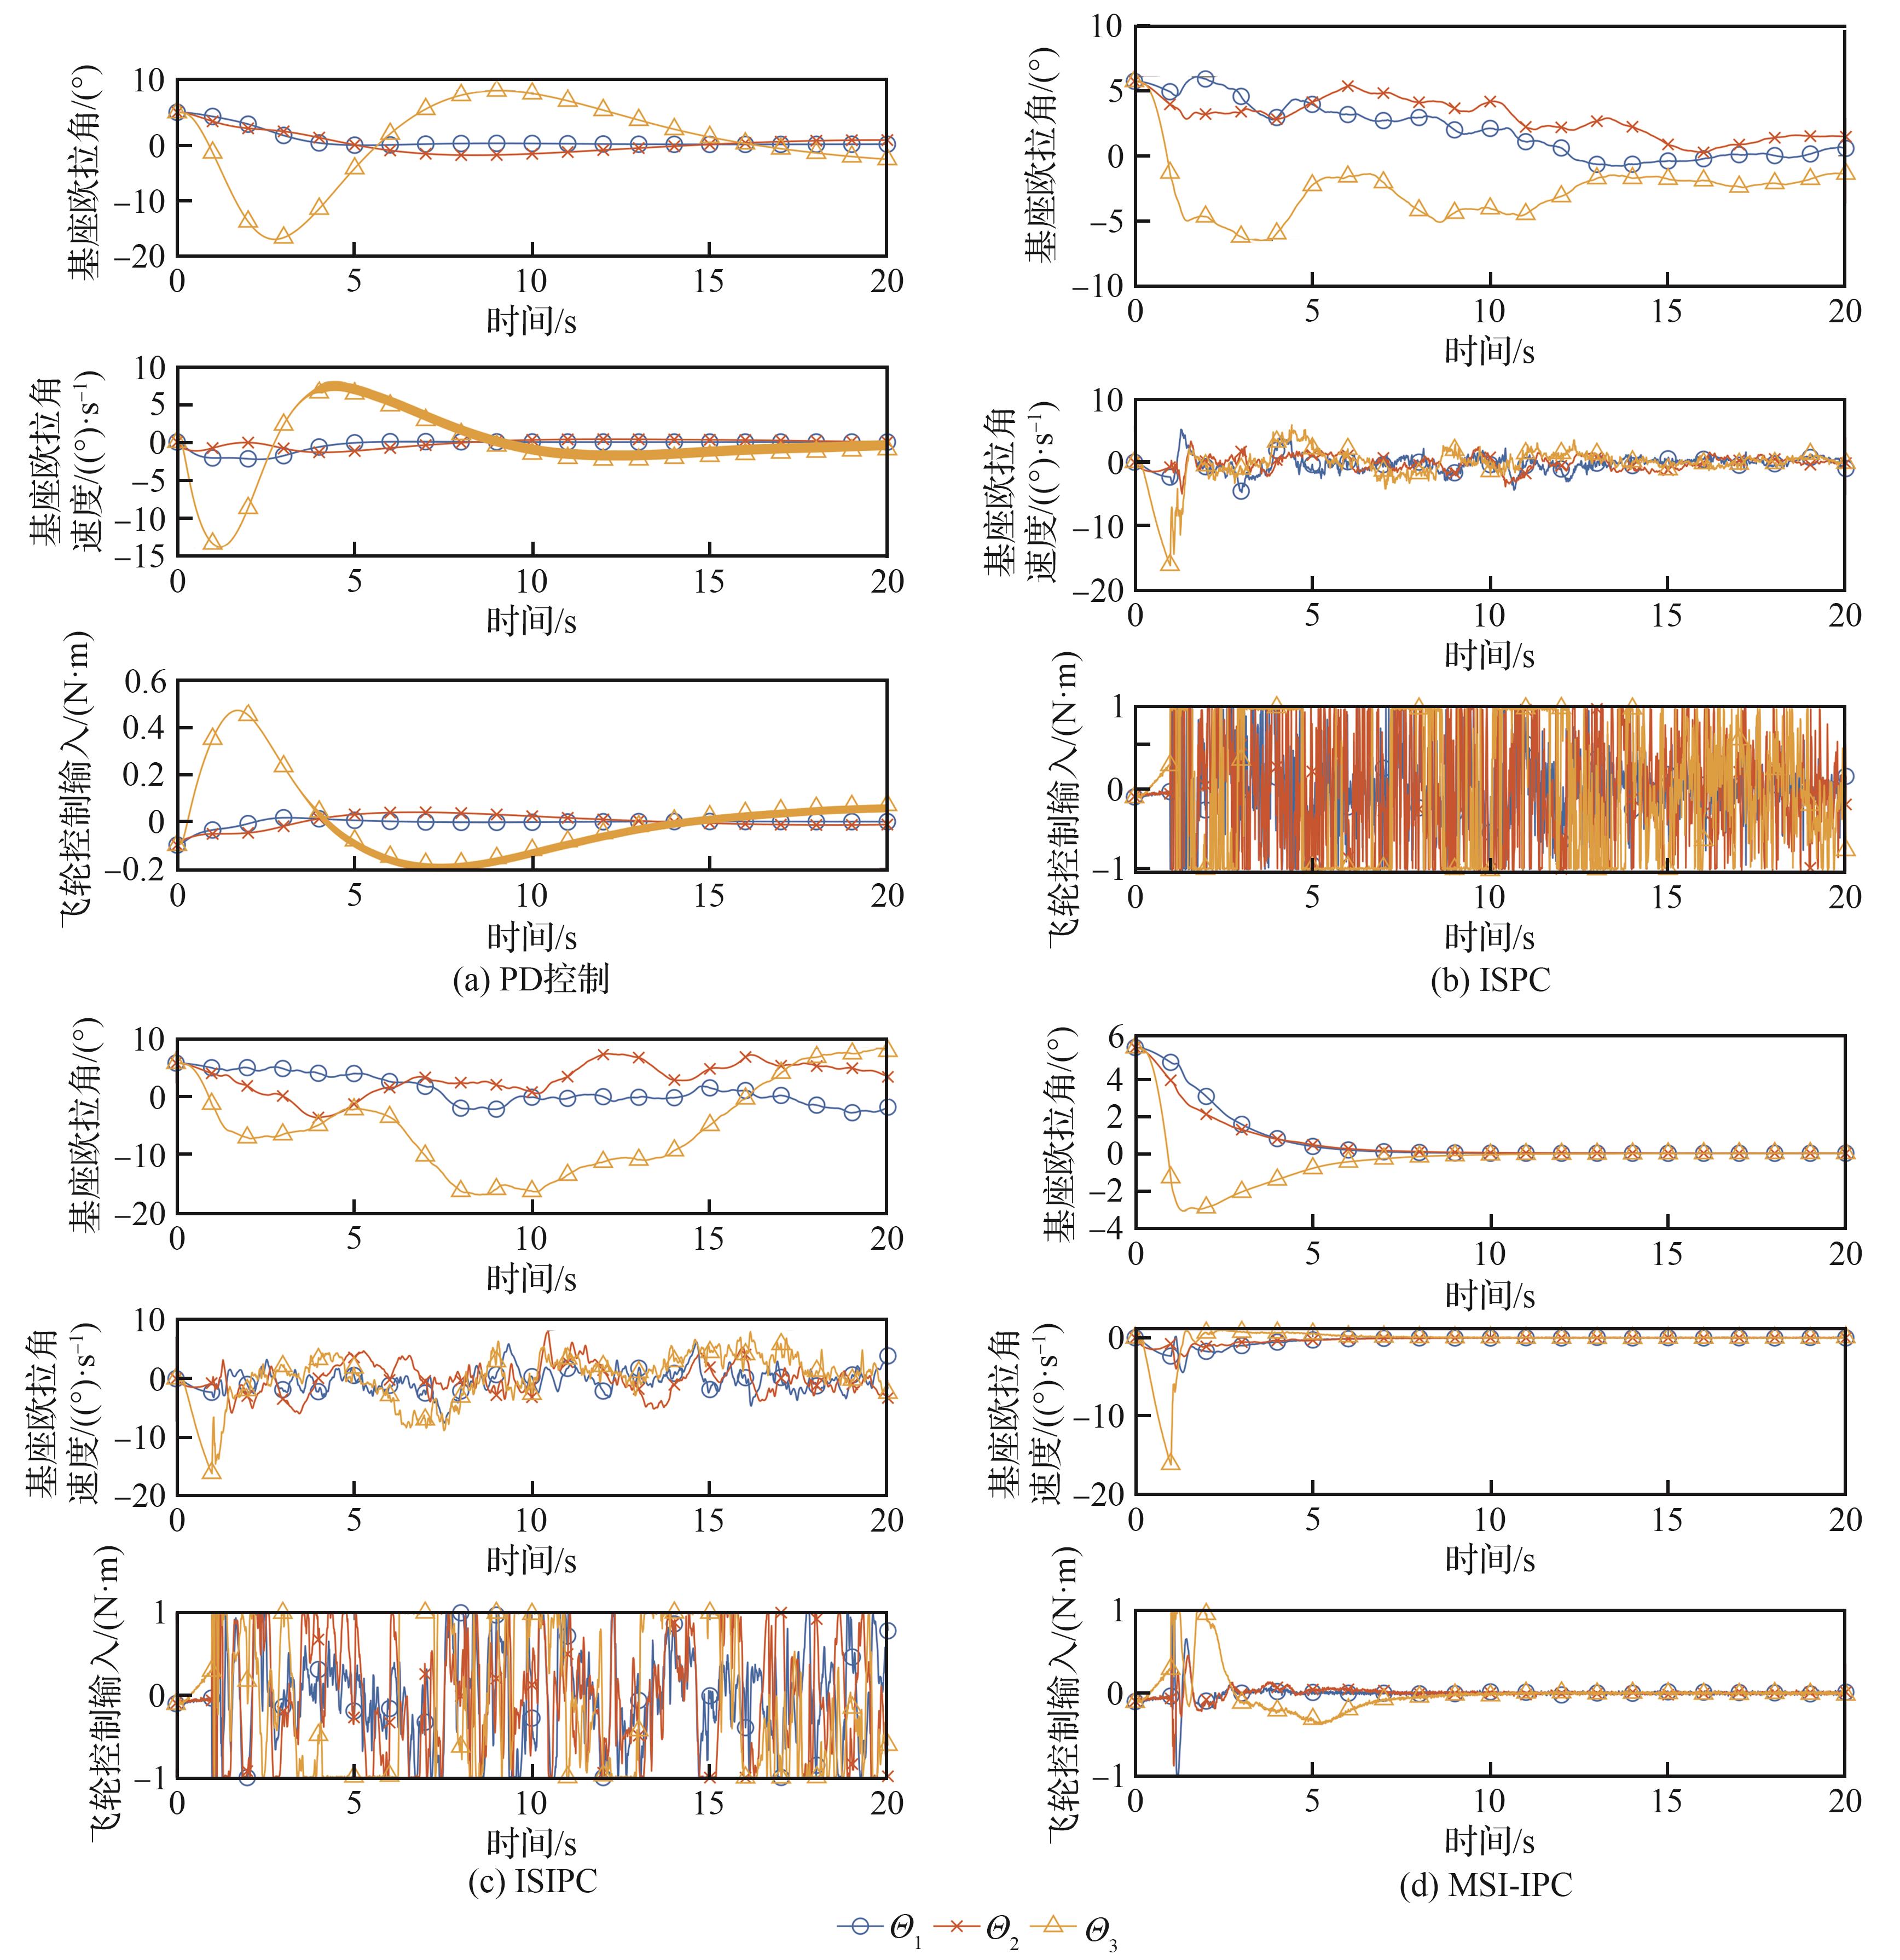
Fig.5
Joint angle, angular rate and motor control input (capturing target under Configuration 1)
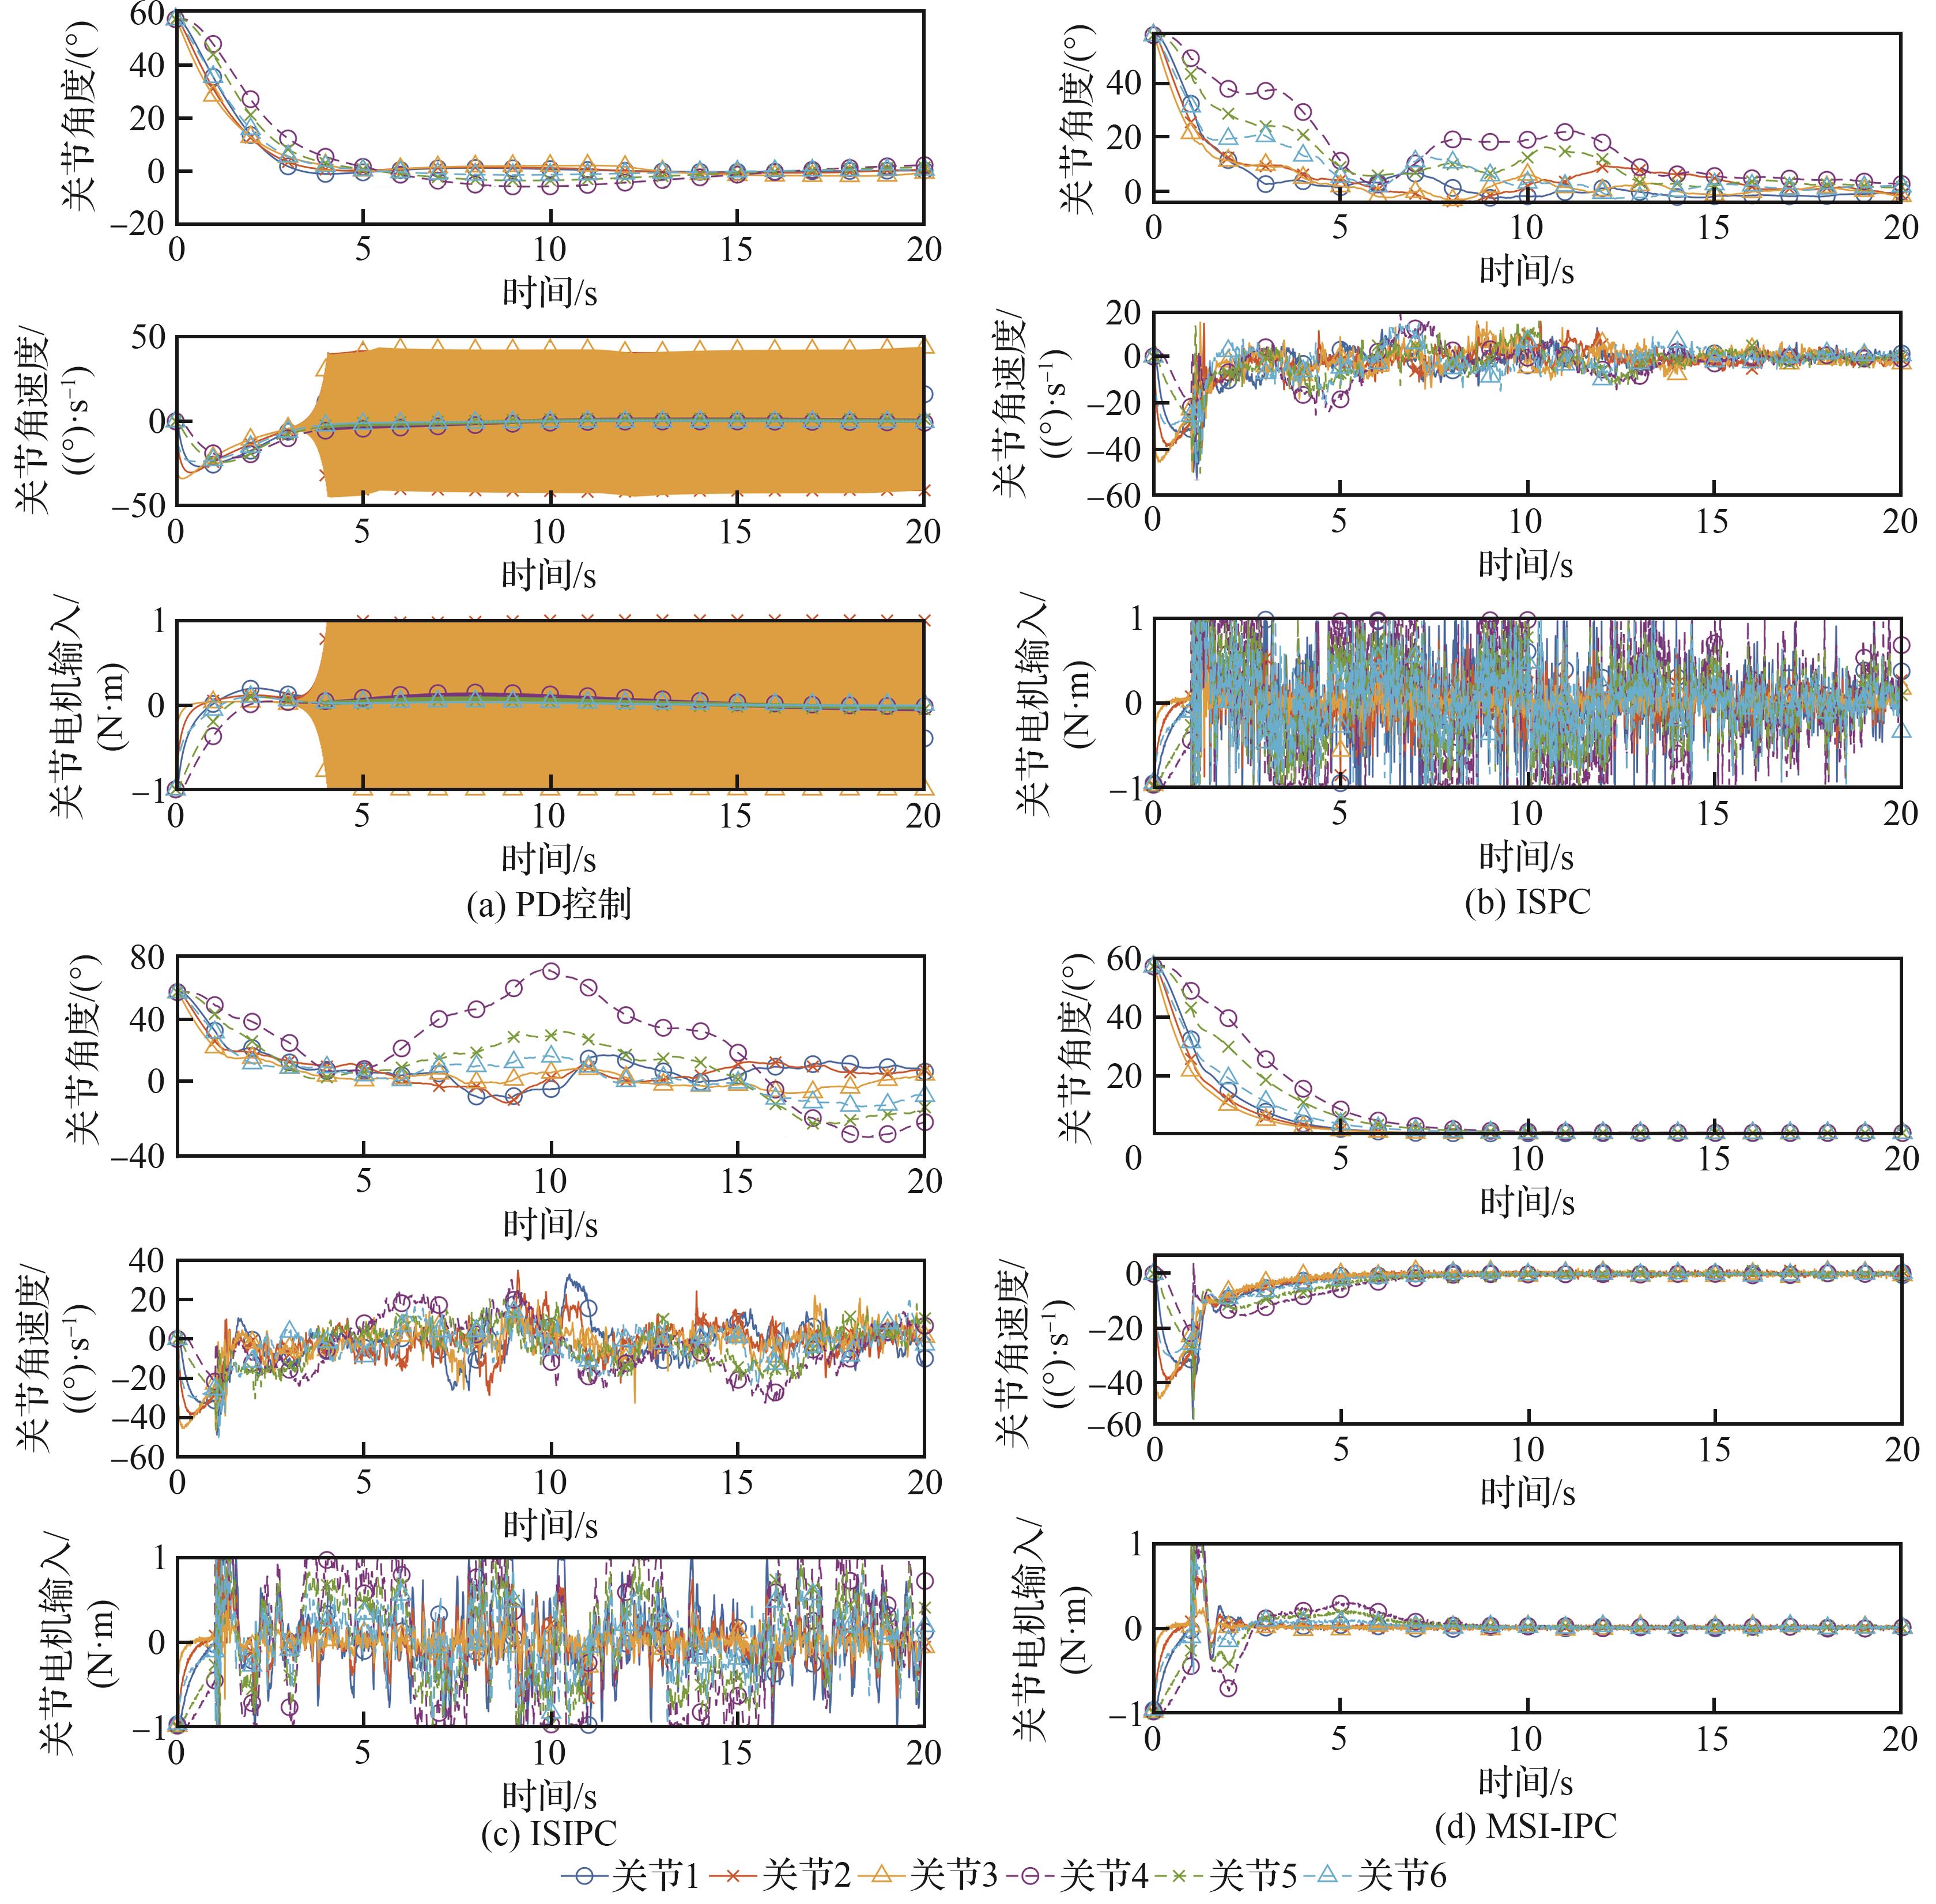
Table 4
State accuracy and control input consumption(Configuration 1)
| 稳态性能/控制方法 | PD | ISPC | ISIPC | MSI-IPC |
|---|---|---|---|---|
| 基座位置/m | 0.055 5 | 0.061 9 | 0.248 | 0.285×10⁻³ |
| 基座姿态角/(°) | 1.07 | 1.15 | 4.88 | 0.798×10⁻³ |
| 关节角/(°) | 1.18 | 1.45 | 13.3 | 0.012 8 |
| 喷管控制输入/N | 0.855 | 0.569 | 0.827 | 0.008 60 |
| 飞轮控制输入/(N·m) | 0.064 | 0.276 | 0.558 | 0.009 32 |
| 关节电机输入/(N·m) | 0.022 9 | 0.159 | 0.225 | 0.00 947 |
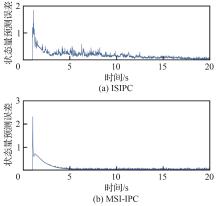
Fig.6
State variable prediction error of MSI-IPC and ISIPC methods
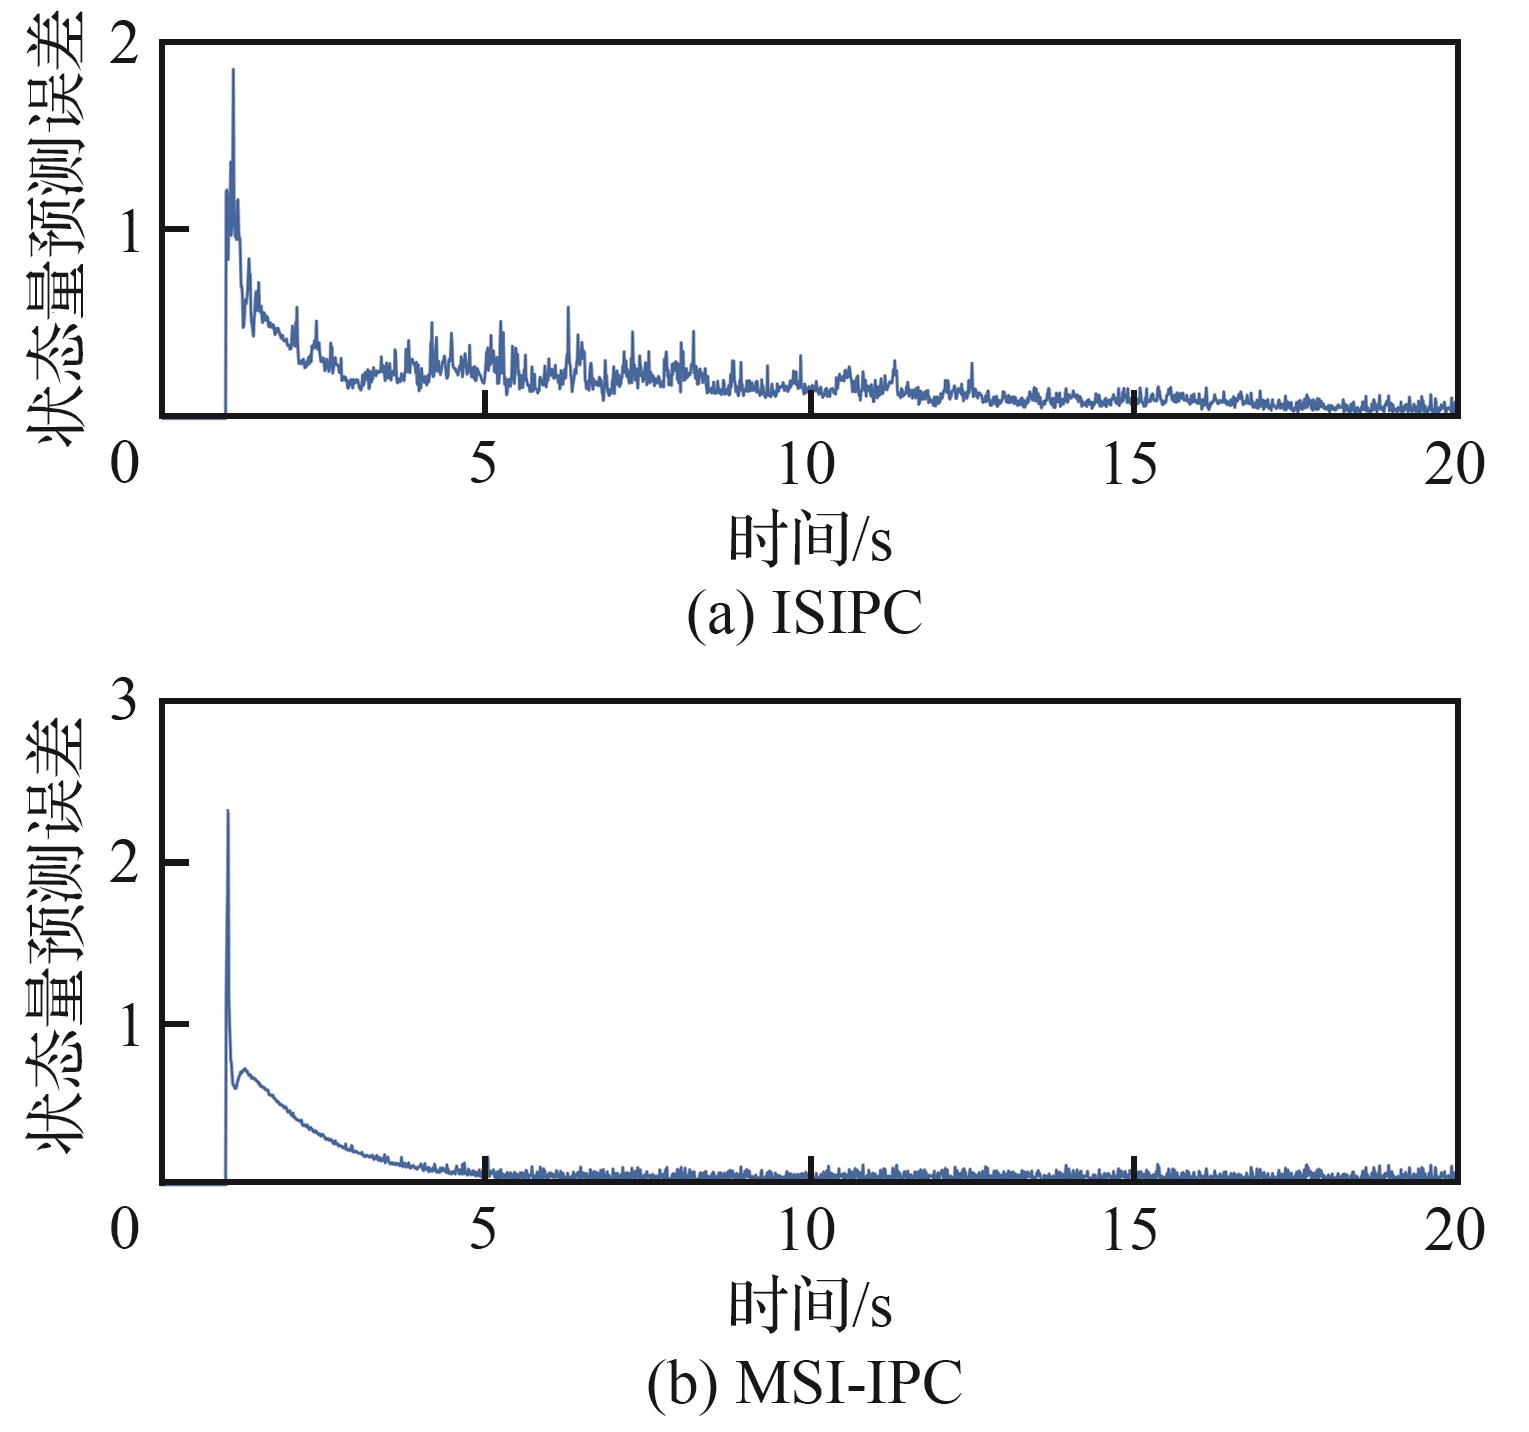
Fig.7
Simulation results under MSI-IPC without capturing target at end (Configuration 1)
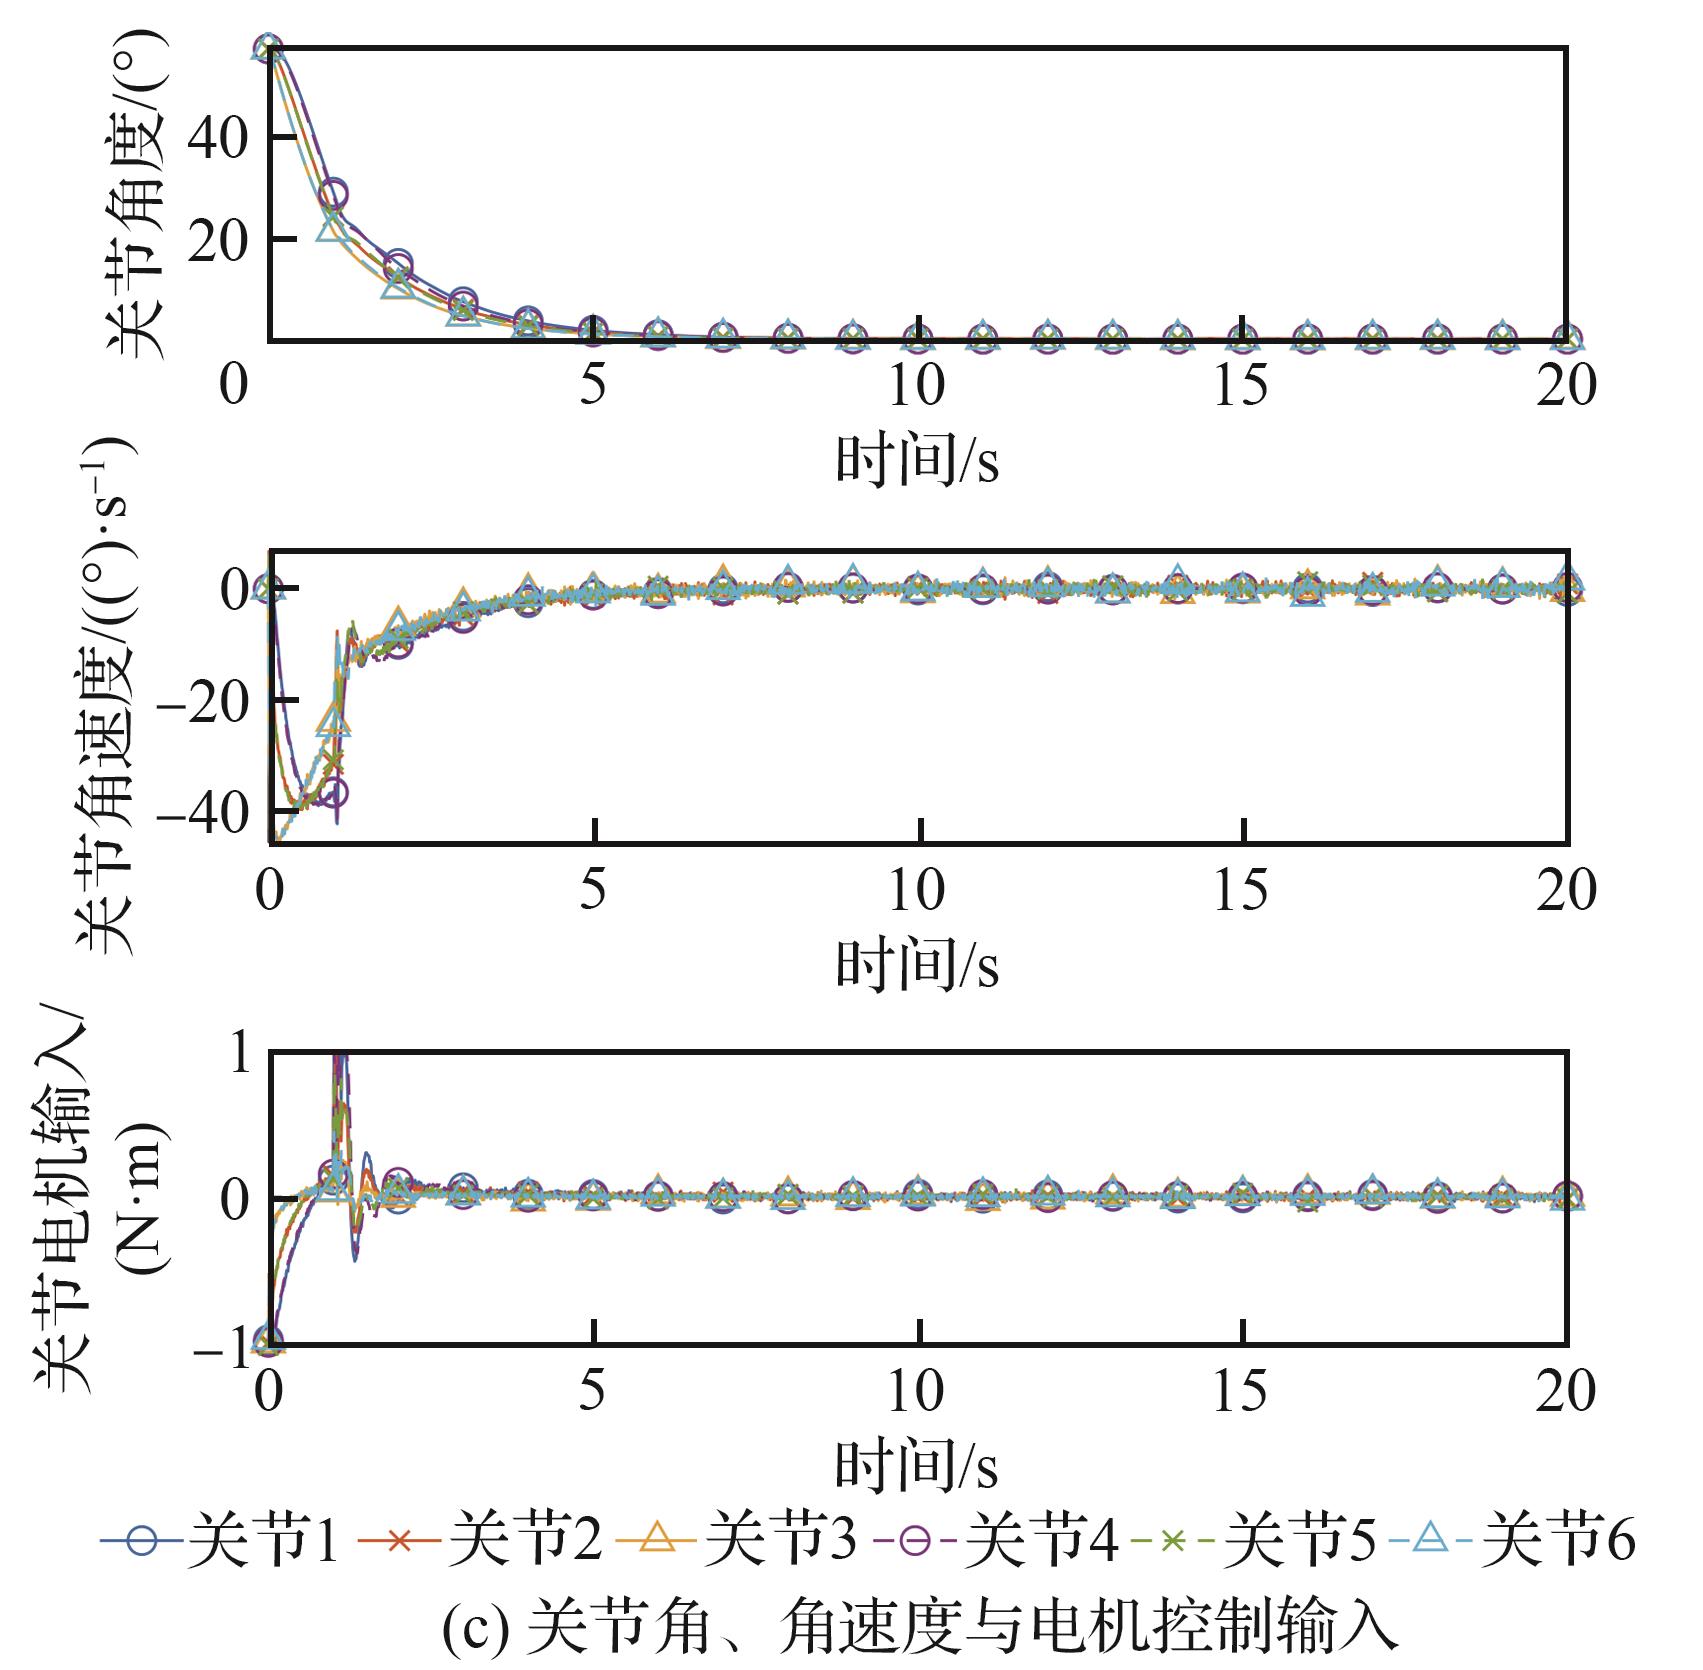
Fig.8
Simulation results under MIPC without capturing target at the end (Configuration 1)
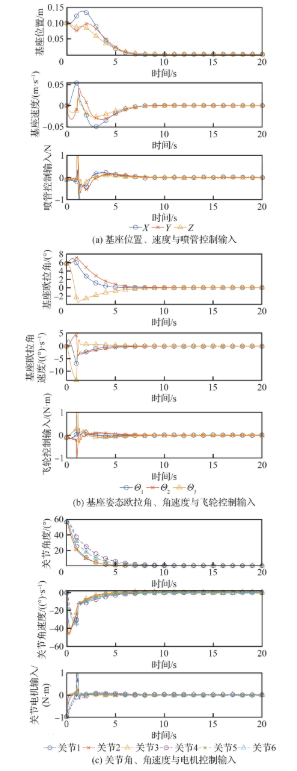
Table 5
State accuracy and control input consumption (Figs. 7 and 8)
| 稳态性能/控制方法 | MIPC | MSI-IPC |
|---|---|---|
| 基座位置/mm | 0.131 | 0.145 |
| 基座姿态角/(10-3(°)) | 1.217 | 1.256 |
| 关节角/(10-3(°)) | 21.610 | 21.548 |
| 喷管控制输入/(10-3 N) | 8.447 | 8.442 |
| 飞轮控制输入/(10-3 N·m) | 9.369 | 9.365 |
| 关节电机控制输入/(10-3 N·m) | 9.909 | 9.910 |
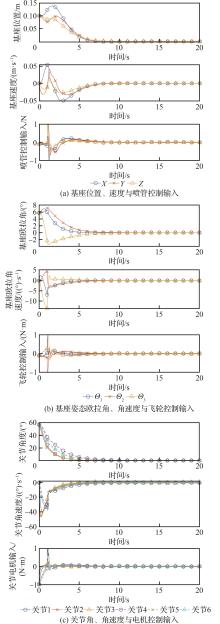
Fig.9
Simulation results with capturing target at the end (Configuration 2)
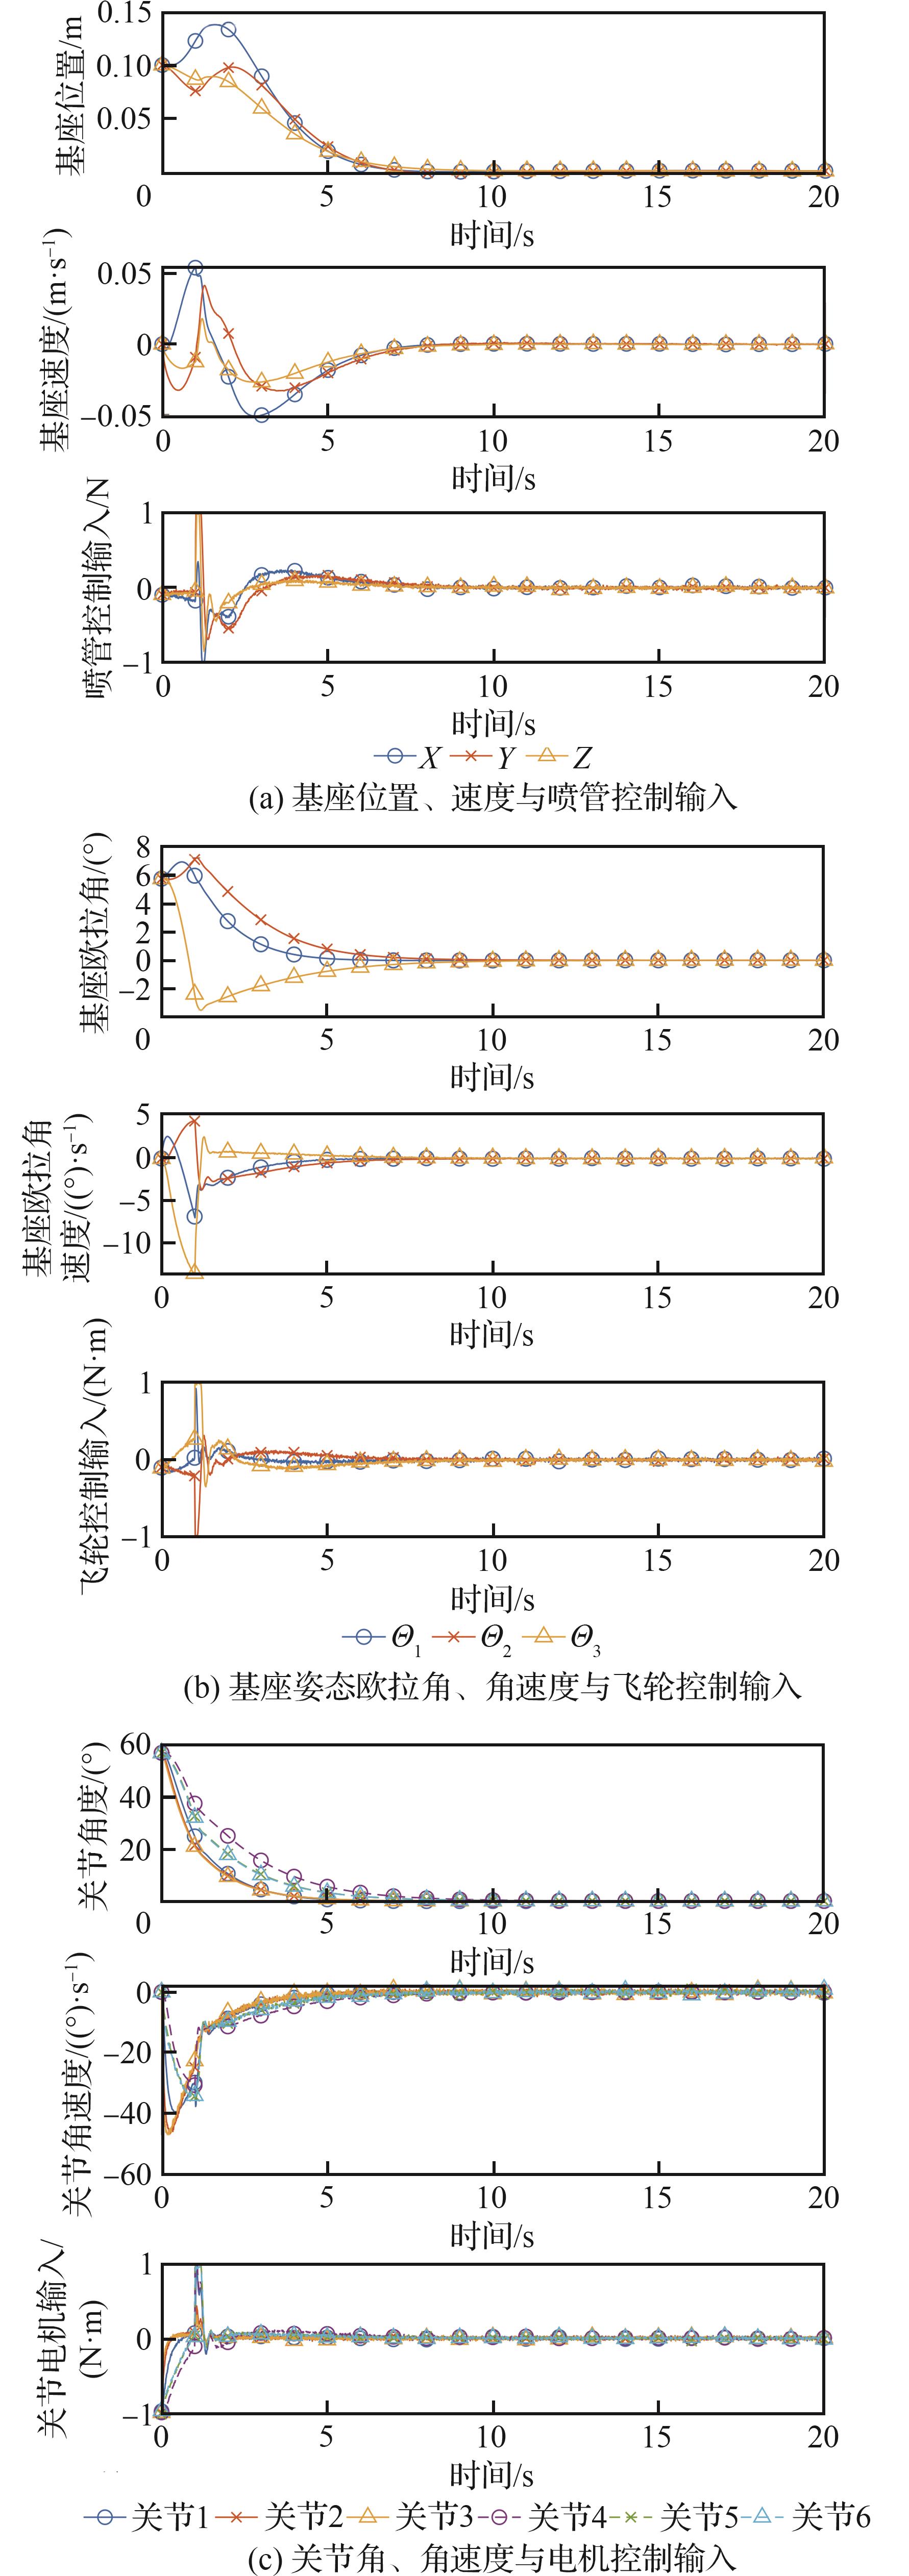
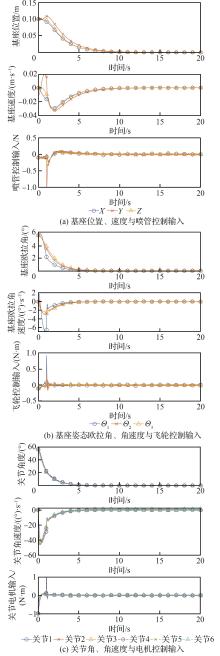
Fig.10
Simulation results without capturing target at the end (Configuration 2)
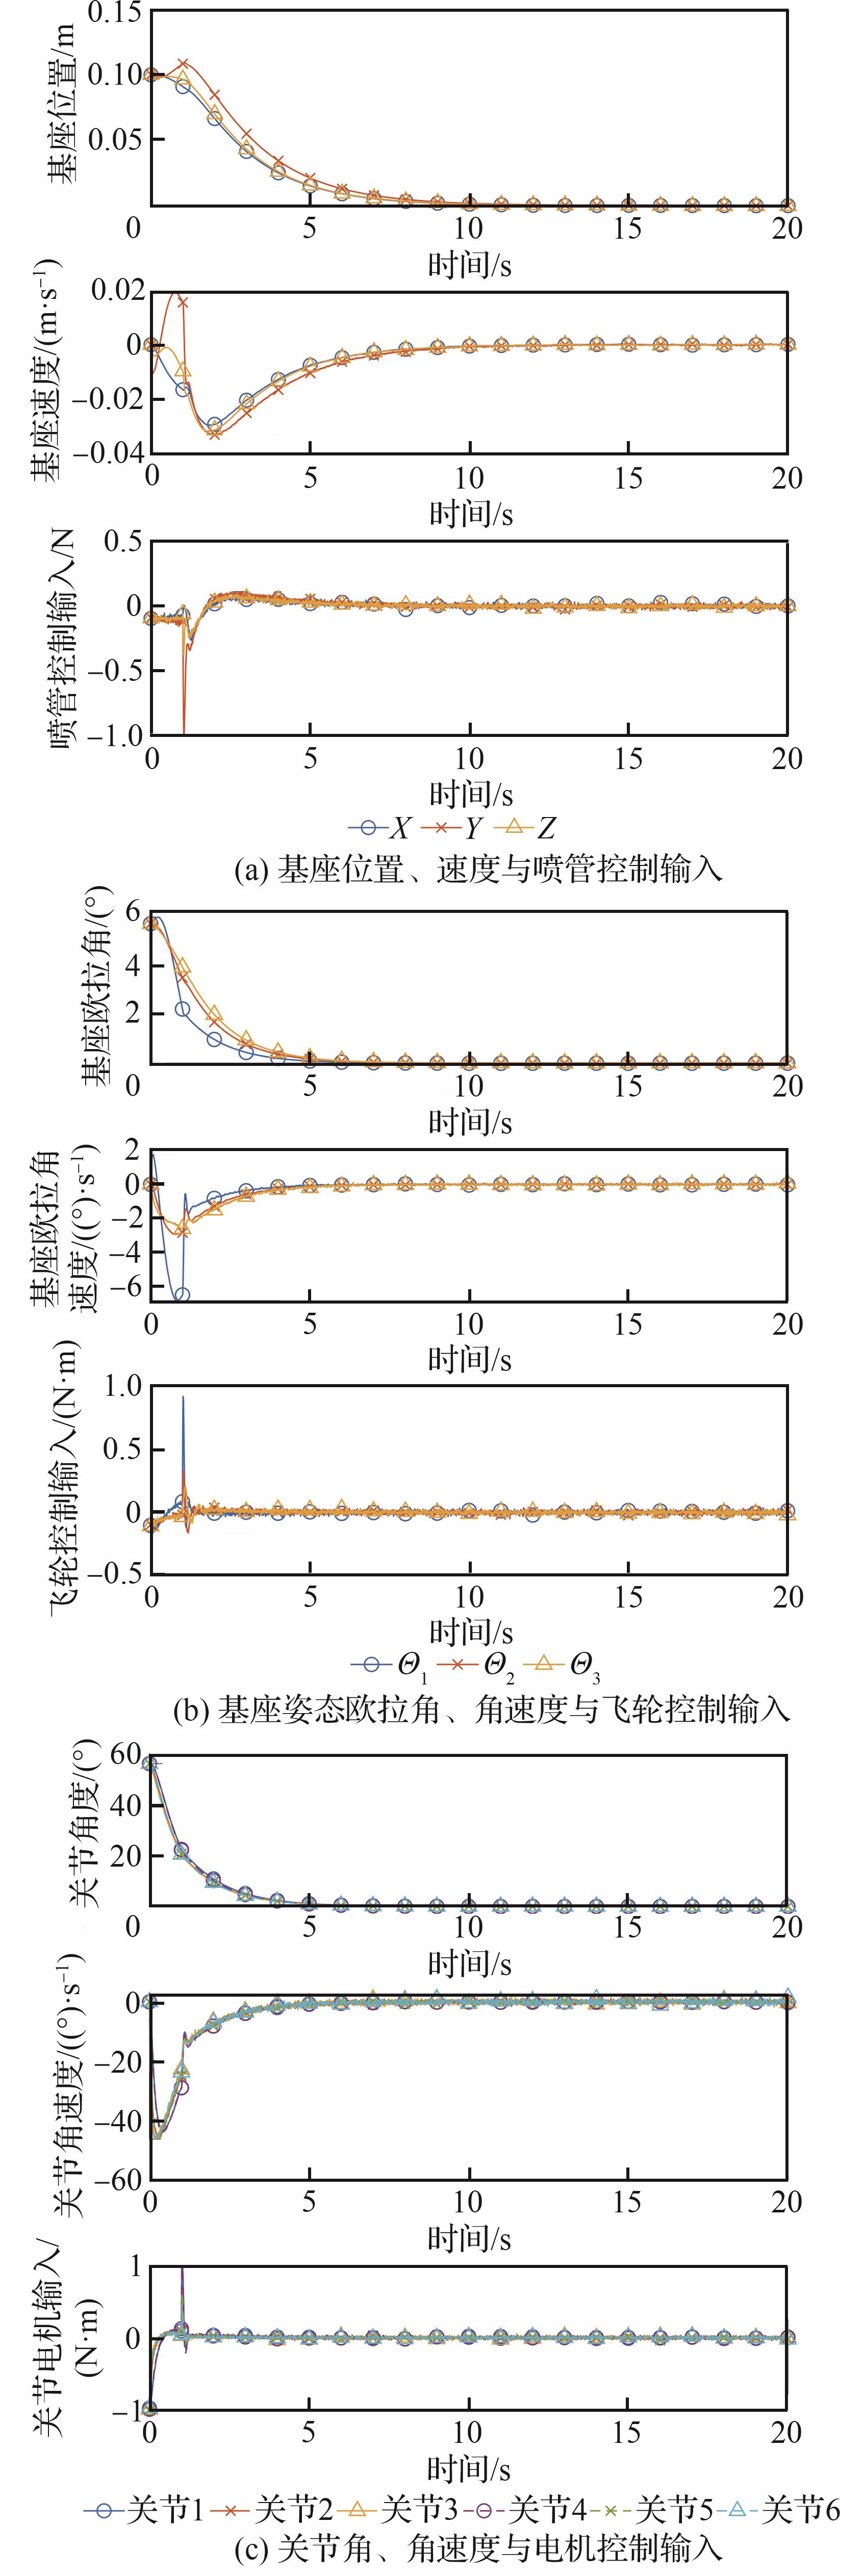
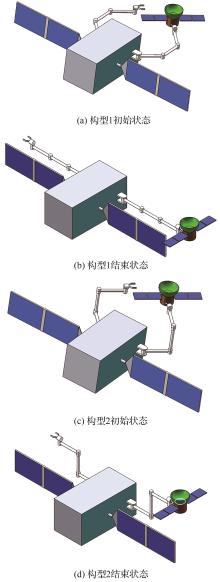
Fig.11
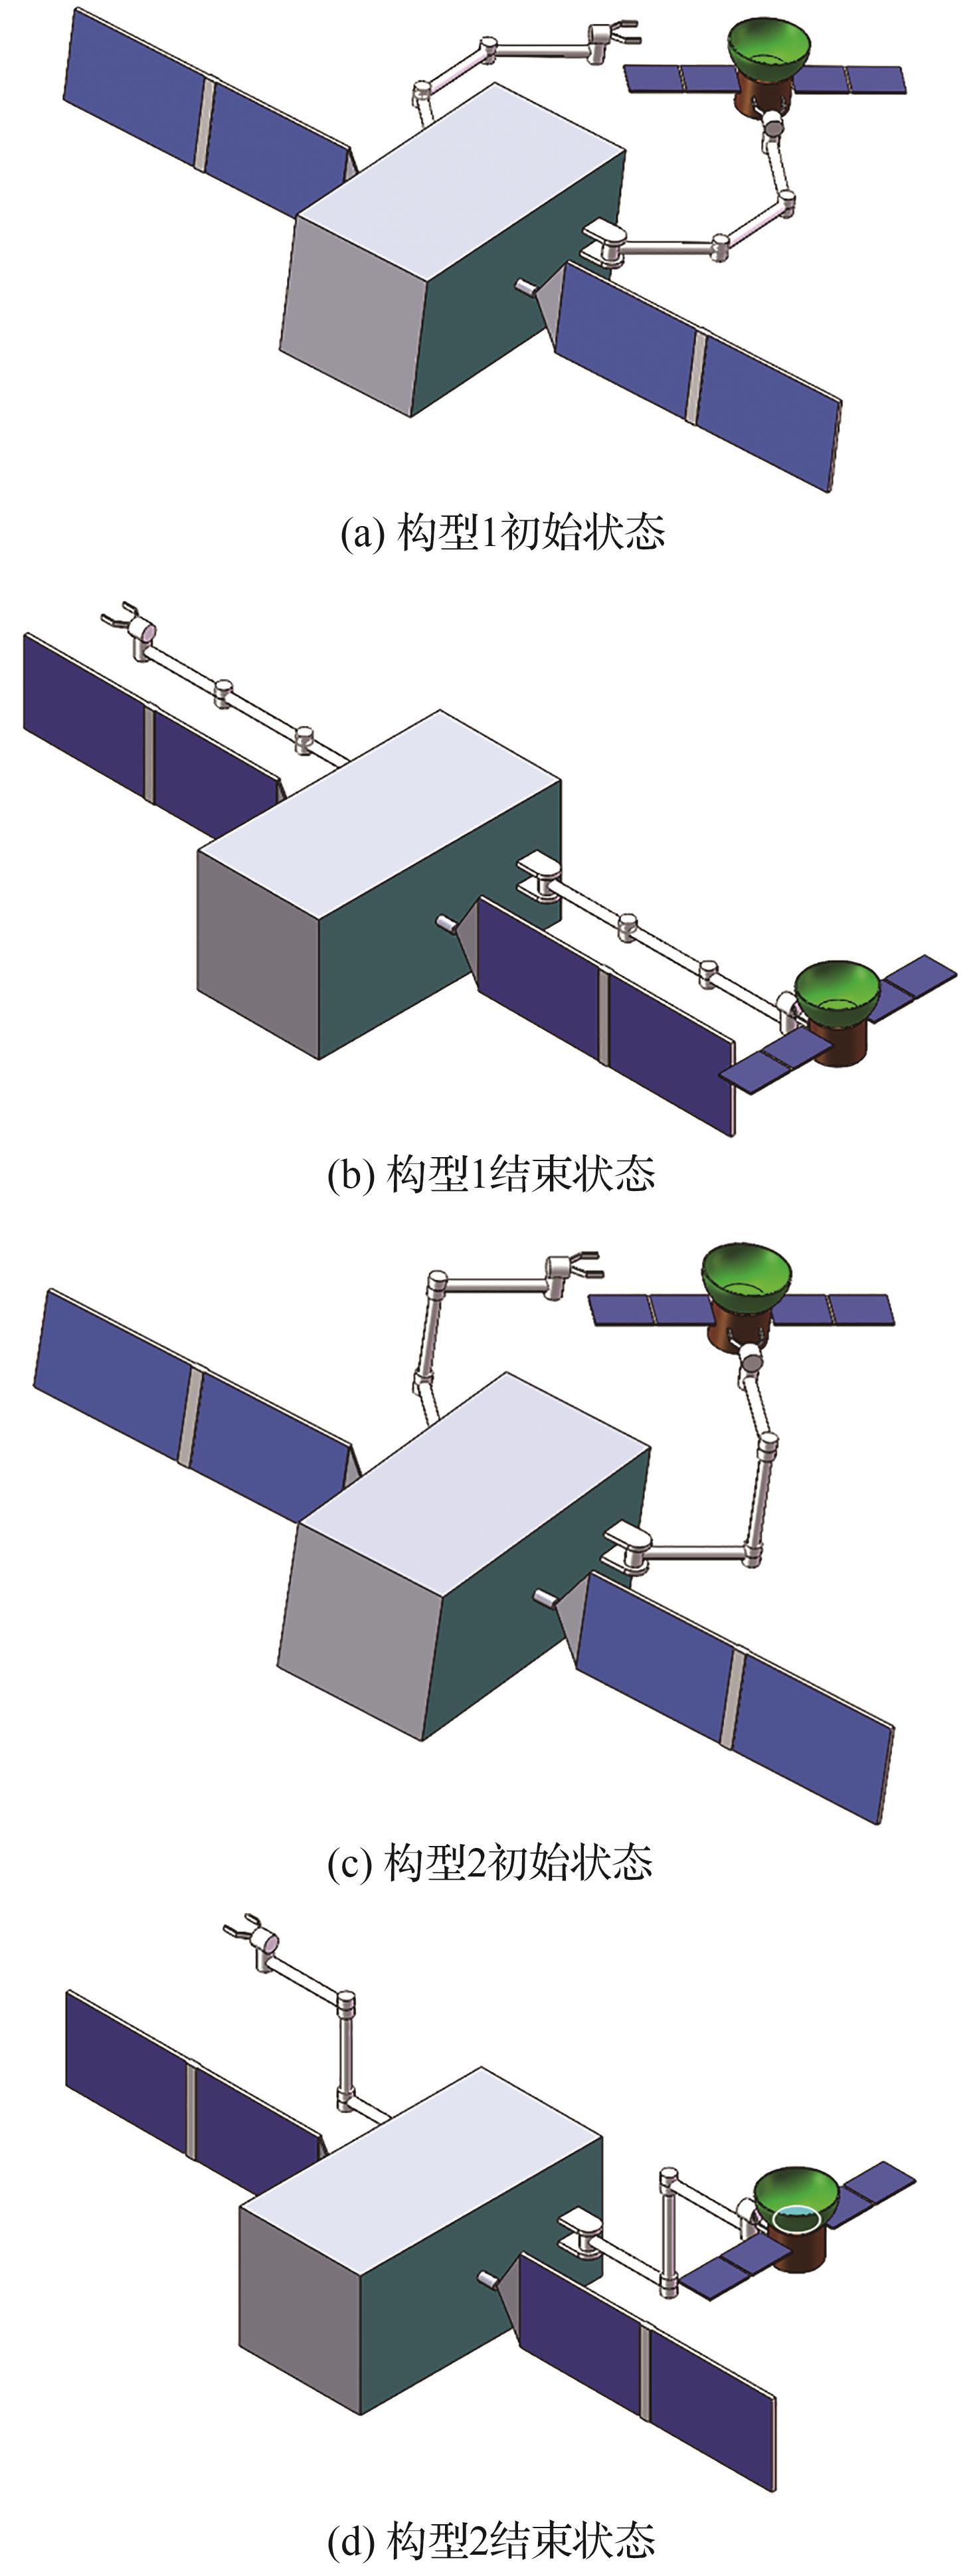
Visualization of simulation results for Configuration 1 (Fig. 7) and Configuration 2 (Fig. 10)
| [1] | CHEN G, WANG Y Q, WANG Y F, et al. Detumbling strategy based on friction control of dual-arm space robot for capturing tumbling target[J]. Chinese Journal of Aeronautics, 2020, 33(3): 1093-1106. |
| [2] | 徐升, 褚明, 蔺绍奇, 等. 非合作目标软捕获后的动力学参数无激励辨识[J]. 航空学报, 2023, 44(19): 228342. |
| XU S, CHU M, LIN S Q, et al. Dynamic parameter identification without excitation for non-cooperative targets post soft capture[J]. Acta Aeronautica et Astronautica Sinica, 2023, 44(19): 228342 (in Chinese). | |
| [3] | 夏鹏程, 罗建军, 王明明, 等. 空间双臂机器人抓捕非合作目标后的协调稳定控制[J]. 航空学报, 2022, 43(2): 325398. |
| XIA P C, LUO J J, WANG M M, et al. Coordinated stabilization control for dual-arm space robot capturing a non-cooperative target[J]. Acta Aeronautica et Astronautica Sinica, 2022, 43(2): 325398 (in Chinese). | |
| [4] | LU L, YUE C F, SHEN Q, et al. Hierarchical passivity-based force-position-configuration coordinated control of multi-branch spacecraft[J]. IEEE Transactions on Aerospace and Electronic Systems, 2025, 61(2): 4223-4237. |
| [5] | YUE C F, LIN T, ZHANG X, et al. Hierarchical path planning for multi-arm spacecraft with general translational and rotational locomotion mode[J]. Science China Technological Sciences, 2023, 66(4): 1180-1191. |
| [6] | YANG Z Y, LAI M Z, QI J, et al. Reorientation and obstacle avoidance control of free-floating modular robots using sinusoidal oscillator[J]. Chinese Journal of Aeronautics, 2024, 37(6): 262-275. |
| [7] | 赵浩天, 邱实, 刘明, 等. 基于全生命周期数据驱动的通讯卫星行波管退化评估方法[J]. 航空学报, 2025, 46(12): 331376. |
| ZHAO H T, QIU S, LIU M, et al. Degradation evaluation method for communication satellite traveling wave tubes based on full life cycle data[J]. Acta Aeronautica et Astronautica Sinica, 2025, 46(12): 331376 (in Chinese). | |
| [8] | SUN C, YUAN J P, ZHU Z X. Neural adaptive control for a ground experiment of the space proximity operation in a six-degree-of-freedom micro-gravity simulation system[J]. Chinese Journal of Aeronautics, 2020, 33(9): 2420-2433. |
| [9] | WANG D, GAO N, LIU D R, et al. Recent progress in reinforcement learning and adaptive dynamic programming for advanced control applications[J]. IEEE/CAA Journal of Automatica Sinica, 2024, 11(1): 18-36. |
| [10] | WU Y H, YU Z C, LI C Y, et al. Reinforcement learning in dual-arm trajectory planning for a free-floating space robot[J]. Aerospace Science and Technology, 2020, 98: 105657. |
| [11] | SONG B Y, LI J Q, LIU X Y, et al. A trajectory planning method for capture operation of space robotic arm based on deep reinforcement learning[J]. Journal of Computing and Information Science in Engineering, 2024, 24(9): 091003. |
| [12] | SUN Q, JIA Y M. Adaptive dynamic programming-based tracking control for free-floating space manipulators[C]∥ 2024 IEEE 19th Conference on Industrial Electronics and Applications (ICIEA). Piscataway: IEEE Press, 2024: 1-6. |
| [13] | ZHANG Z G, MA T H, ZHAO Y D, et al. Adaptive dynamic programming-based multi-fault tolerant control of reconfigurable manipulator with input constraint[J]. Complex & Intelligent Systems, 2024, 10(6): 8341-8353. |
| [14] | ZHANG Y H, ZOU L, LIU Y, et al. A brief survey on nonlinear control using adaptive dynamic programming under engineering-oriented complexities[J]. International Journal of Systems Science, 2023, 54(8): 1855-1872. |
| [15] | SASSELLA A, BRESCHI V, FORMENTIN S. Data-driven design of explicit predictive controllers[C]∥ 2022 IEEE 61st Conference on Decision and Control (CDC). Piscataway: IEEE Press, 2023: 2821-2826. |
| [16] | DE PERSIS C, TESI P. Formulas for data-driven control: stabilization, optimality, and robustness[J]. IEEE Transactions on Automatic Control, 2020, 65(3): 909-924. |
| [17] | HUANG L B, COULSON J, LYGEROS J, et al. Decentralized data-enabled predictive control for power system oscillation damping[J]. IEEE Transactions on Control Systems Technology, 2022, 30(3): 1065-1077. |
| [18] | BERBERICH J, KÖHLER J, MÜLLER M A, et al. Linear tracking MPC for nonlinear systems: Part Ⅱ: The data-driven case[J]. IEEE Transactions on Automatic Control, 2022, 67(9): 4406-4421. |
| [19] | ZHANG X W, HAN M H, YIN X Y. Reduced-order Koopman modeling and predictive control of nonlinear processes[J]. Computers & Chemical Engineering, 2023, 179: 108440. |
| [20] | KADALI R, HUANG B, ROSSITER A. A data driven subspace approach to predictive controller design[J]. Control Engineering Practice, 2003, 11(3): 261-278. |
| [21] | BRESCHI V, HAMDAN T BOU, MERCÈRE G, et al. Tuning of subspace predictive controls[J]. IFAC-PapersOnLine, 2023, 56(3): 103-108. |
| [22] | YE H, LIU Y T. Online recursive closed-loop state space model identification for damping control[C]∥ 2010 Asia-Pacific Power and Energy Engineering Conference. Piscataway: IEEE Press, 2010: 1-4. |
| [23] | KHALIL H K. Nonlinear Systems[M]. 3rd ed. Upper Saddle River: Prentice Hall, 2002: 144. |
| [24] | CAI B C, WEI C, YUE C F, et al. Artificial potential incorporated adaptive fixed-time sliding mode control for target capture[J]. Advances in Space Research, 2023, 72(4): 982-996. |
| [25] | 蔡璧丞. 空间非合作目标包络式抓捕优化与控制[D]. 哈尔滨: 哈尔滨工业大学, 2024: 26. |
| CAI B C. Research on optimization and control of non-cooperative target envelope capture[D]. Harbin: Harbin Institute of Technology, 2024: 26 (in Chinese) . | |
| [26] | GRÜNE L, PANNEK J, SEEHAFER M, et al. Analysis of unconstrained nonlinear MPC schemes with time varying control horizon[C]∥ 2012 IEEE 51st IEEE Conference on Decision and Control (CDC). Piscataway: IEEE Press, 2013: 2605-2610. |
| [27] | GRUNE L, RANTZER A. On the infinite horizon performance of receding horizon controllers[J]. IEEE Transactions on Automatic Control, 2008, 53(9): 2100-2111. |
| [1] | Qinbo SUN, Zhaohui DANG. Spacecraft guardian strategy design via motion-intent recognition [J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(S1): 733013-733013. |
| [2] | Kaikai DONG, Jiale WANG, Pengjin SHANG, Maozhang ZHENG, Zhiyu NI. Trajectory planning and control for space rendezvous with non-cooperative targets in line-of-sight coordinate system [J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(S1): 733005-733005. |
| [3] | Yiyu WANG, Zexu ZHANG, Weimin BAO, Shuai YUAN, Hutao CUI. Approaching trajectory planning with field-of-view constraints for non-cooperative spacecraft rendezvous [J]. Acta Aeronautica et Astronautica Sinica, 2025, 46(16): 331702-331702. |
| [4] | Sheng XU, Ming CHU, Shaoqi LIN, Rui CHANG, Hanxu SUN. Dynamic parameter identification without excitation for non-cooperative targets post soft capture [J]. Acta Aeronautica et Astronautica Sinica, 2023, 44(19): 228342-228342. |
| [5] | Ming CHU, Shaoqi LIN, Sheng XU, Rui CHANG. Design and simulation of omnidirectional compliant docking joint for space non-cooperative target [J]. Acta Aeronautica et Astronautica Sinica, 2023, 44(13): 428024-428024. |
| [6] | Bin CHEN, Houyin XI, Xiaodong ZHANG, Min LUO, Zhidong GUO. Point cloud registration of space non-cooperative targets based on geodesic distance [J]. ACTA AERONAUTICAET ASTRONAUTICA SINICA, 2023, 44(1): 326336-326336. |
| [7] | XIA Pengcheng, LUO Jianjun, WANG Mingming, TAN Longyu. Coordinated stabilization control for dual-arm space robot capturing a non-cooperative target [J]. ACTA AERONAUTICAET ASTRONAUTICA SINICA, 2022, 43(2): 325398-325398. |
| [8] | SUN Bowen, WANG Dayi, WANG Jiongqi, ZHOU Haiyin, GE Dongming, DONG Tianshu. Filter method for dimension reduction in spacecraft autonomous navigation based on sequence image [J]. ACTA AERONAUTICAET ASTRONAUTICA SINICA, 2021, 42(4): 524971-524971. |
| [9] | MU Jinzhen, LIU Zongming, HAN Fei, ZHOU Yan, LI Shuang. Long-range relative pose estimation and optimization of a failure satellite [J]. ACTA AERONAUTICAET ASTRONAUTICA SINICA, 2021, 42(11): 524959-524959. |
| [10] | WAN Wenya, SUN Chong, YUAN Jianping. Multi-finger caging-based gripping path design for space non-cooperative targets [J]. ACTA AERONAUTICAET ASTRONAUTICA SINICA, 2020, 41(12): 324041-324041. |
| [11] | LIU Bingyan, YE Xiongbing, GAO Yong, WANG Xinbo, NI Lei. Strategy solution of non-cooperative target pursuit-evasion game based on branching deep reinforcement learning [J]. ACTA AERONAUTICAET ASTRONAUTICA SINICA, 2020, 41(10): 324040-324040. |
| [12] | ZHU Yunfeng, SUN Yongrong, ZHAO Wei, HUANG Bin, WU Ling. Relative navigation algorithm for non-cooperative target with adaptive modification of multiplicative noise [J]. ACTA AERONAUTICAET ASTRONAUTICA SINICA, 2019, 40(7): 322884-322884. |
| [13] | YU Dateng, WANG Hua, SUN Fuyu. Optimal evasive maneuver strategy with potential threatening area being considered [J]. ACTA AERONAUTICAET ASTRONAUTICA SINICA, 2017, 38(1): 320202-320202. |
| [14] | CHEN Lu, HUANG Panfeng, CAI Jia. Space non-cooperative target detection based on improved features of histogram of oriented gradient [J]. ACTA AERONAUTICAET ASTRONAUTICA SINICA, 2016, 37(2): 717-726. |
| [15] | DAI Chong, XU Zhenhai, XIAO Shunping. Simulation Method of Dynamic RCS for Non-cooperative Targets [J]. ACTA AERONAUTICAET ASTRONAUTICA SINICA, 2014, 35(5): 1374-1384. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
Address: No.238, Baiyan Buiding, Beisihuan Zhonglu Road, Haidian District, Beijing, China
Postal code : 100083
E-mail:hkxb@buaa.edu.cn
Total visits: 6658907 Today visits: 1341All copyright © editorial office of Chinese Journal of Aeronautics
All copyright © editorial office of Chinese Journal of Aeronautics
Total visits: 6658907 Today visits: 1341

 CJA

