Acta Aeronautica et Astronautica Sinica ›› 2026, Vol. 47 ›› Issue (15): 333091.doi: 10.7527/S1000-6893.2025.33091
• Electronics and Electrical Engineering and Control • Previous Articles
Pengxuan WEI1, Hanlin SHENG1( ), Fengyun LI1, Yijie WANG1, Haolan SHI1, Jiacheng LI2, Qian CHEN1
Received:2025-11-17
Revised:2025-12-03
Accepted:2025-12-09
Online:2025-12-17
Published:2025-12-15
Contact:
Hanlin SHENG
E-mail:dreamshl@nuaa.edu.cn
Supported by:CLC Number:
Pengxuan WEI, Hanlin SHENG, Fengyun LI, Yijie WANG, Haolan SHI, Jiacheng LI, Qian CHEN. Hierarchical adaptive multi-mode fault-tolerant control method for UAVs[J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(15): 333091.
Table 1
Comparison of characteristics between the proposed method and SOTA methods
| 对比维度 | 本文方法 | 文献[ | 文献[ |
|---|---|---|---|
| 容错类型 | 主动容错 | 被动容错 | 主动容错 |
| 验证环境 | 机载传感器 | 机载传感器 | 依赖动捕系统 |
| 模型依赖 | 在线辨识 | 无需 | 精确模型 |
| 适用工况 | 无故障/部分/完全失效 | 无故障/部分/完全失效 | 无故障/ 完全失效 |
| 控制能力 | 动态轨迹精确跟踪 | 位置可行性 保持 | 动态轨迹精确跟踪 |
| 失效数量 | 1个 | 1、2、3个 | 1个 |
Fig.1
Quadrotor and its coordinate system definition
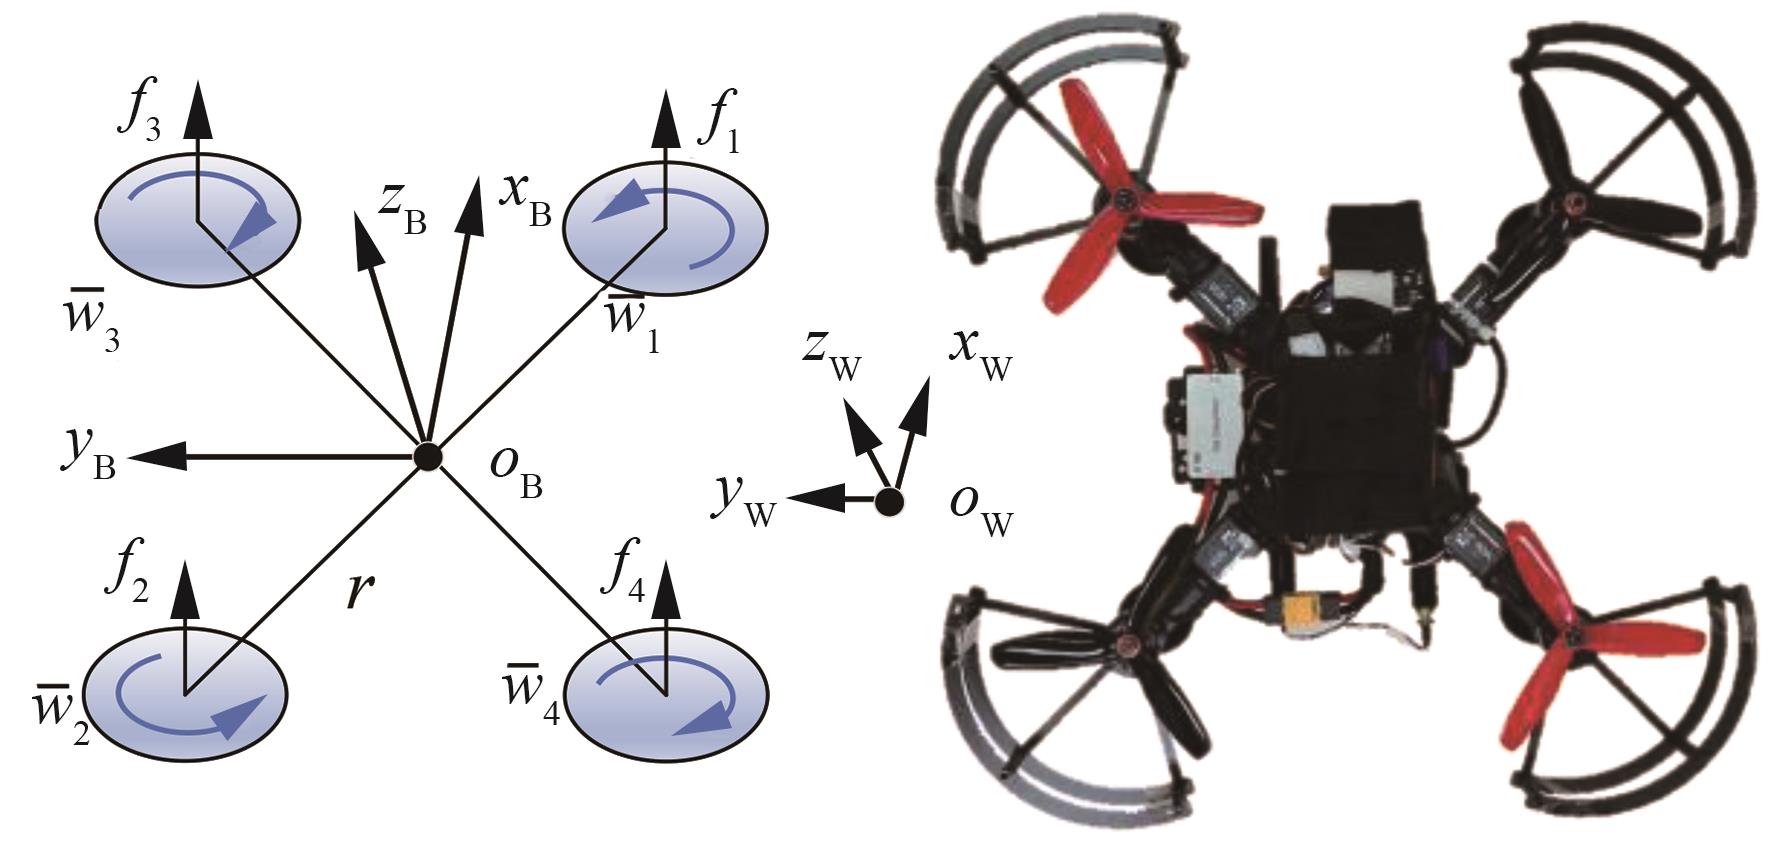
Fig.2
Block diagram of multi-mode fault-tolerant control structure
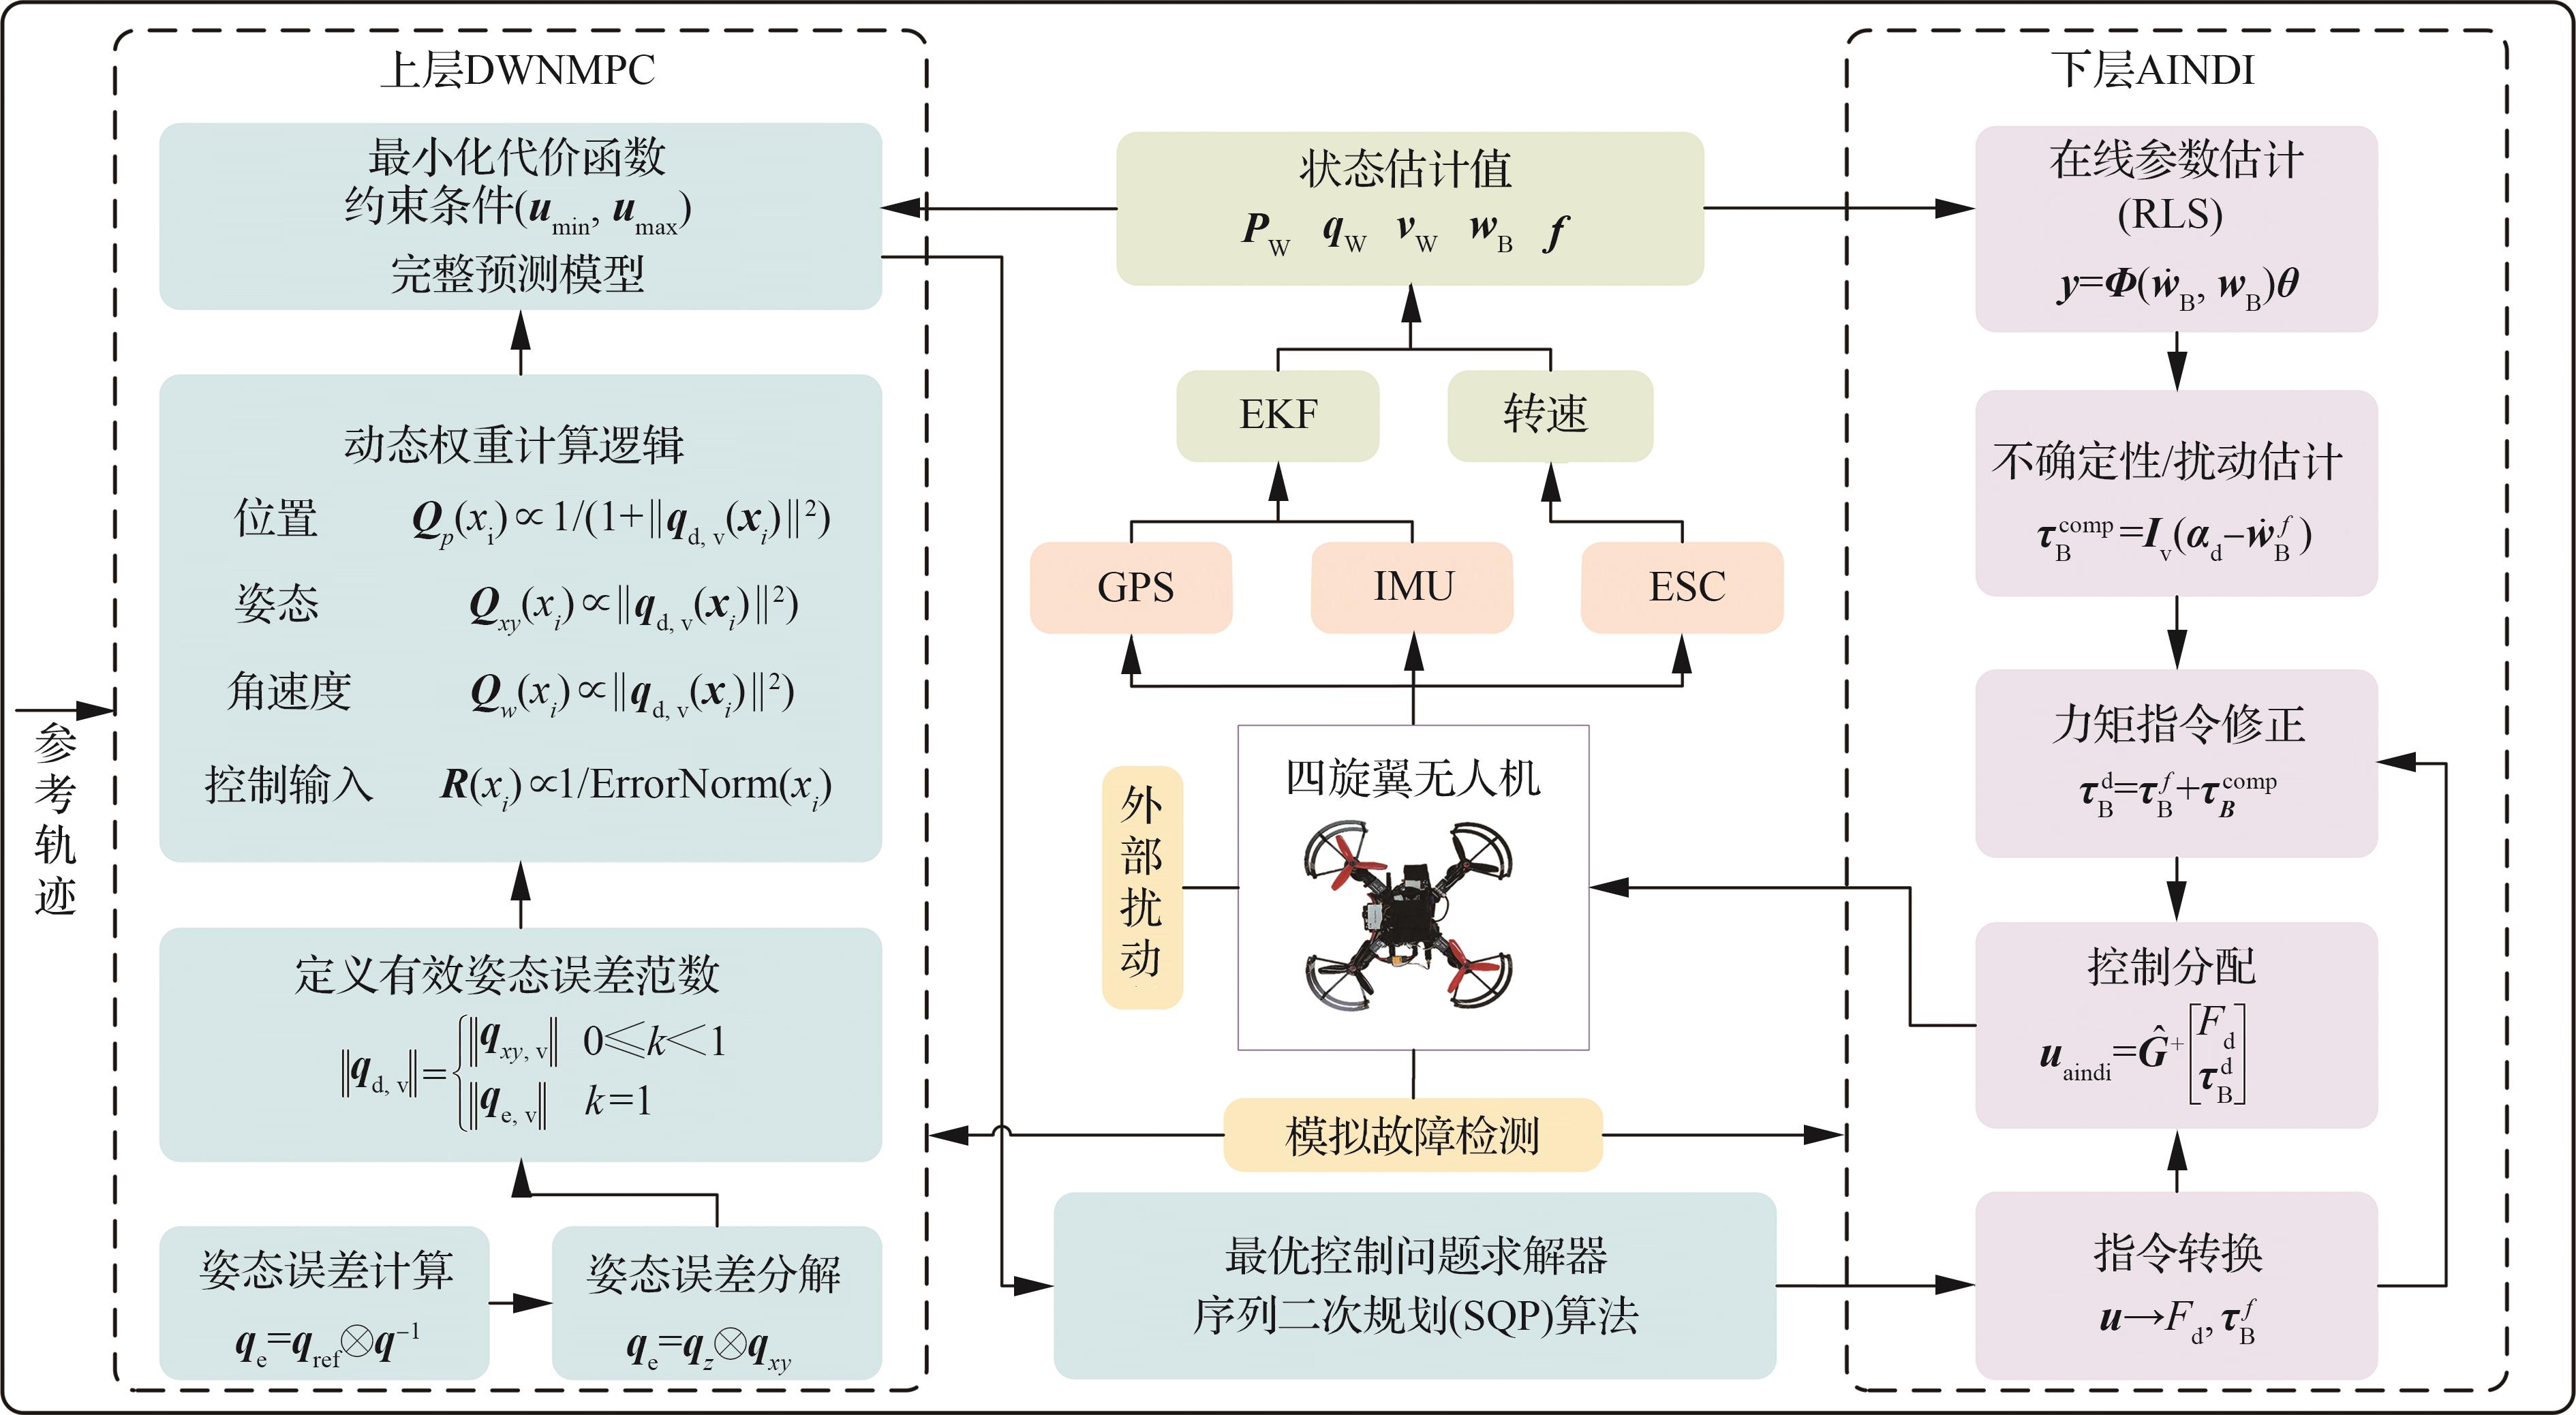
Table 2
Parameters of quadrotor UAV
| 参数 | 数值 | 参数 | 数值 |
|---|---|---|---|
| 1.505 | 0.018 75 | ||
| 0.06 | 14.4 | ||
| 0.147 45 | 0.011 | ||
| 0.145 25 | 0.016 | ||
| 8.548×10⁻⁶ | 0.022 |
Fig.3
Angular velocity and thrust of the quadcopter UAV in fault-free mode
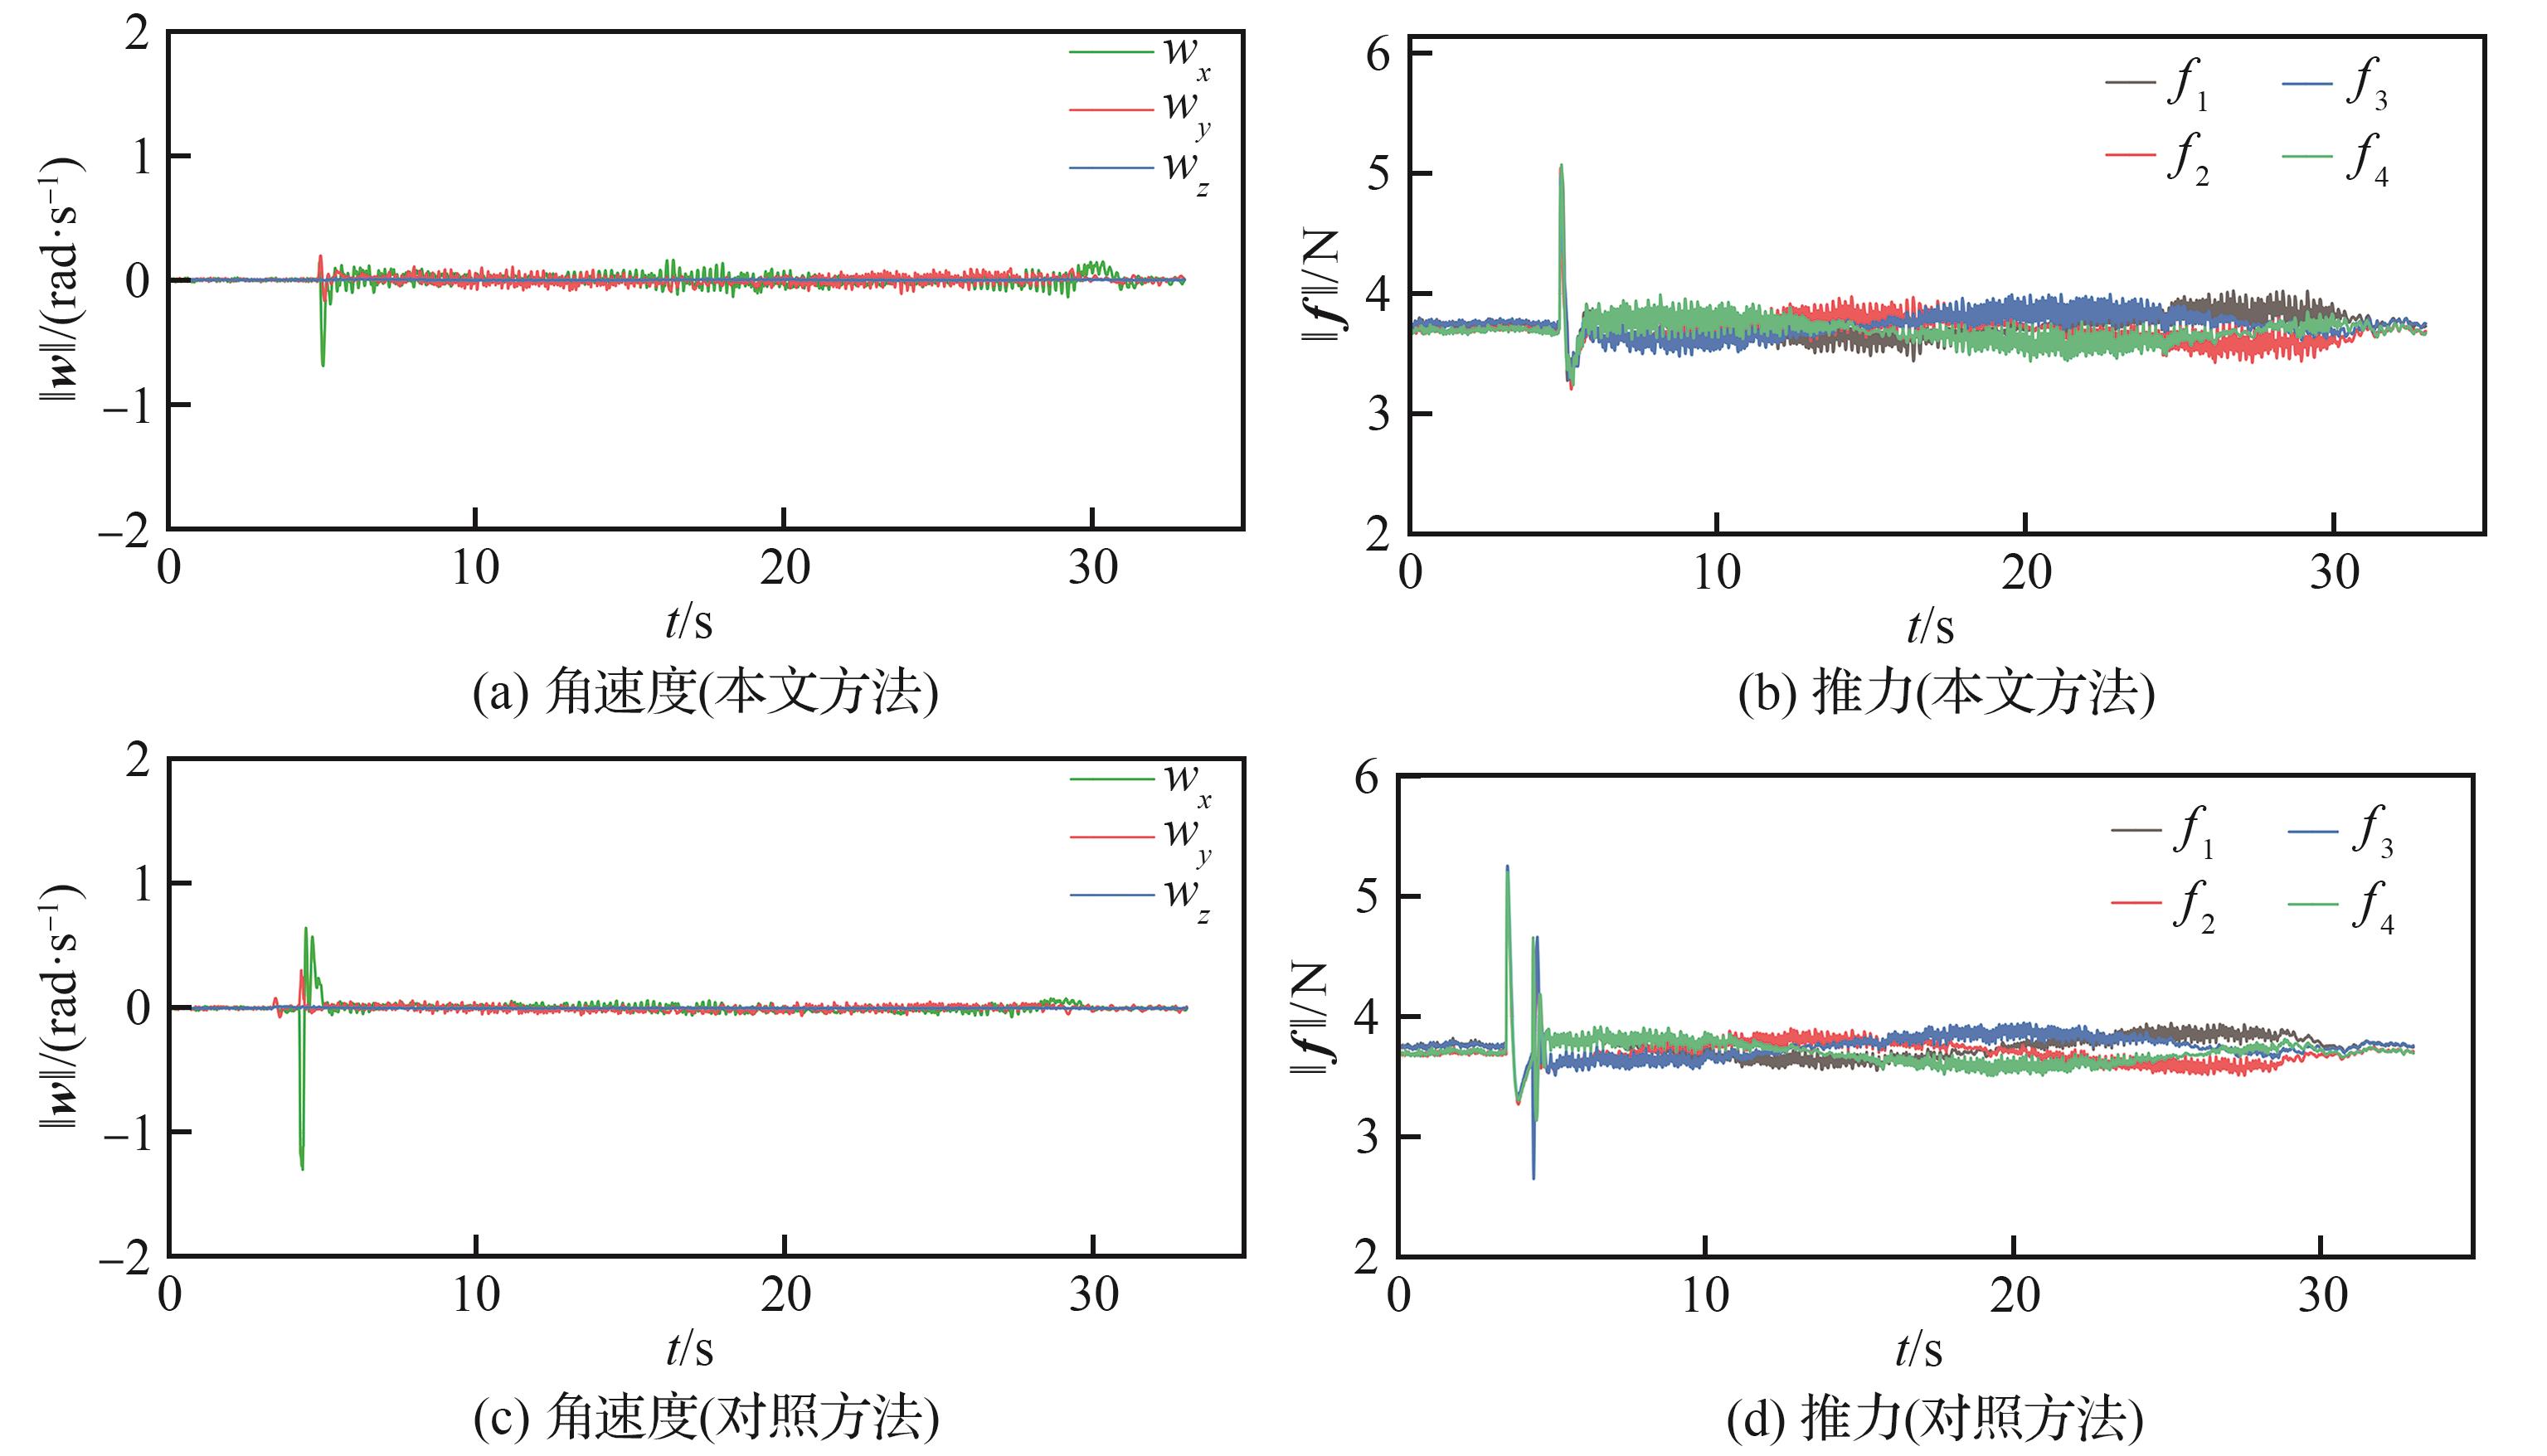
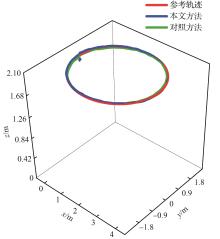
Fig.4
3D diagram of trajectory tracking in fault-free mode
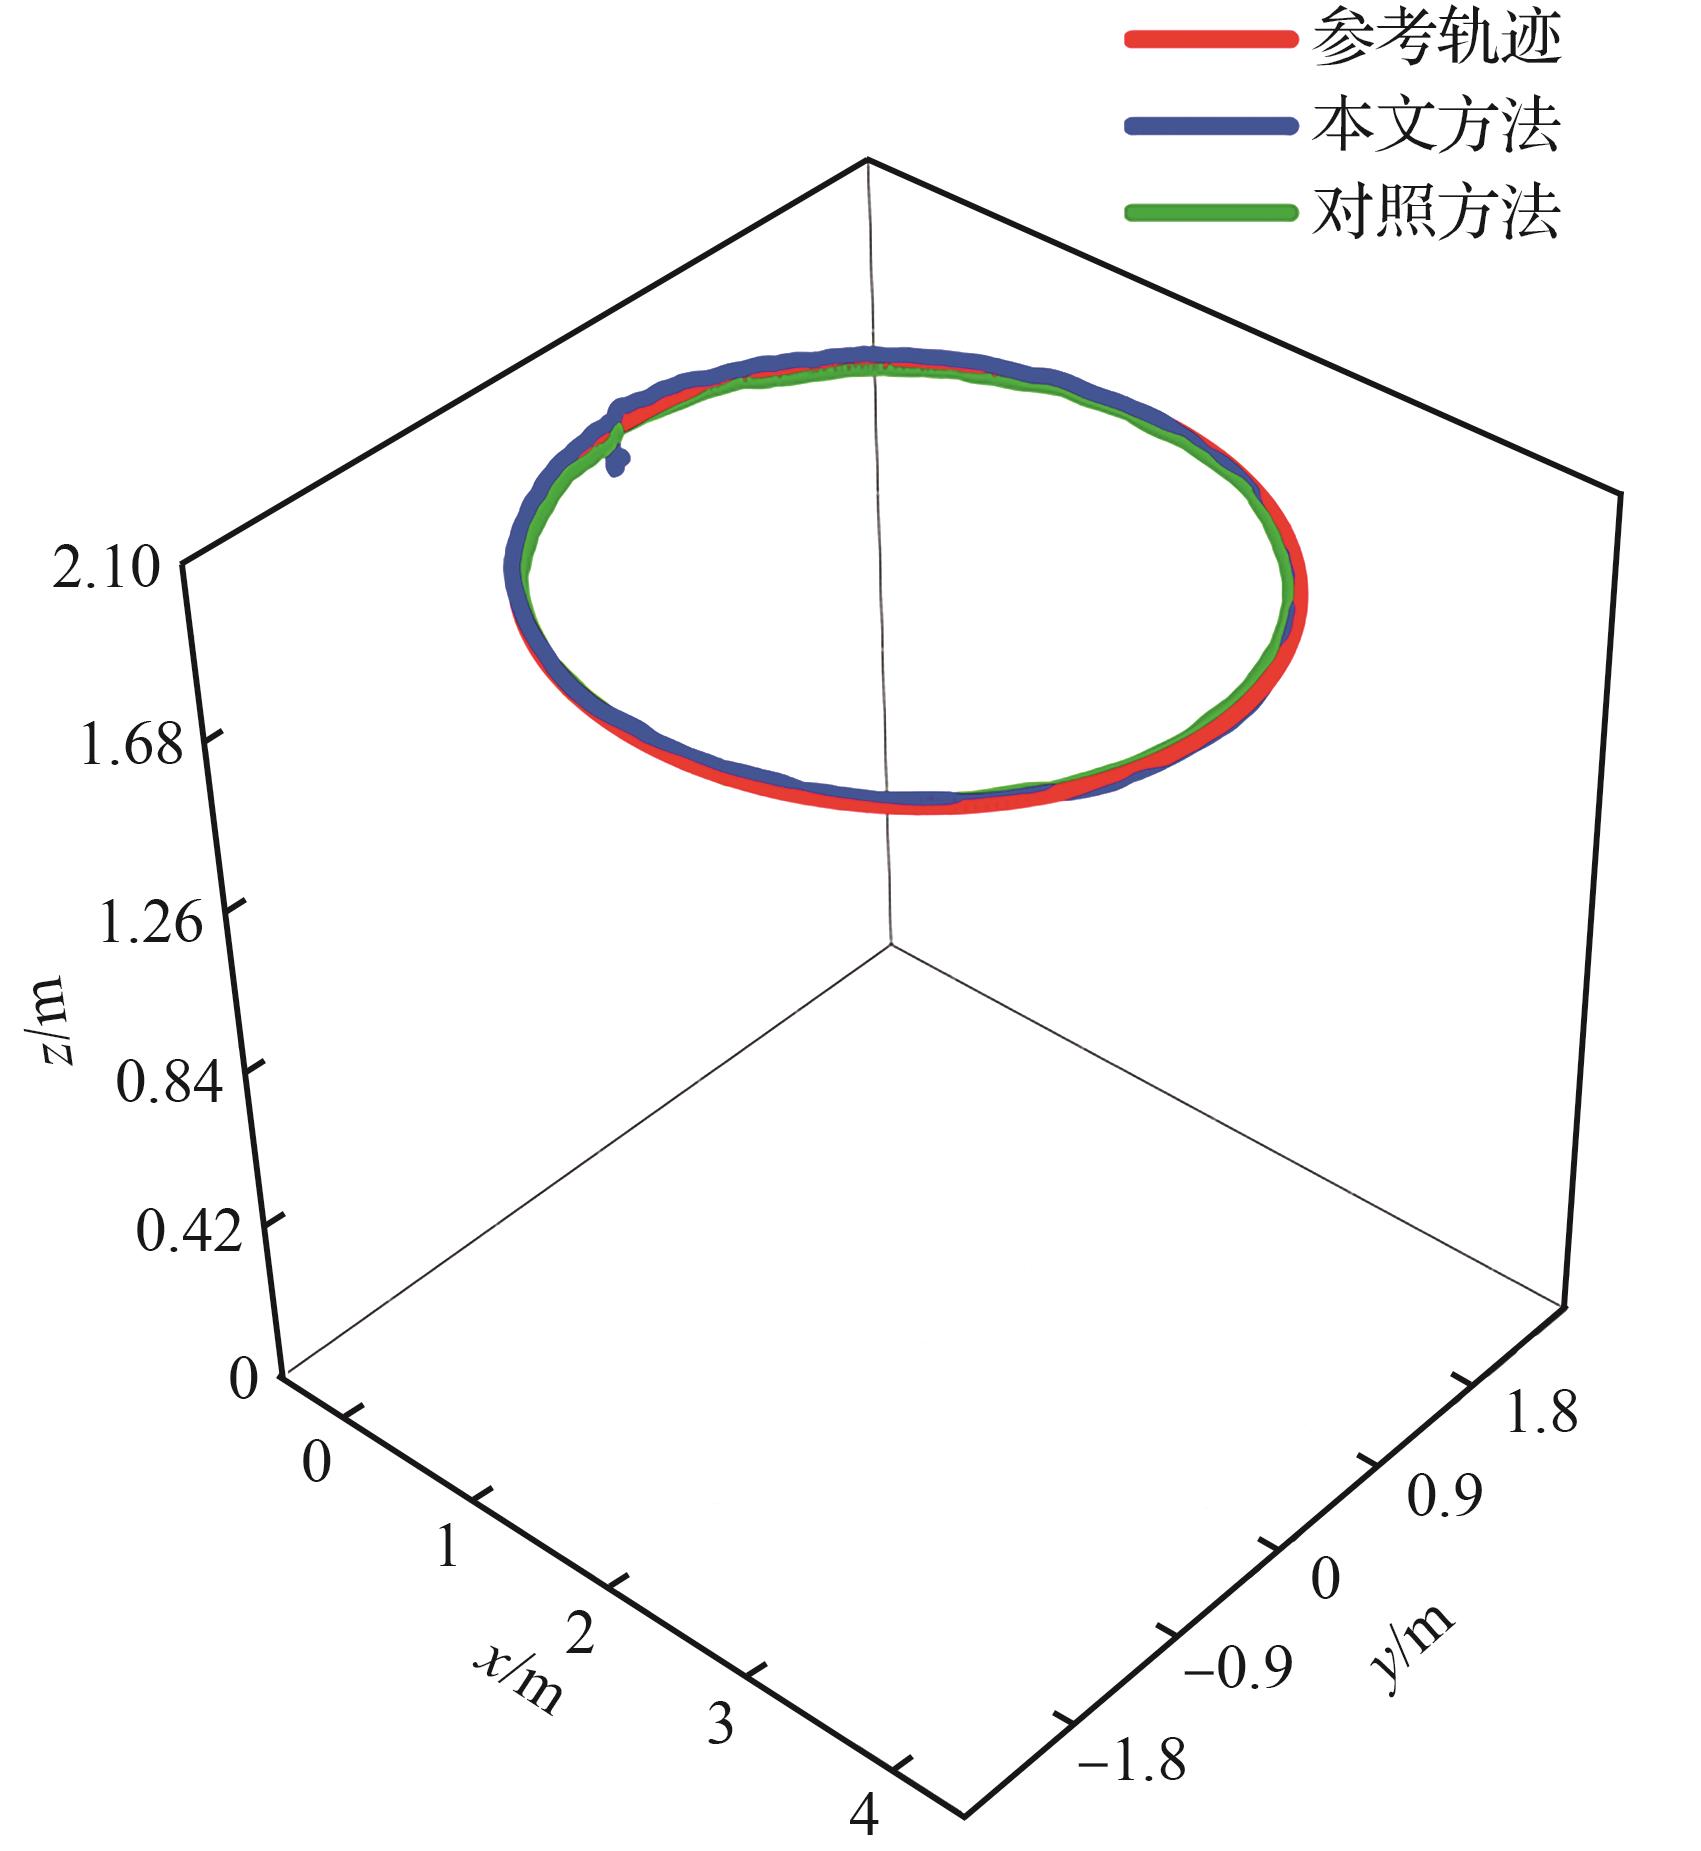
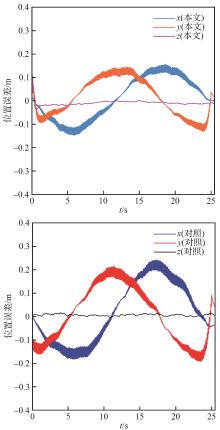
Fig.5
Trajectory tracking error in fault-free mode
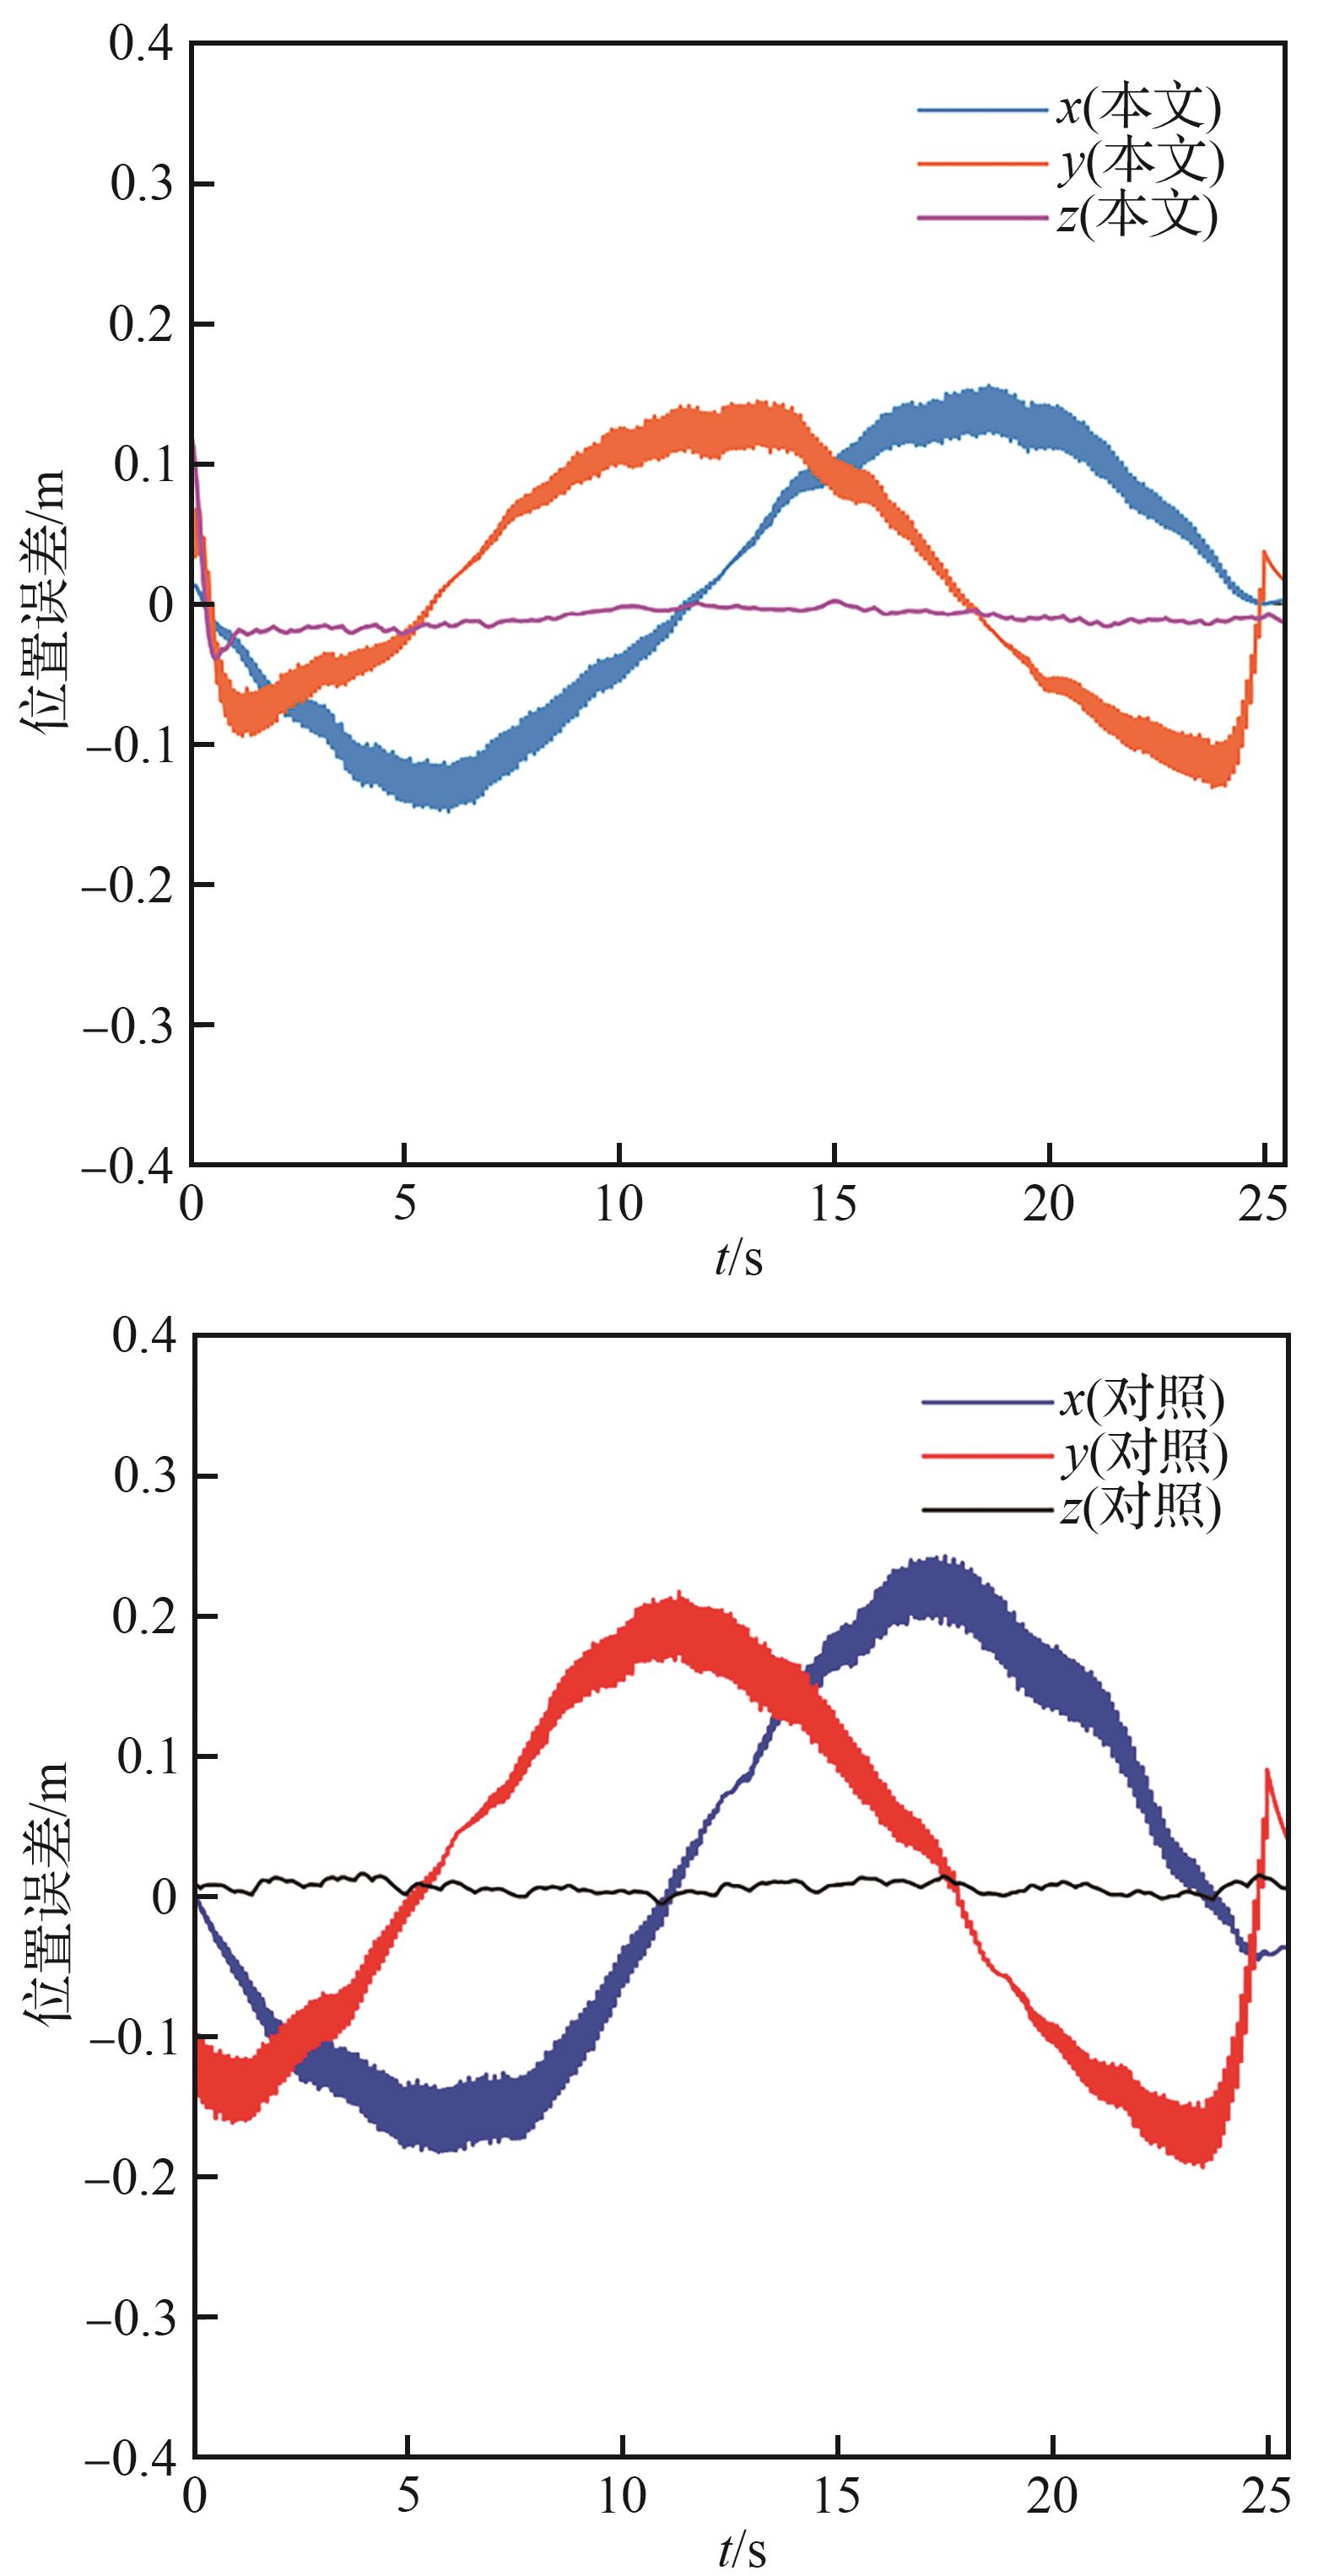
Table 3
Trajectory tracking RMSE under different failure conditions of a single rotor
| 方法 | 失效程度/% | x轴/m | y轴/m | z轴/m |
|---|---|---|---|---|
| 本文 | 0 | 0.091 1 | 0.080 1 | 0.007 8 |
| 对照 | 0 | 0.127 0 | 0.117 2 | 0.014 4 |
| 本文 | 90 | 0.108 0 | 0.101 9 | 0.022 2 |
| 对照 | 90 | 0.109 1 | 0.105 4 | 0.049 9 |
| 本文 | 100 | 0.138 7 | 0.134 6 | 0.090 8 |
| 对照 | 100 |
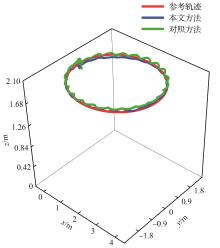
Fig.6
3D diagram of trajectory tracking in partial failure mode
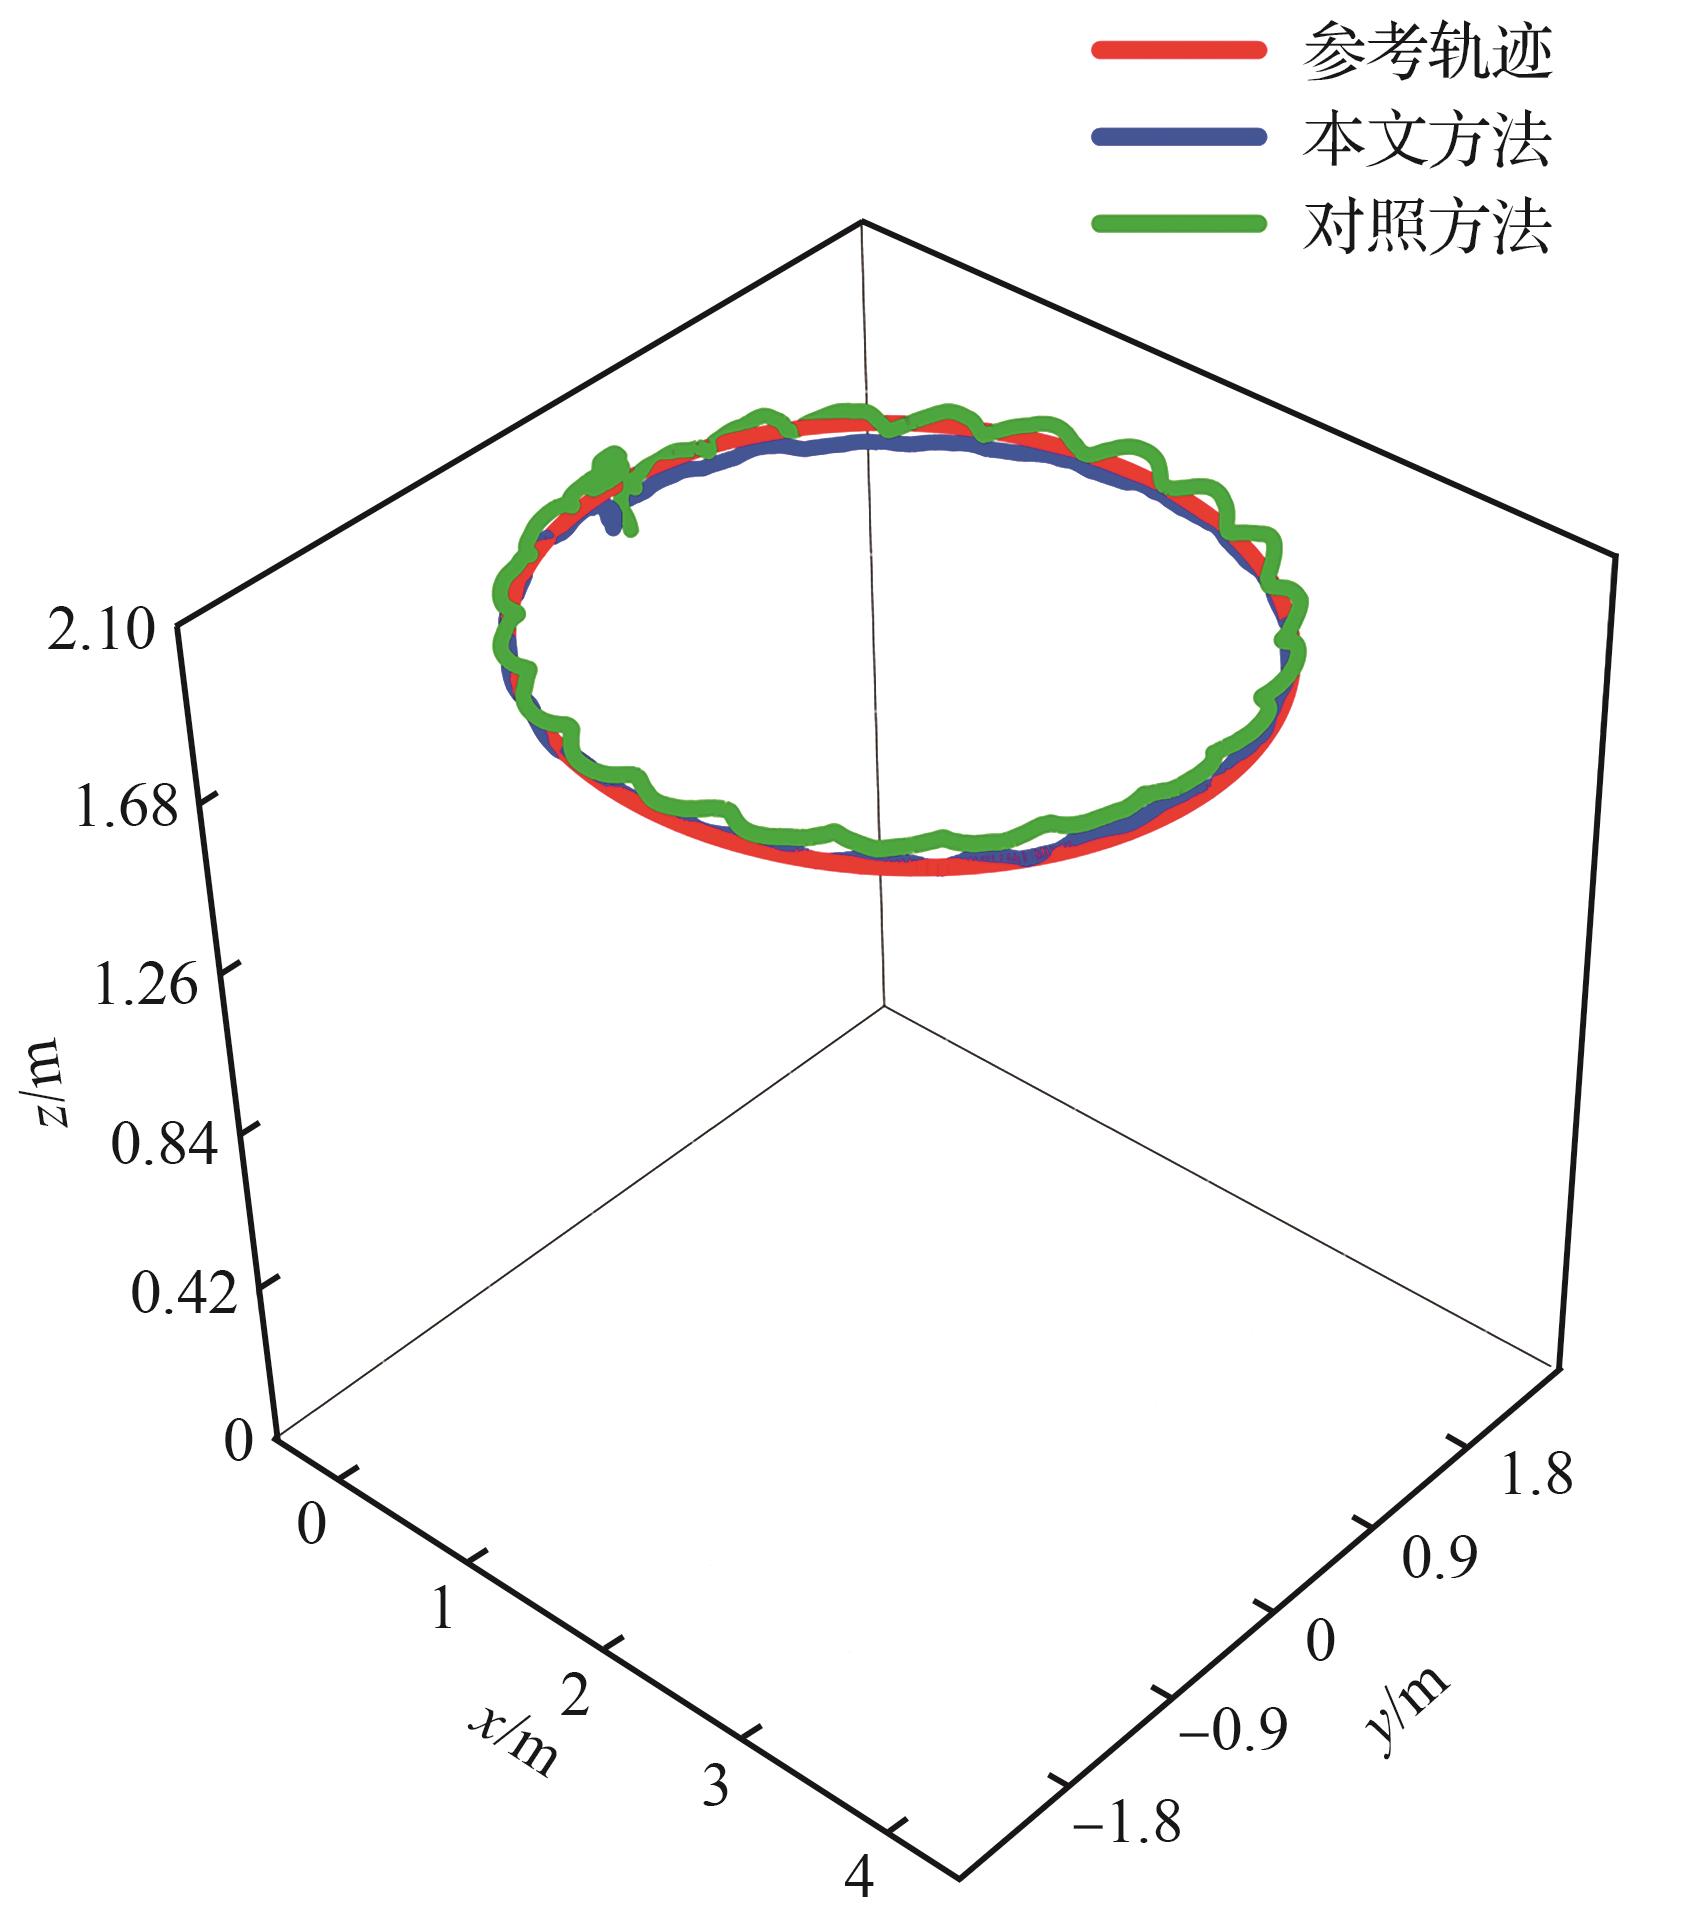
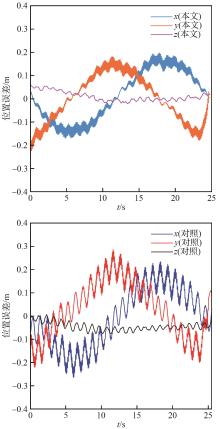
Fig.7
Trajectory tracking error in partial failure mode
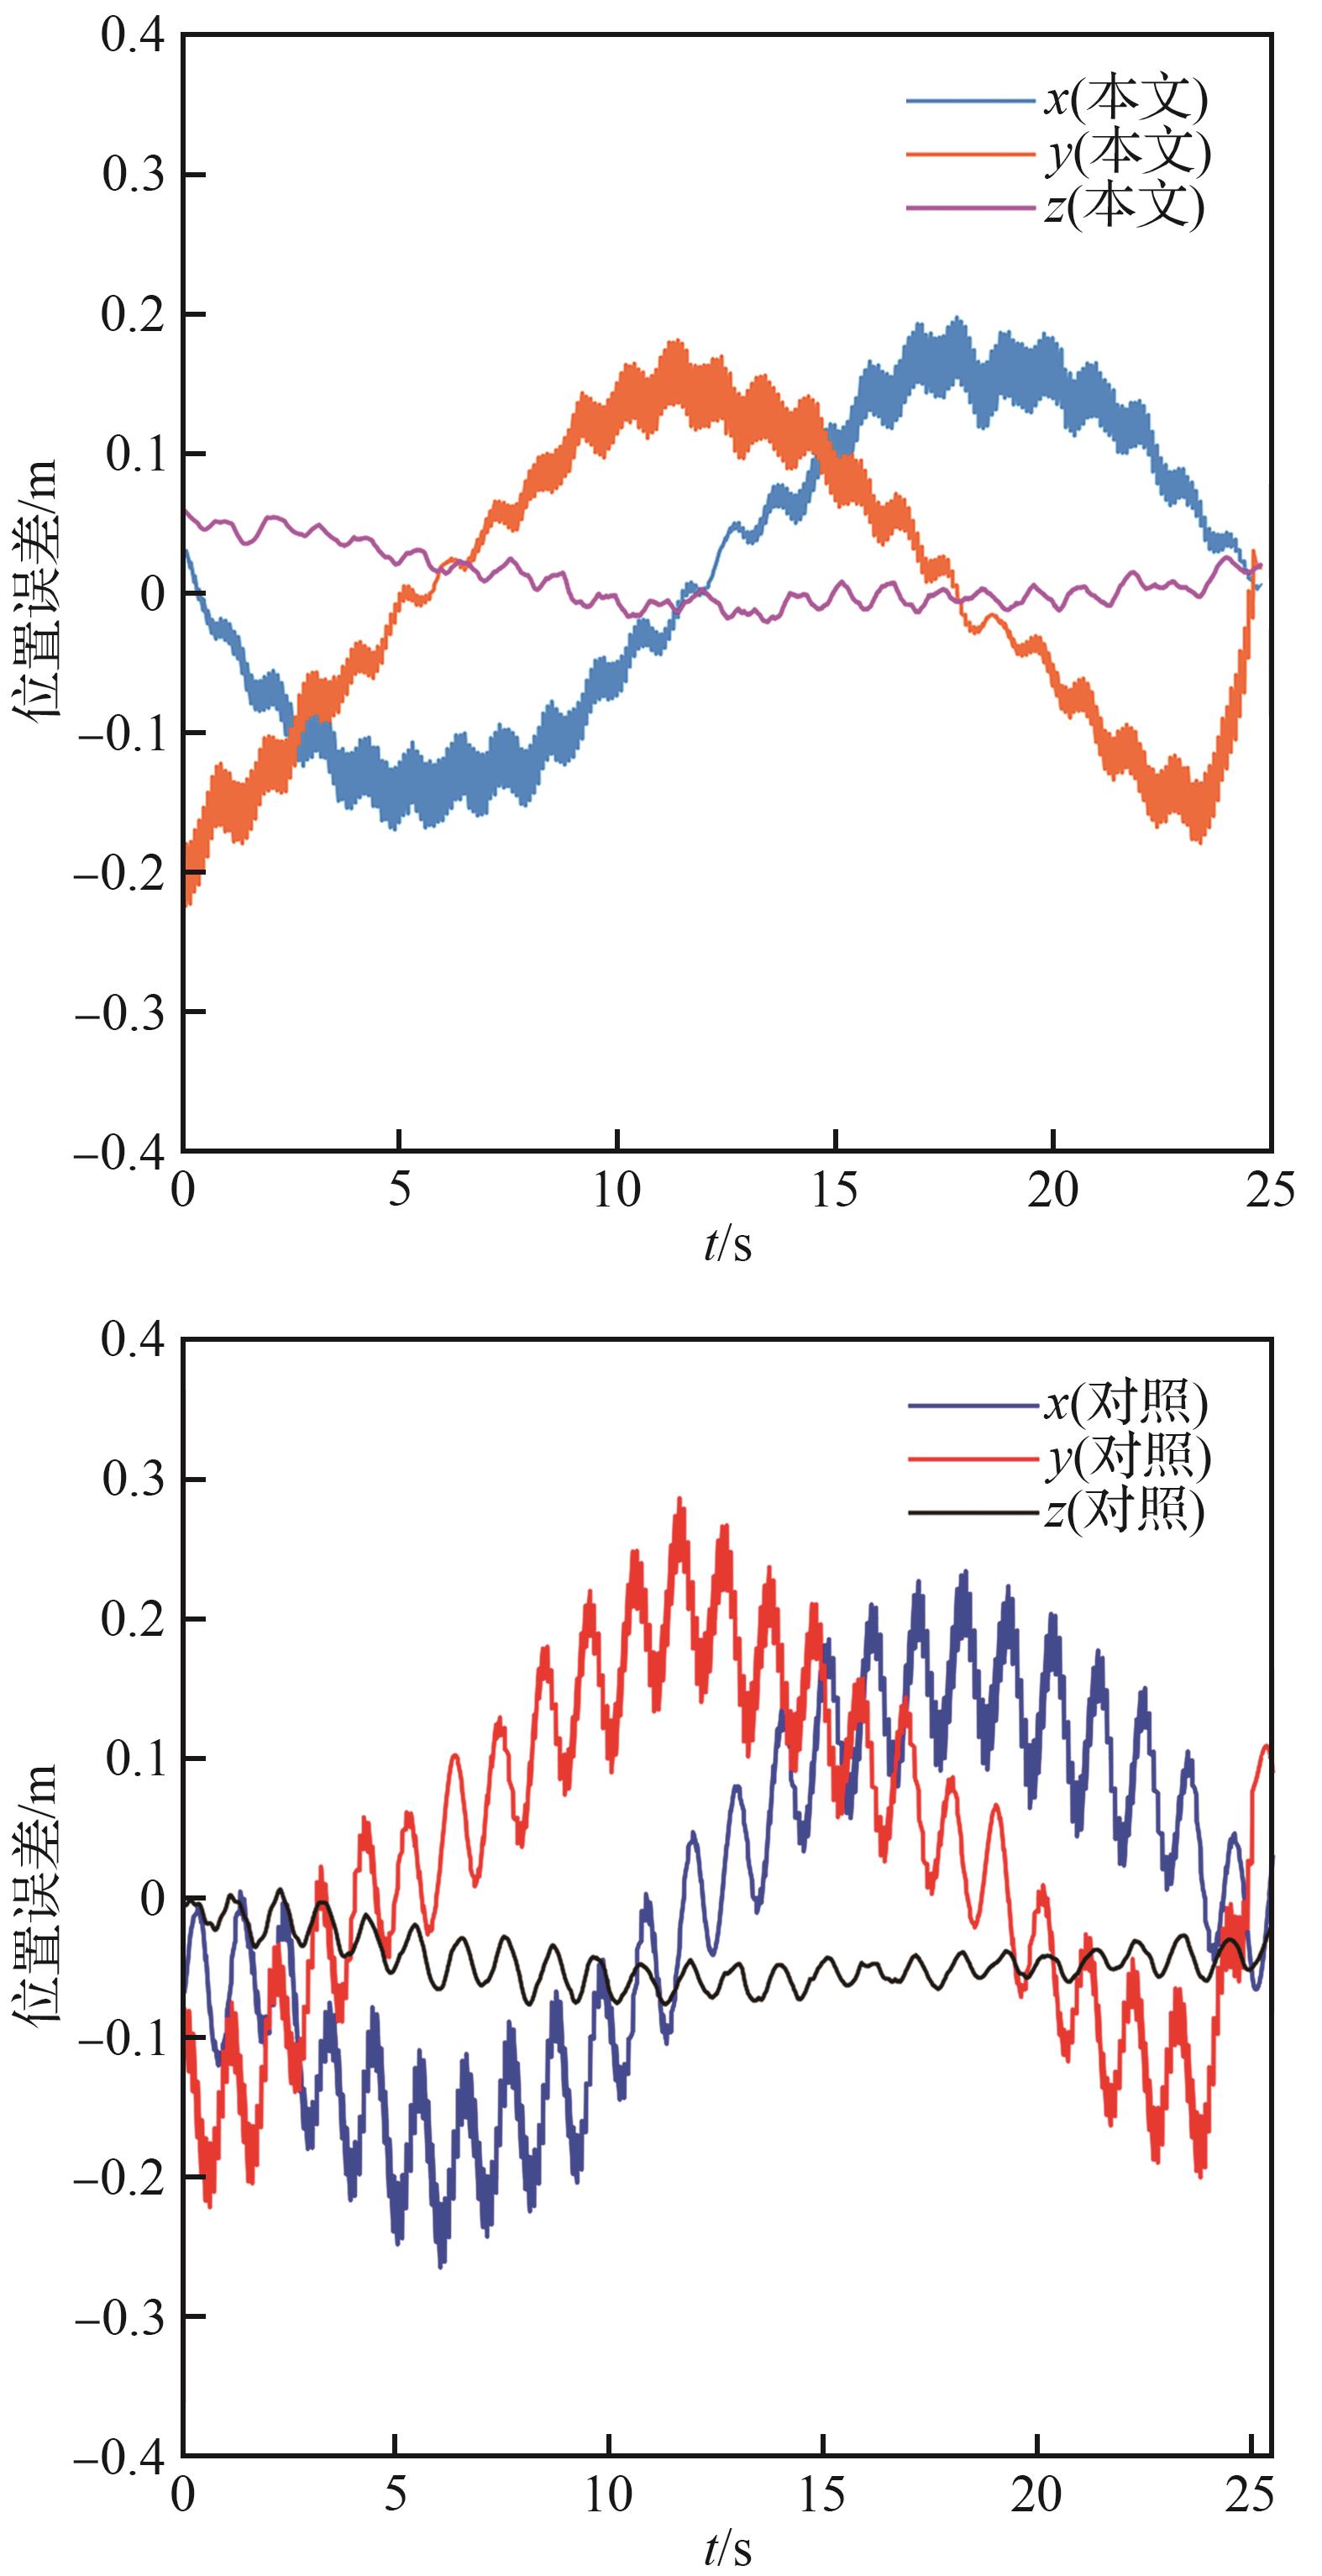
Fig.8
Angular velocity and thrust of the quadcopter UAV in partial failure mode
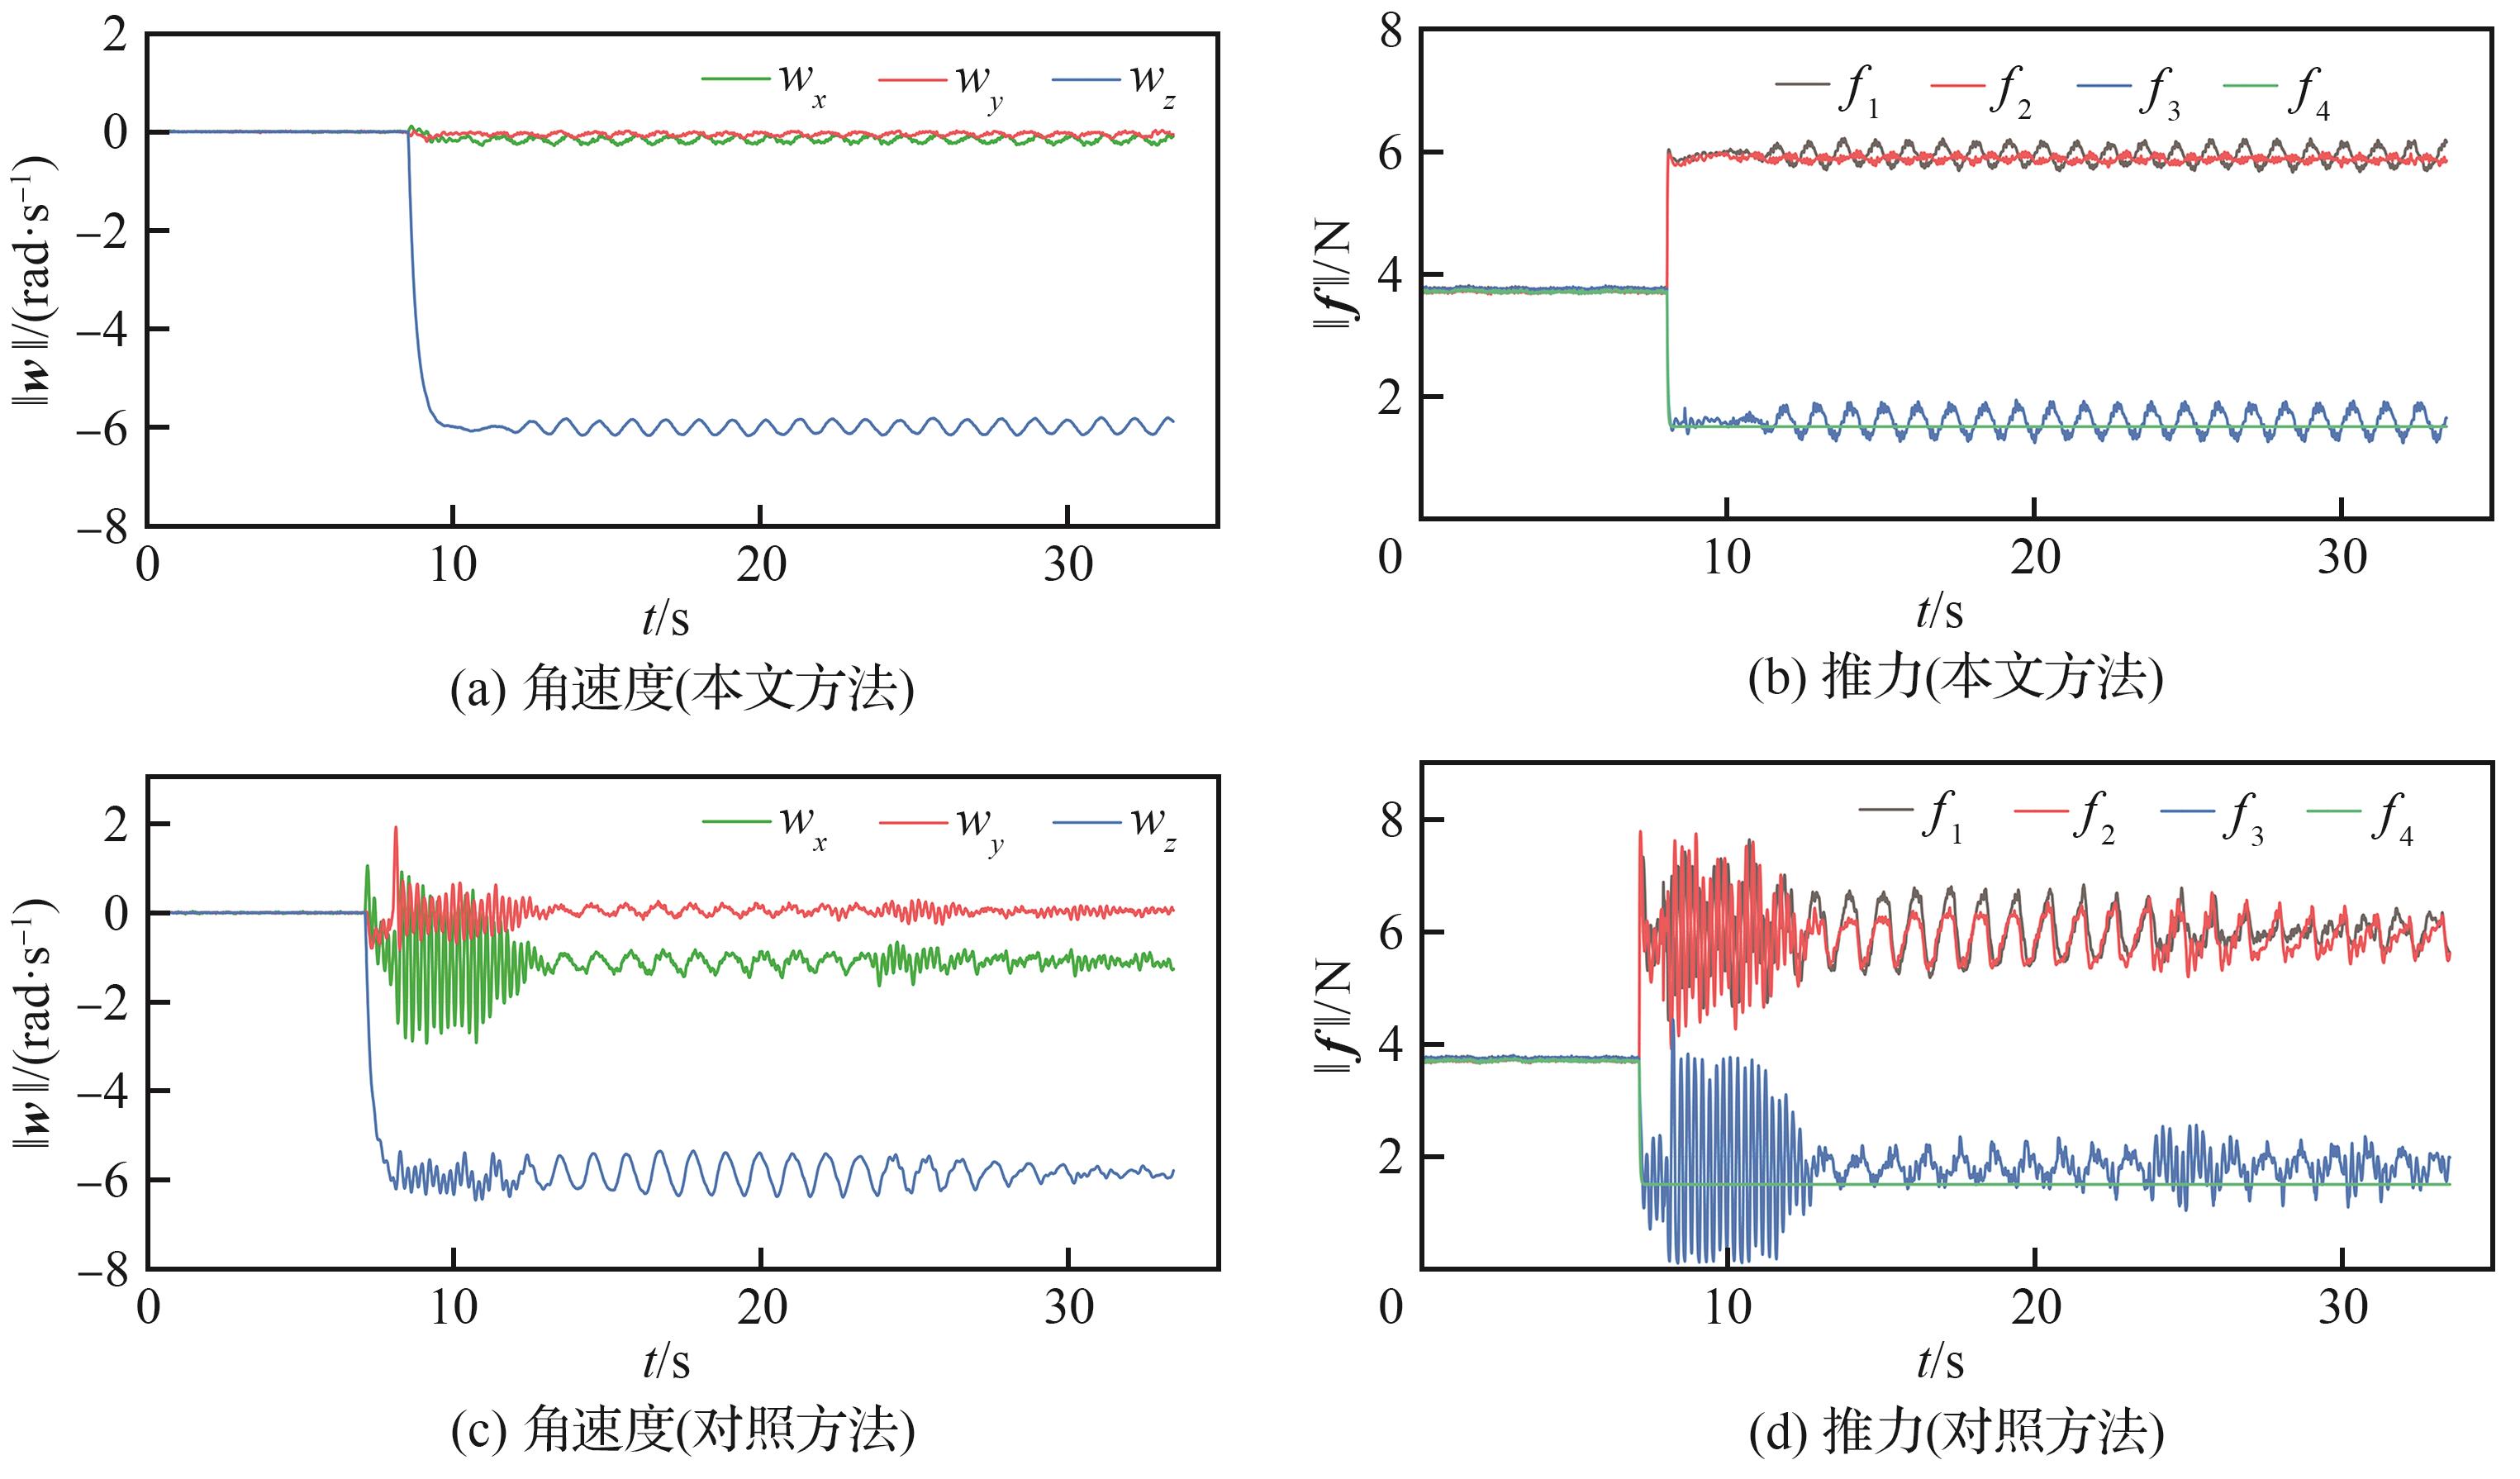
Fig.9
Angular velocity and thrust of the quadcopter UAV in complete failure mode
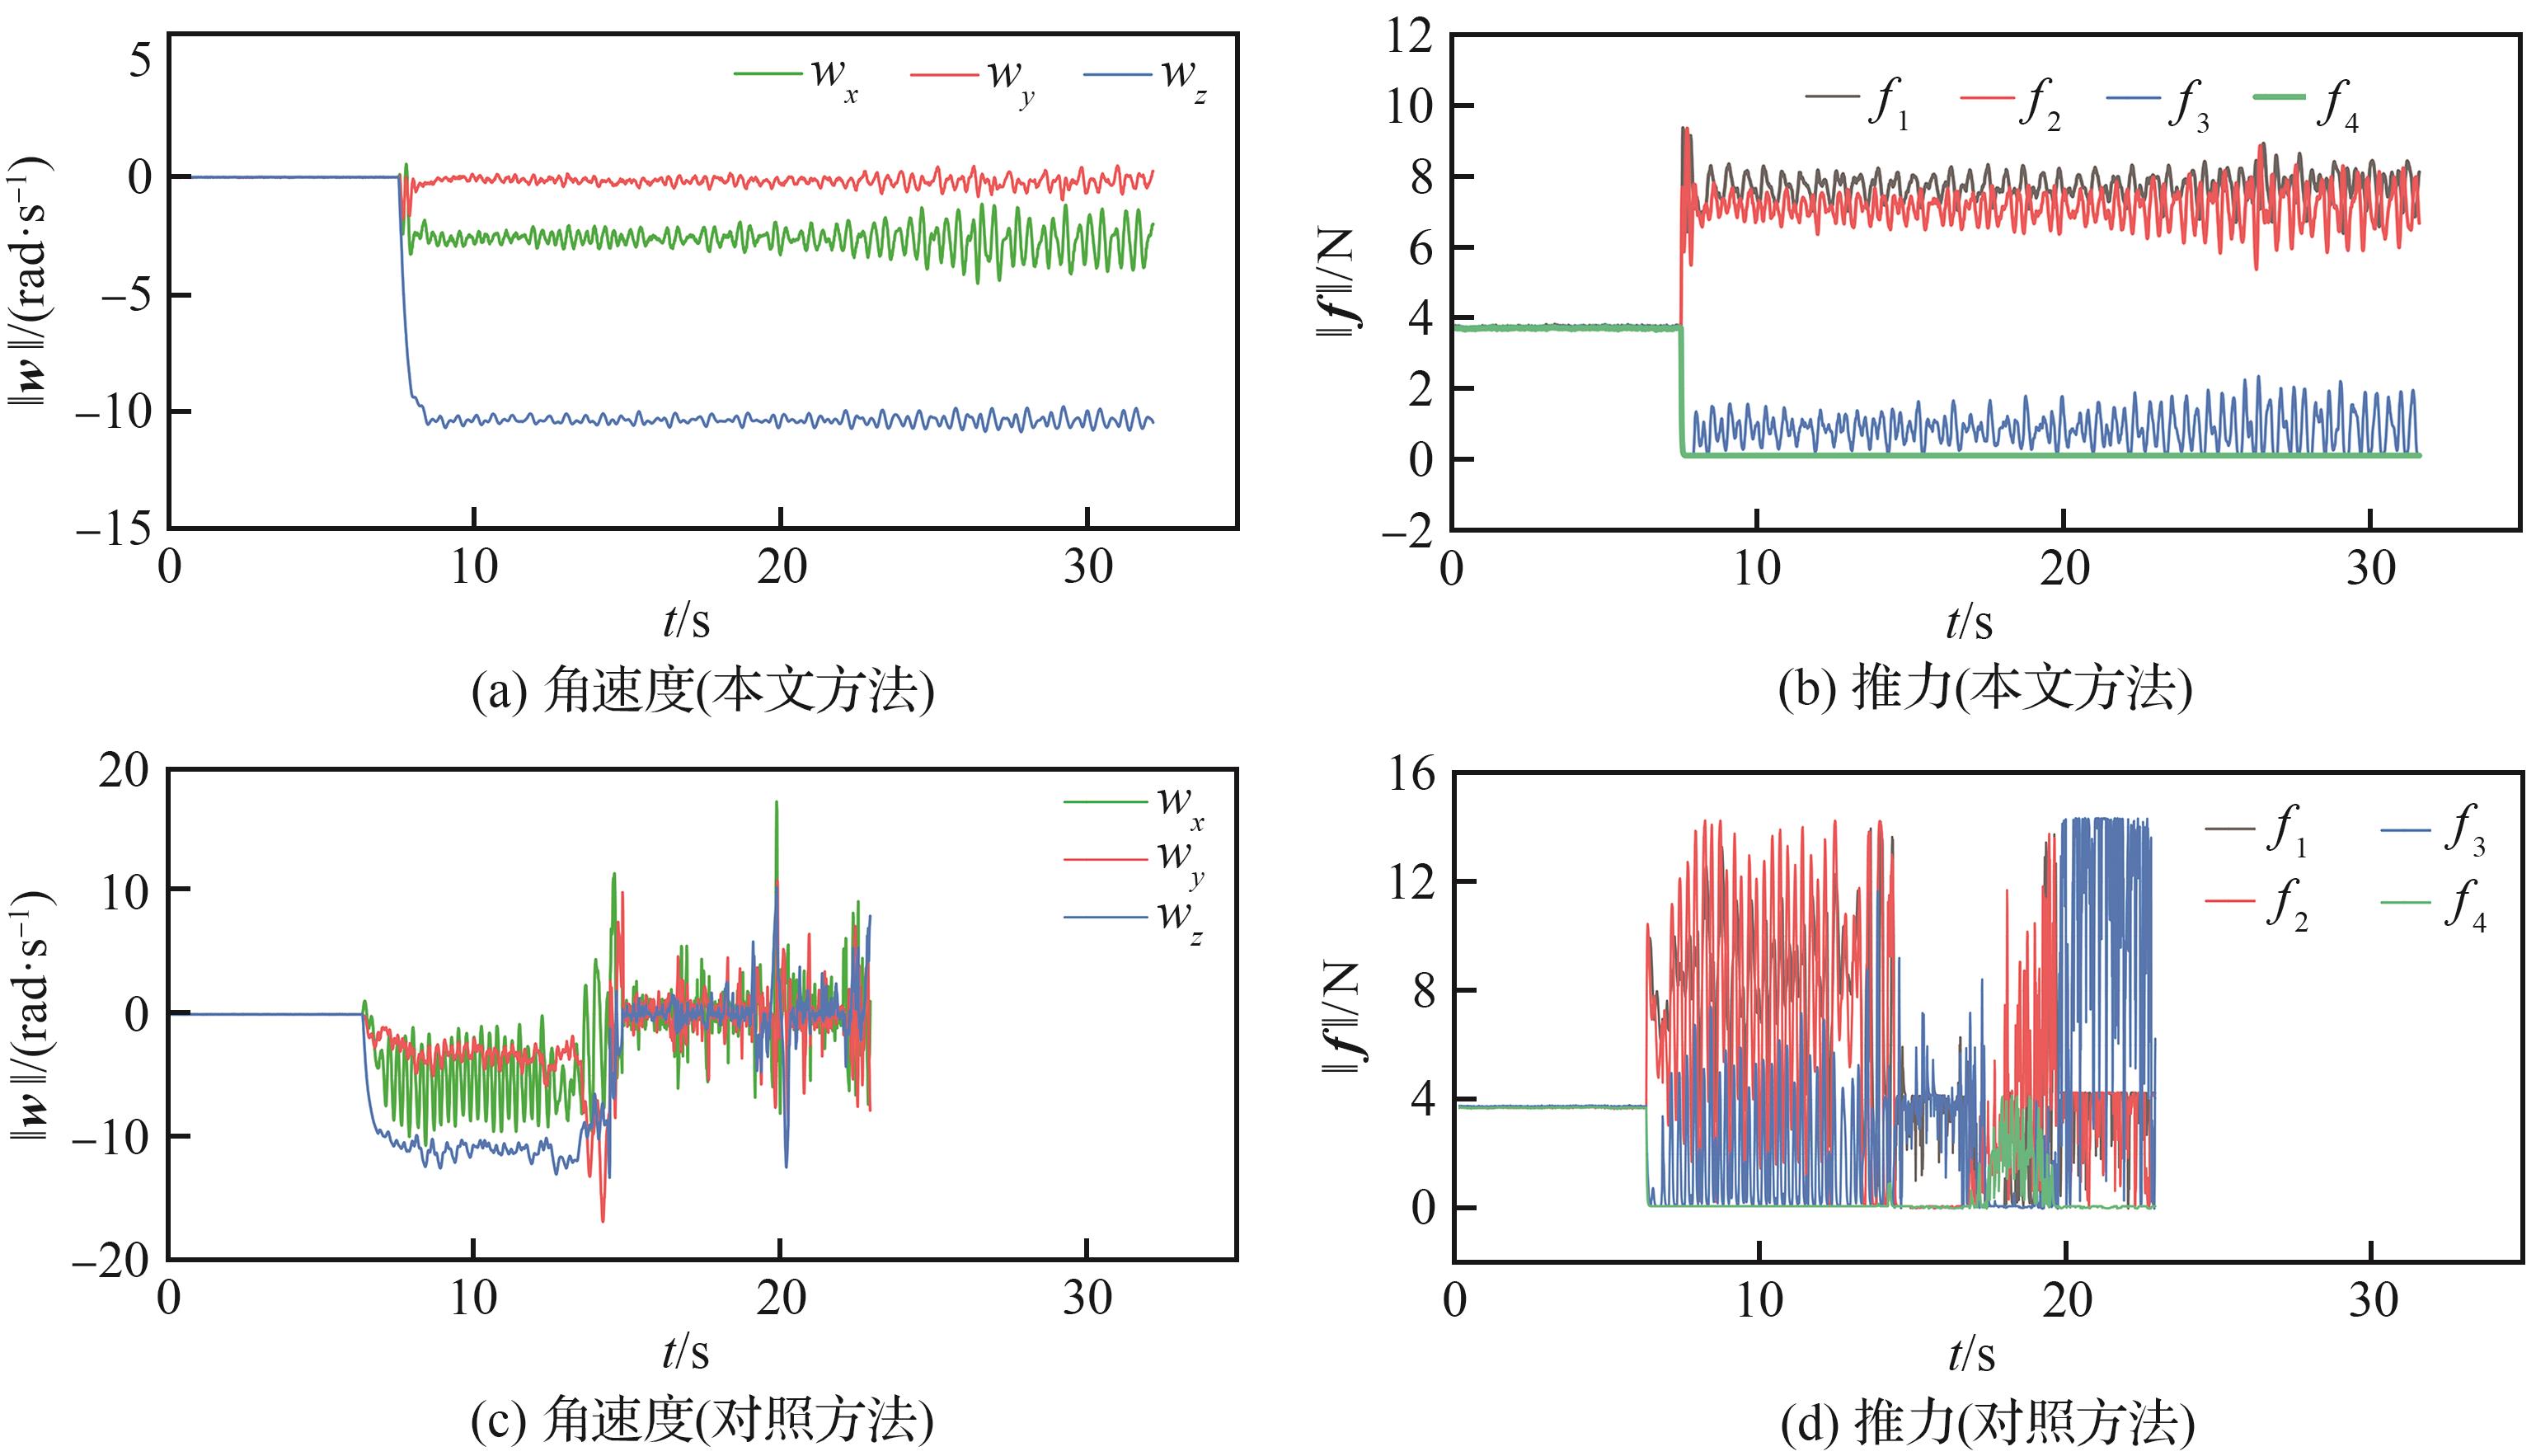
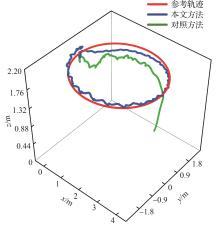
Fig.10
3D diagram of trajectory tracking in complete failure mode
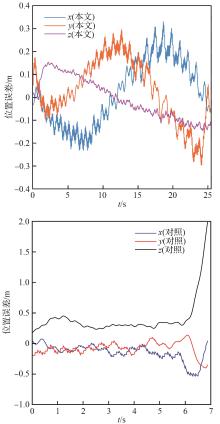
Fig.11
Trajectory tracking error in complete failure mode
Fig.12
Trajectory convergence under large initial error conditions
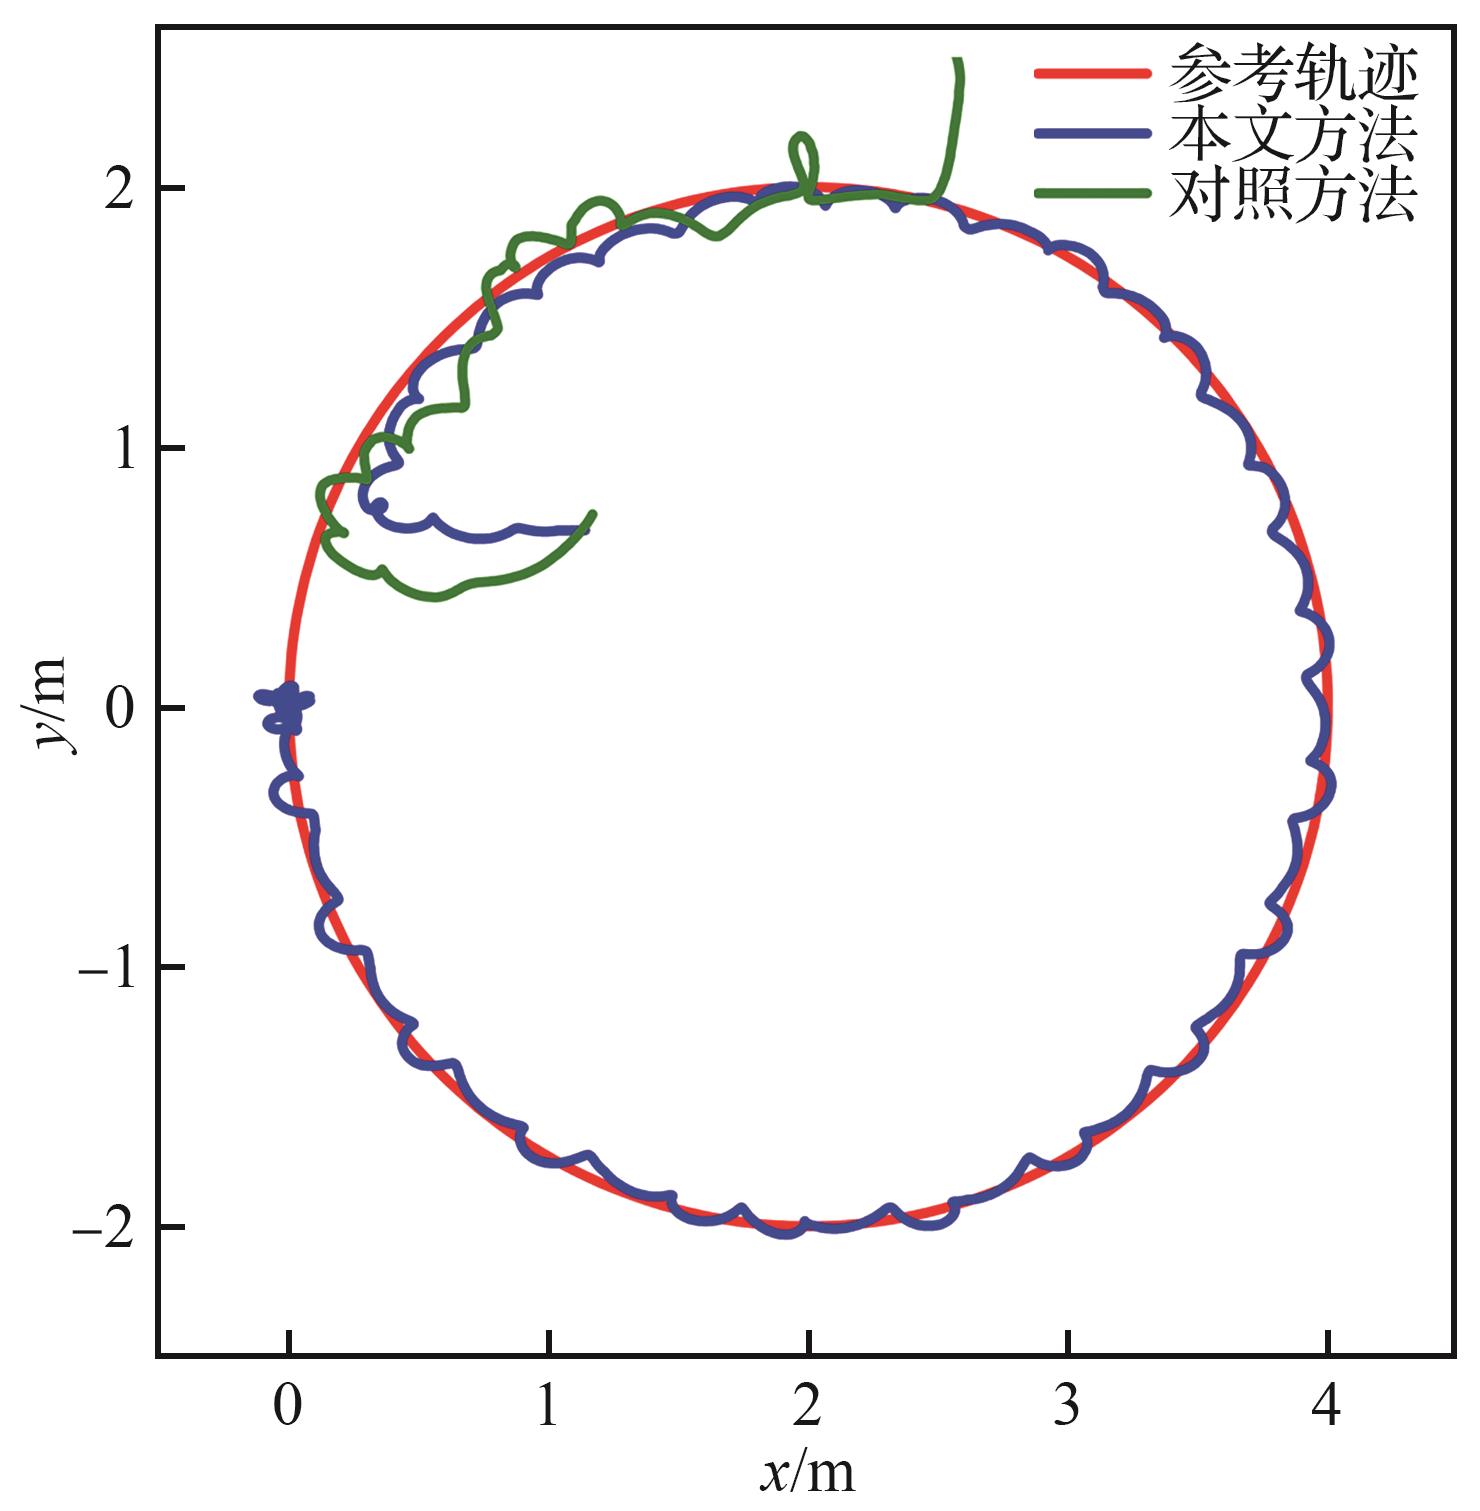
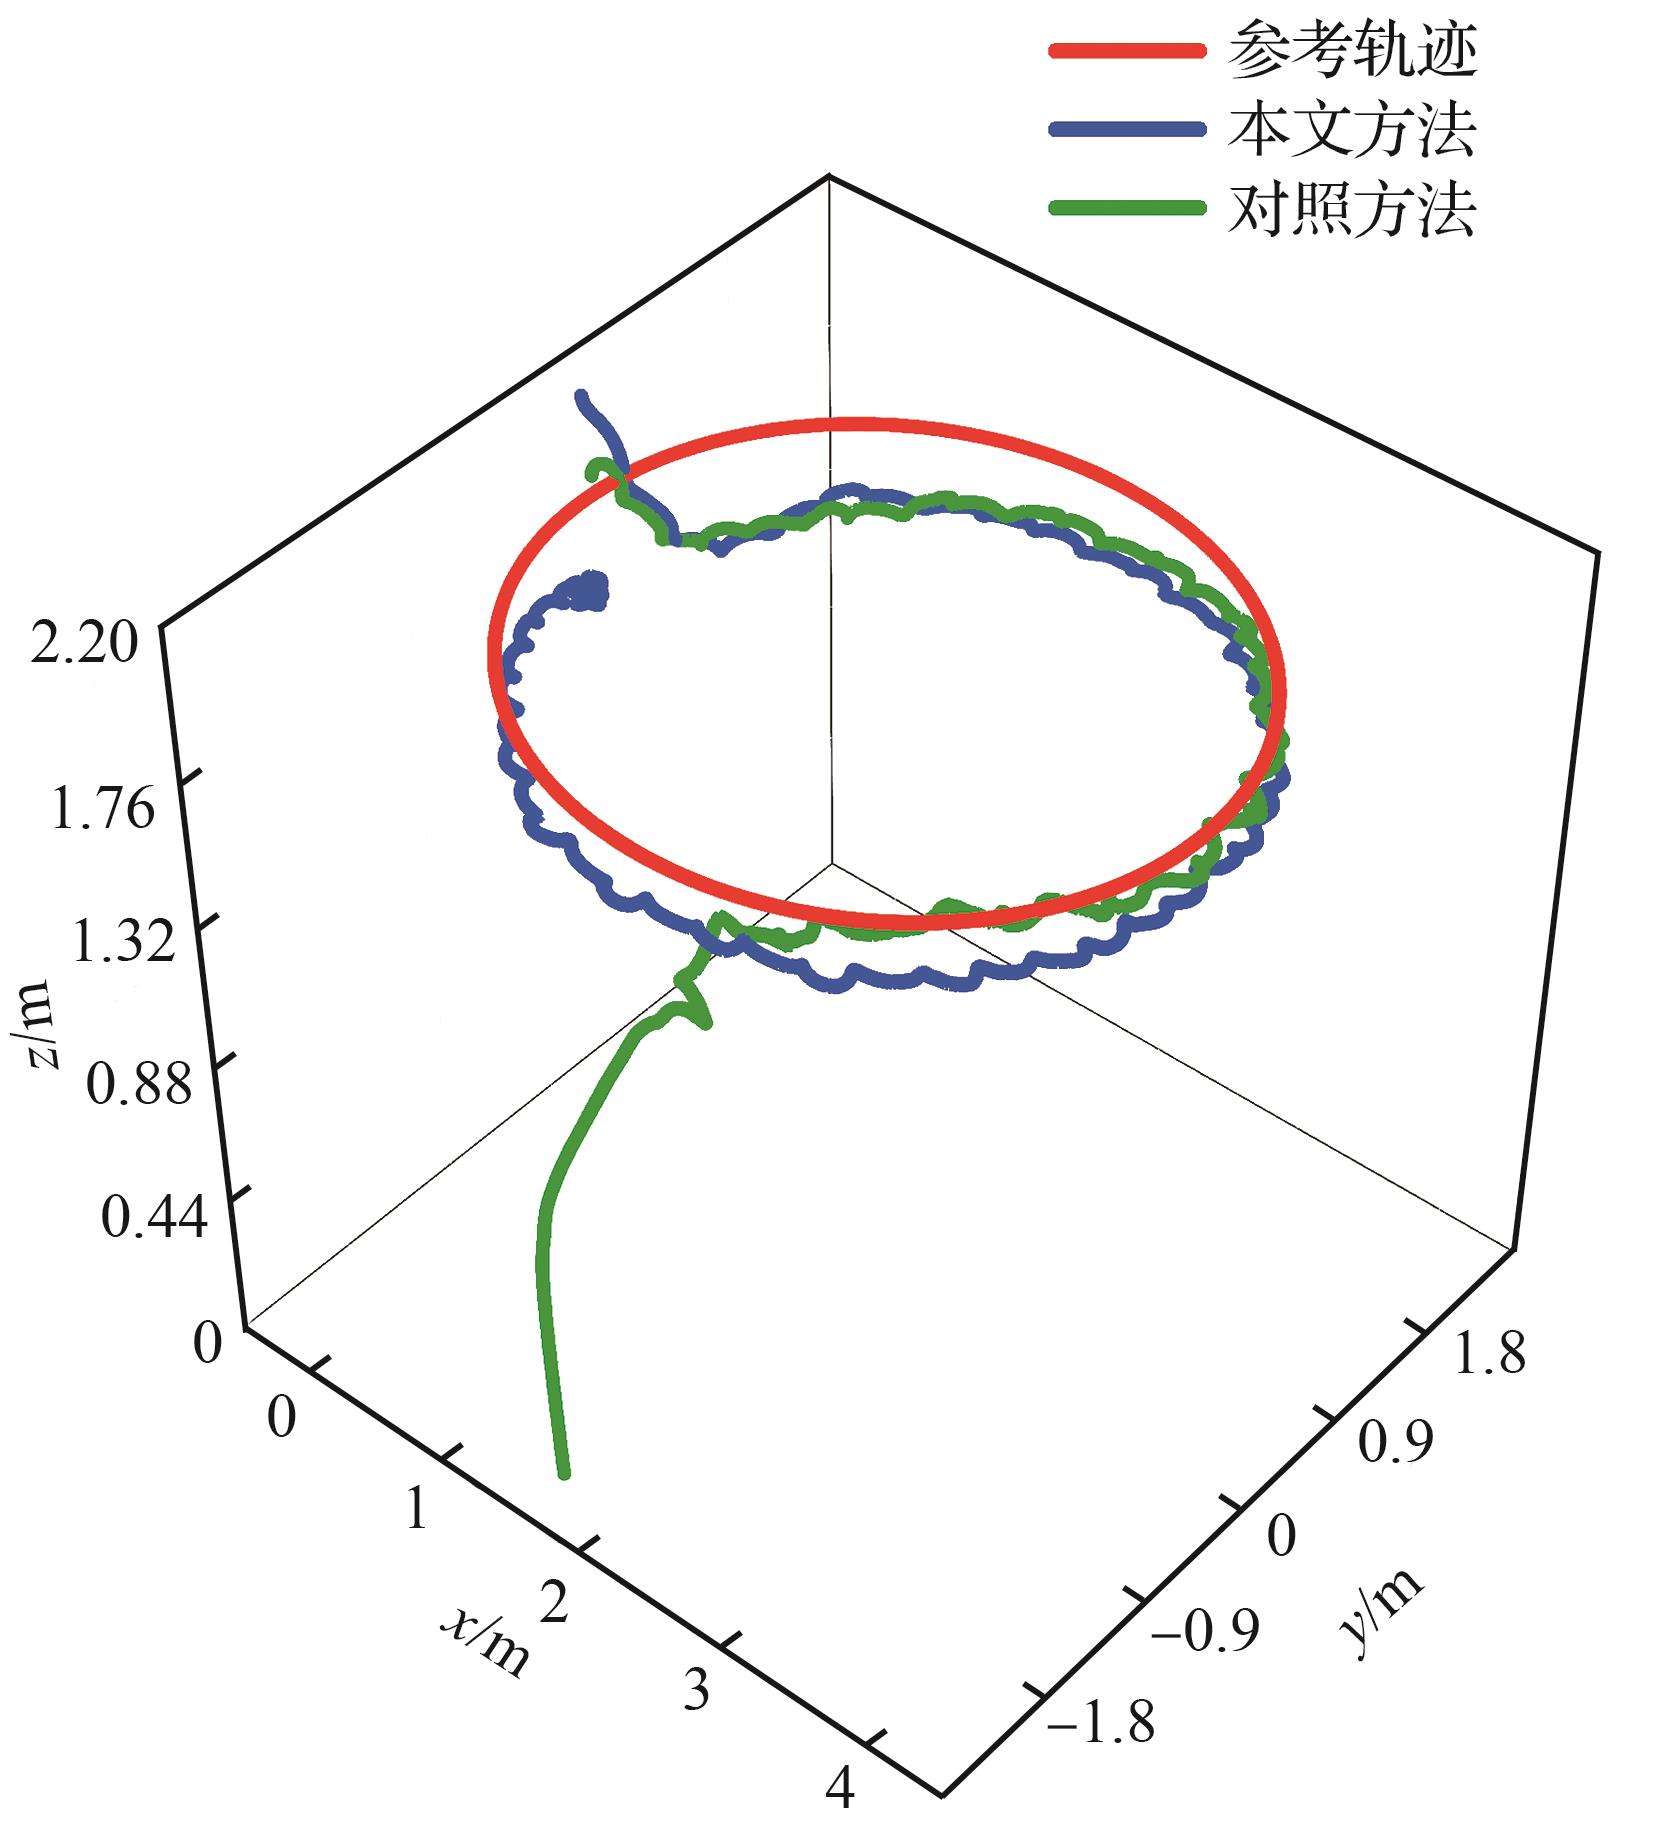
Fig.13
Comparison of RLS ablation experiments under model mismatch conditions
| [1] | LI R S, WANG X J, HE S B. Two-stage generative color calibration for drone photography with cloud-edge collaboration[J]. IEEE Internet of Things Journal, 2025, 12(5): 6054-6057. |
| [2] | ANTAL P, PÉNI T, TÓTH R. Autonomous hook-based grasping and transportation with quadcopters[J]. IEEE Transactions on Control Systems Technology, 2025, 33(3): 980-990. |
| [3] | LYNCH A, DUGUID C, BUZZATTO J, et al. A powerline inspection UAV equipped with dexterous, lockable gripping mechanisms for autonomous perching and contact rolling[C]∥ 2024 IEEE International Conference on Robotics and Automation (ICRA). Piscataway: IEEE Press, 2024: 6206-6211. |
| [4] | KARAM K, MANSOUR A, KHALDI M, et al. Quadcopters in smart agriculture: Applications and modelling[J]. Applied Sciences, 2024, 14(19): 9132. |
| [5] | ULLAH S, ALGHAMDI H, ALGETHAMI A A, et al. Robust control design of under-actuated nonlinear systems: Quadcopter unmanned aerial vehicles with integral backstepping integral terminal fractional-order sliding mode[J]. Fractal and Fractional, 2024, 8(7): 412. |
| [6] | LIPPIELLO V, RUGGIERO F, SERRA D. Emergency landing for a quadrotor in case of a propeller failure: A backstepping approach[C]∥ 2014 IEEE/RSJ International Conference on Intelligent Robots and Systems. Piscataway: IEEE Press, 2014: 4782-4788. |
| [7] | DE CROUSAZ C, FARSHIDIAN F, NEUNERT M, et al. Unified motion control for dynamic quadrotor maneuvers demonstrated on slung load and rotor failure tasks[C]∥ 2015 IEEE International Conference on Robotics and Automation (ICRA). Piscataway: IEEE Press, 2015: 2223-2229. |
| [8] | MUELLER M W, D’ANDREA R. Stability and control of a quadrocopter despite the complete loss of one, two, or three propellers[C]∥ 2014 IEEE International Conference on Robotics and Automation (ICRA). Piscataway: IEEE Press, 2014: 45-52. |
| [9] | SUN S H, CIOFFI G, DE VISSER C, et al. Autonomous quadrotor flight despite rotor failure with onboard vision sensors: Frames vs. events[J]. IEEE Robotics and Automation Letters, 2021, 6(2): 580-587. |
| [10] | HOU Z W, LU P, TU Z J. Nonsingular terminal sliding mode control for a quadrotor UAV with a total rotor failure[J]. Aerospace Science and Technology, 2020, 98: 105716. |
| [11] | YU D X, MA S Z, LIU Y J, et al. Finite-time adaptive fuzzy backstepping control for quadrotor UAV with stochastic disturbance[J]. IEEE Transactions on Automation Science and Engineering, 2024, 21(2): 1335-1345. |
| [12] | WANG J H, ALATTAS K A, BOUTERAA Y, et al. Adaptive finite-time backstepping control tracker for quadrotor UAV with model uncertainty and external disturbance[J]. Aerospace Science and Technology, 2023, 133: 108088. |
| [13] | WANG H, SHAN J J. Distributed adaptive dynamic event-triggered control for multiple quadrotors[J]. ASME Transactions on Mechatronics, 2023, 28(4): 1900-1910. |
| [14] | KHADHRAOUI A, ZOUAOUI A, SAAD M. Barrier Lyapunov function and adaptive backstepping-based control of a quadrotor UAV[J]. Robotica, 2023, 41(10): 2941-2963. |
| [15] | MAARUF M, ABUBAKAR A N, GULZAR M M. Adaptive backstepping and sliding mode control of a quadrotor[J]. Journal of the Brazilian Society of Mechanical Sciences and Engineering, 2024, 46(11): 630. |
| [16] | FATEMI M M, AKBARIMAJD A. Adaptive sliding mode control for quadrotor UAVs under disturbances using multi-layer perceptron[J]. IEEE Access, 2025, 13: 45518-45526. |
| [17] | LIU W Q, CHENG X H, ZHANG J J. Command filter-based adaptive fuzzy integral backstepping control for quadrotor UAV with input saturation[J]. Journal of the Franklin Institute, 2023, 360(1): 484-507. |
| [18] | FOEHN P, ROMERO A, SCARAMUZZA D. Time-optimal planning for quadrotor waypoint flight[J]. Science Robotics, 2021, 6(56): eabh1221. |
| [19] | BANGURA M, MAHONY R. Real-time model predictive control for quadrotors[J]. IFAC Proceedings Volumes, 2014, 47(3): 11773-11780. |
| [20] | KAMEL M, ALEXIS K, ACHTELIK M, et al. Fast nonlinear model predictive control for multicopter attitude tracking on SO(3)[C]∥ 2015 IEEE Conference on Control Applications (CCA). Piscataway: IEEE Press, 2015:1160-1166. |
| [21] | SUN S H, WANG X R, CHU Q P, et al. Incremental nonlinear fault-tolerant control of a quadrotor with complete loss of two opposing rotors[J]. IEEE Transactions on Robotics, 2021, 37(1): 116-130. |
| [22] | HUANG R, SHENG H L, CHEN Q, et al. Adaptive configuration control of combined UAVs based on leader-wingman mode[J]. Chinese Journal of Aeronautics, 2024, 37(12): 416-433. |
| [23] | SUN Z W, ZHANG F B, LANG S P. Fault-tolerant model predictive control of a quadrotor with an unknown complete rotor failure[C]∥ 2022 41st Chinese Control Conference (CCC). Piscataway: IEEE Press, 2022: 4087-4093. |
| [24] | SMEUR E J J, CHU Q P, DE CROON G C H E. Adaptive incremental nonlinear dynamic inversion for attitude control of micro air vehicles[J]. Journal of Guidance, Control, and Dynamics, 2016, 39(3): 450-461. |
| [25] | HAFNER S, HOSSEINI B, HOLZAPFEL F. Least squares based adaptive control allocation[C]∥ 2023 IEEE Conference on Control Technology and Applications (CCTA). Piscataway: IEEE Press, 2023: 651-656. |
| [26] | BLAHA T M, SMEUR E J J, REMES B D W, et al. Flying a quadrotor with unknown actuators and sensor configuration [DB/OL]. arXiv preprint: 2409.01080, 2024. |
| [27] | DHAYBI M, DAHER N. Real-time estimation of the inertia tensor elements of a quadcopter hover platform[C]∥2019 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM). Piscataway: IEEE Press, 2019: 1347-1352. |
| [28] | CAO S, SHEN L C, ZHANG R S, et al. Adaptive incremental nonlinear dynamic inversion control based on neural network for UAV maneuver[C]∥ 2019 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM). Piscataway: IEEE Press, 2019: 642-647. |
| [29] | HACHEM M, ROOS C, MIQUEL T, et al. Improving incremental nonlinear dynamic inversion robustness using robust control in aerial robotics[J]. Journal of Guidance, Control, and Dynamics, 2026, 49(1): 280-291. |
| [30] | 陈涛, 陈建. 基于学习观测器的无人机故障弹性容错控制[J]. 航空学报, 2025, 46(11): 531346. |
| CHEN T, CHEN J. Learning-observer-based resilient fault-tolerant control for quadrotor unmanned aerial vehicles[J]. Acta Aeronautica et Astronautica Sinica,2025, 46 (11): 531346 (in Chinese). | |
| [31] | LUO Z R, XIAO E D, LU P. FT-Net: Learning failure recovery and fault-tolerant locomotion for quadruped robots[J]. IEEE Robotics and Automation Letters, 2023, 8(12): 8414-8421. |
| [32] | REN Y, SUN Y. Inverse compensation mechanism-based adaptive fuzzy-neural fault-tolerant control for an uncertain quadrotor UAV[J]. Aerospace Science and Technology. 2024, 153: 109426. |
| [33] | LIU X, YUAN Z, GAO Z, et al. Reinforcement learning-based fault-tolerant control for quadrotor UAVs under actuator fault[J]. IEEE Transactions on Industrial Informatics. 2024, 20(12): 13926-13935. |
| [34] | MERHEB A R, NOURA H, BATEMAN F. Design of passive fault-tolerant controllers of a quadrotor based on sliding mode theory[J]. International Journal of Applied Mathematics and Computer Science. 2015, 25(3): 561-576. |
| [35] | BARGHANDAN S, BADAMCHIZADEH M ALI, JAHED-MOTLAGH M R. Improved adaptive fuzzy sliding mode controller for robust fault tolerant of a quadrotor[J]. International Journal of Control, Automation and Systems, 2017, 15(1): 427-441. |
| [36] | MAO J, YEOM J, NAIR S, et al. From propeller damage estimation and adaptation to fault tolerant control: Enhancing quadrotor resilience[J]. IEEE Robotics and Automation Letters, 2024, 9(5): 4297-4304. |
| [37] | KE C X, CAI K Y, QUAN Q. Uniform passive fault-tolerant control of a quadcopter with one, two, or three rotor failure[J]. IEEE Transactions on Robotics, 2023, 39(6): 4297-4311. |
| [38] | CHEN X Q, WANG S, ZHAO H X, et al. Fault-tolerant control of lifting-wing multicopter based on nonlinear MPC[J]. IEEE Robotics and Automation Letters, 2025, 10(6): 6135-6142. |
| [39] | BEYER Y, STEEN M, HECKER P. Incremental passive fault-tolerant control for quadrotors subjected to complete rotor failures[J]. Journal of Guidance, Control, and Dynamics, 2023, 46(10): 2033-2042. |
| [40] | SUN S H, SIJBERS L, WANG X R, et al. High-speed flight of quadrotor despite loss of single rotor[J]. IEEE Robotics and Automation Letters, 2018, 3(4): 3201-3207. |
| [41] | NAN F, SUN S H, FOEHN P, et al. Nonlinear MPC for quadrotor fault-tolerant control[J]. IEEE Robotics and Automation Letters, 2022, 7(2): 5047-5054. |
| [42] | FREDDI A, LANZON A, LONGHI S. A feedback linearization approach to fault tolerance in quadrotor vehicles[J]. IFAC Proceedings Volumes, 2011, 44(1): 5413-5418. |
| [43] | TAL E, KARAMAN S. Accurate tracking of aggressive quadrotor trajectories using incremental nonlinear dynamic inversion and differential flatness[J]. IEEE Transactions on Control Systems Technology, 2021, 29(3): 1203-1218. |
| [44] | LI F Y, LUO S H, YANG G C, et al. Dynamical analysis and accelerated adaptive backstepping funnel control for dual-mass MEMS gyroscope under event trigger[J]. Chaos, Solitons & Fractals, 2023, 168: 113116. |
| [45] | NGUYEN N P, HONG S K. Sliding mode thau observer for actuator fault diagnosis of quadcopter UAVs[J]. Applied Sciences, 2018, 8(10): 1893. |
| [46] | DEBELE Y, SHI H Y, WONDOSEN A, et al. Deep learning-based robust actuator fault detection and isolation scheme for highly redundant multirotor UAVs[J]. Drones, 2023, 7(7): 437. |
| [1] | Qi CHEN, Chang ZHANG, Hongjin ZHANG, Jiyu HU, Like ZHAO. Trajectory tracking control of multiple parafoil formation based on fuzzy PID [J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(S1): 732897-732897. |
| [2] | Yu LI, Jiaxin CHEN, Kecheng LI, Chi-Yung WEN, Ni LI, Xiaoxiong LIU. Characteristic analysis of aircraft with asymmetric wing damage and incremental fault-tolerant control [J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(9): 532501-532501. |
| [3] | Qie LIU, Junying LU, Fei XIE, Wenbo LI. Adaptive hybrid dynamic programming for fault-tolerant attitude control of underactuated spacecraft [J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(9): 532531-532531. |
| [4] | Xiaojuan WANG, Guangtai TIAN, Bin LI, Zhenqing HE. Fully actuated anti-disturbance control for quadrotor UAVs based on dynamic compensator [J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(9): 123-135. |
| [5] | Jie WANG, Ming YANG, Bailing TIAN, Bohao LI, Zhishi CHEN. Dynamic event-triggered prescribed performance formation control for hypersonic morphing vehicles [J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(9): 532499-532499. |
| [6] | Zhong WANG, Zhongfu REN, Junqiang BAI, Jinxi LANG, Yan LI. Integrated flight/propulsion control of coaxial high-speed helicopter based on robust explicit model following control [J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(7): 632745-632745. |
| [7] | Yuying GUO, Lanxin LIAO, Xiaoqiang ZHANG, Youmin ZHANG, Kai WANG. Finite-time fault-tolerant control of compound actuator faults for unmanned aerial vehicles [J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(4): 332659-332659. |
| [8] | Hang XU, Bin SONG, Lujiang LIU, Xinglong LI, Qiufan YUAN. Fast replanning method for large-scale on-orbit servicing missions [J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(14): 332728-332728. |
| [9] | Dapeng ZHOU, Chong ZHEN, Xiaolei QU, Fei LUO. Hybrid active-passive fault-tolerant control for carrier landing subject to control surface effectiveness loss [J]. Acta Aeronautica et Astronautica Sinica, 2026, 47(11): 332544-332544. |
| [10] | Jiong HE, Binwu REN, Siliang DU, Yousong XU, Bo WANG. Adaptive attitude control for tilt-quadrotor UAV based on ADRC-RBF [J]. Acta Aeronautica et Astronautica Sinica, 2025, 46(S1): 732189-732189. |
| [11] | Shan HUANG, Jingping SHI, Qi ZHU, Yongxi LYU, Xiaobo QU. Prescribed-time incremental backstepping fault-tolerant control for wing-damaged aircraft [J]. Acta Aeronautica et Astronautica Sinica, 2025, 46(15): 331503-331503. |
| [12] | Tao CHEN, Jian CHEN. Learning-observer-based resilient fault-tolerant control for quadrotor unmanned aerial vehicles [J]. Acta Aeronautica et Astronautica Sinica, 2025, 46(11): 531346-531346. |
| [13] | Ji MA, Xiangyong CHEN, Guanghui WEN, Long CHENG, Jianlong QIU. Predefined time tracking control of unmanned aerial vehicles under stochastic switching topology [J]. Acta Aeronautica et Astronautica Sinica, 2024, 45(S1): 730793-730793. |
| [14] | Tiancai WU, Honglun WANG, Bin REN, Guocheng YAN, Xingyu WU. Learning-based hierarchical coordination fault-tolerant method for hypersonic vehicles [J]. Acta Aeronautica et Astronautica Sinica, 2024, 45(22): 330191-330191. |
| [15] | Jie LI, Wenxin HUANG, Yiming CAI, Siyuan WANG, Yufei GAO, Xuefeng JIANG. Fault diagnosis and fault tolerant control of position sensor based on DFPMM [J]. Acta Aeronautica et Astronautica Sinica, 2024, 45(10): 329307-329307. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
Address: No.238, Baiyan Buiding, Beisihuan Zhonglu Road, Haidian District, Beijing, China
Postal code : 100083
E-mail:hkxb@buaa.edu.cn
Total visits: 6658907 Today visits: 1341All copyright © editorial office of Chinese Journal of Aeronautics
All copyright © editorial office of Chinese Journal of Aeronautics
Total visits: 6658907 Today visits: 1341
 CJA